OpenSMI-ROS2 0.1.0__py3-none-any.whl
This diff represents the content of publicly available package versions that have been released to one of the supported registries. The information contained in this diff is provided for informational purposes only and reflects changes between package versions as they appear in their respective public registries.
- opensmi/ros2/__init__.py +89 -0
- opensmi/ros2/__main__.py +11 -0
- opensmi/ros2/cli.py +143 -0
- opensmi/ros2/py.typed +0 -0
- opensmi/ros2/runtime/__init__.py +67 -0
- opensmi/ros2/runtime/_decode.py +101 -0
- opensmi/ros2/runtime/_encode.py +102 -0
- opensmi/ros2/runtime/_parser.py +147 -0
- opensmi/ros2/runtime/errors.py +141 -0
- opensmi/ros2/runtime/goal.py +232 -0
- opensmi/ros2/runtime/graph.py +288 -0
- opensmi/ros2/runtime/guard.py +213 -0
- opensmi/ros2/runtime/interface.py +140 -0
- opensmi/ros2/runtime/messages/__init__.py +503 -0
- opensmi/ros2/runtime/messages/industrial_msgs.py +62 -0
- opensmi/ros2/runtime/messages/industrial_msgs.pyi +159 -0
- opensmi/ros2/runtime/messages/motoros2_interfaces.py +79 -0
- opensmi/ros2/runtime/messages/motoros2_interfaces.pyi +307 -0
- opensmi/ros2/runtime/messages/neo_msgs2.py +55 -0
- opensmi/ros2/runtime/messages/neo_msgs2.pyi +138 -0
- opensmi/ros2/runtime/messages/neo_srvs2.py +72 -0
- opensmi/ros2/runtime/messages/neo_srvs2.pyi +224 -0
- opensmi/ros2/runtime/outcomes.py +103 -0
- opensmi/ros2/runtime/parameters.py +723 -0
- opensmi/ros2/runtime/publisher.py +125 -0
- opensmi/ros2/runtime/qos.py +394 -0
- opensmi/ros2/runtime/runtime.py +1171 -0
- opensmi/ros2/runtime/selection.py +150 -0
- opensmi/ros2/runtime/stamp.py +100 -0
- opensmi/ros2/runtime/subscription.py +354 -0
- opensmi/ros2/runtime/tf.py +714 -0
- opensmi/ros2/server/__init__.py +148 -0
- opensmi/ros2/server/access.py +109 -0
- opensmi/ros2/server/bindings/__init__.py +92 -0
- opensmi/ros2/server/bindings/_base.py +154 -0
- opensmi/ros2/server/bindings/action.py +133 -0
- opensmi/ros2/server/bindings/keyed.py +127 -0
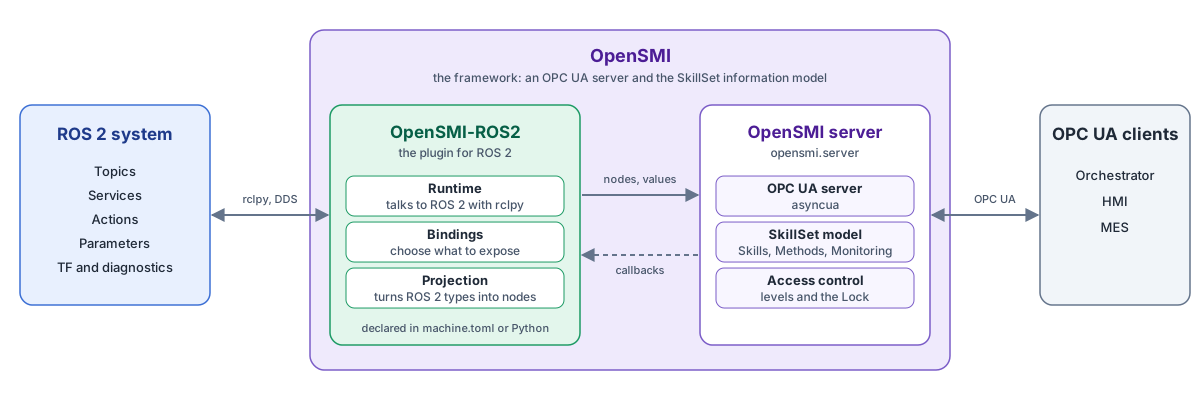
- opensmi/ros2/server/bindings/lifecycle.py +131 -0
- opensmi/ros2/server/bindings/method.py +130 -0
- opensmi/ros2/server/bindings/monitoring.py +109 -0
- opensmi/ros2/server/bindings/parameter.py +133 -0
- opensmi/ros2/server/bindings/publisher.py +192 -0
- opensmi/ros2/server/bindings/registry.py +95 -0
- opensmi/ros2/server/bindings/tf.py +256 -0
- opensmi/ros2/server/browse_names.py +94 -0
- opensmi/ros2/server/component.py +334 -0
- opensmi/ros2/server/config.py +493 -0
- opensmi/ros2/server/containers.py +191 -0
- opensmi/ros2/server/drivers.py +421 -0
- opensmi/ros2/server/errors.py +159 -0
- opensmi/ros2/server/events.py +406 -0
- opensmi/ros2/server/introspection.py +850 -0
- opensmi/ros2/server/keyed.py +749 -0
- opensmi/ros2/server/lifecycle.py +238 -0
- opensmi/ros2/server/limits.py +66 -0
- opensmi/ros2/server/loader.py +977 -0
- opensmi/ros2/server/machine.py +225 -0
- opensmi/ros2/server/method.py +307 -0
- opensmi/ros2/server/mirror.py +582 -0
- opensmi/ros2/server/mutation.py +992 -0
- opensmi/ros2/server/nodesets/Opc.Ua.SmartFactory.ROS2.NodeSet2.xml +85 -0
- opensmi/ros2/server/nodesets/__init__.py +18 -0
- opensmi/ros2/server/nodesets/smart_factory_ros2.py +26 -0
- opensmi/ros2/server/parameters.py +704 -0
- opensmi/ros2/server/projection.py +1176 -0
- opensmi/ros2/server/projections/__init__.py +41 -0
- opensmi/ros2/server/projections/scope.py +222 -0
- opensmi/ros2/server/provenance.py +121 -0
- opensmi/ros2/server/publisher.py +781 -0
- opensmi/ros2/server/recipes.py +514 -0
- opensmi/ros2/server/required.py +633 -0
- opensmi/ros2/server/skill.py +363 -0
- opensmi/ros2/server/spatial.py +283 -0
- opensmi/ros2/server/startup.py +626 -0
- opensmi/ros2/server/status.py +107 -0
- opensmi/ros2/server/structures.py +135 -0
- opensmi/ros2/server/transforms/__init__.py +39 -0
- opensmi/ros2/server/transforms/conversions.py +58 -0
- opensmi/ros2/server/transforms/filing.py +340 -0
- opensmi/ros2/server/transforms/mirror.py +462 -0
- opensmi/ros2/server/transforms/outward.py +180 -0
- opensmi/ros2/server/transforms/records.py +195 -0
- opensmi/ros2/server/transforms/spatial.py +154 -0
- opensmi_ros2-0.1.0.dist-info/METADATA +183 -0
- opensmi_ros2-0.1.0.dist-info/RECORD +89 -0
- opensmi_ros2-0.1.0.dist-info/WHEEL +5 -0
- opensmi_ros2-0.1.0.dist-info/entry_points.txt +2 -0
- opensmi_ros2-0.1.0.dist-info/licenses/LICENSES/MIT.txt +18 -0
- opensmi_ros2-0.1.0.dist-info/top_level.txt +1 -0
|
@@ -0,0 +1,195 @@
|
|
|
1
|
+
# SPDX-FileCopyrightText: 2026 Technologie-Initiative SmartFactory KL e.V.
|
|
2
|
+
#
|
|
3
|
+
# SPDX-License-Identifier: MIT
|
|
4
|
+
|
|
5
|
+
"""The bookkeeping a rendered frame needs: its Location, its owner and its last reading."""
|
|
6
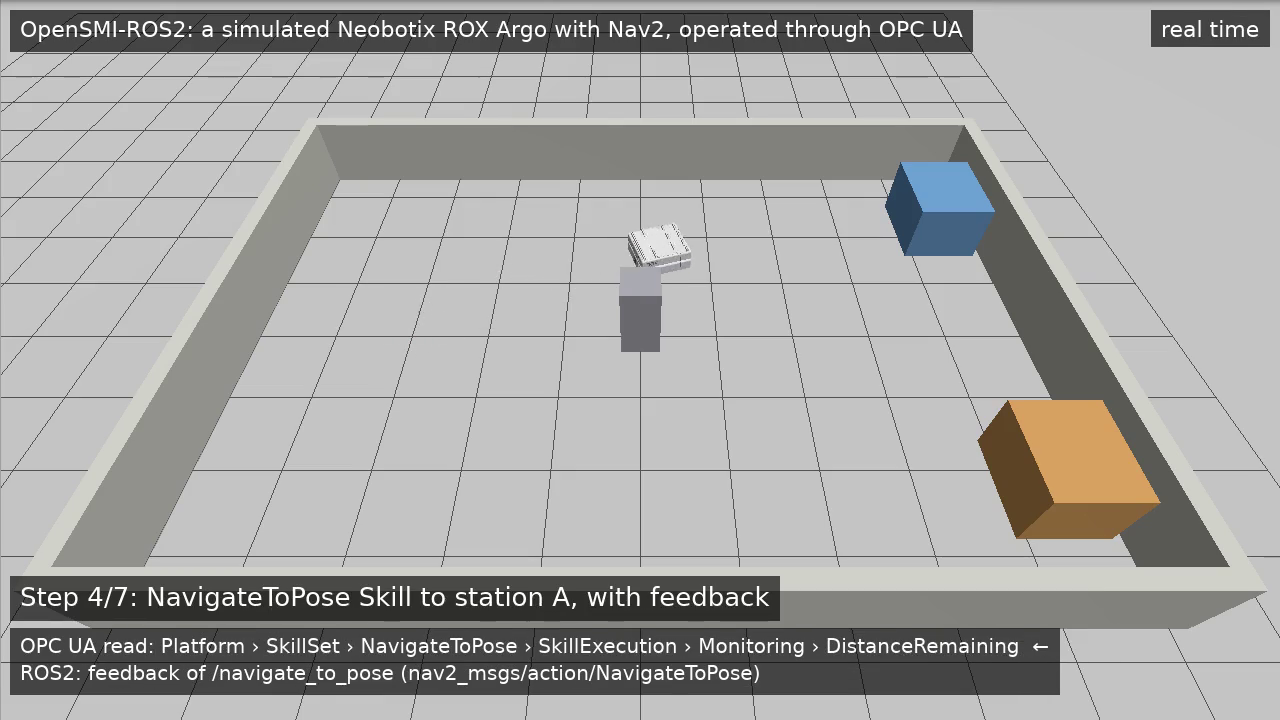
|
+
|
|
7
|
+
from __future__ import annotations
|
|
8
|
+
|
|
9
|
+
from collections.abc import AsyncGenerator
|
|
10
|
+
from dataclasses import dataclass, field
|
|
11
|
+
from typing import TYPE_CHECKING, Any, NamedTuple
|
|
12
|
+
|
|
13
|
+
from asyncua import ua
|
|
14
|
+
from opensmi.core.lifecycle_mixin import lifecycle
|
|
15
|
+
from opensmi.server.spatial_object import CartesianFrame, Orientation, Pose, Position, PositionFrame, SpatialObject
|
|
16
|
+
|
|
17
|
+
from opensmi.ros2.runtime.tf import FrameLink, Transform
|
|
18
|
+
from opensmi.ros2.server.bindings import PublishedFrame, TFBinding
|
|
19
|
+
from opensmi.ros2.server.status import transform_status
|
|
20
|
+
from opensmi.ros2.server.transforms.conversions import DEGREES, METRES
|
|
21
|
+
|
|
22
|
+
if TYPE_CHECKING:
|
|
23
|
+
from collections.abc import Awaitable, Callable, Mapping
|
|
24
|
+
|
|
25
|
+
from asyncua.common.node import Node
|
|
26
|
+
|
|
27
|
+
|
|
28
|
+
class _Observed(CartesianFrame):
|
|
29
|
+
"""A Location that reports a client's write and ignores this module's own bad-status writes.
|
|
30
|
+
|
|
31
|
+
A write is announced to ``on_value_change`` once opensmi has stored it, which is how a client's
|
|
32
|
+
pose reaches ROS2. Without a ``written`` callback the node is made read-only after creation,
|
|
33
|
+
because opensmi makes every Cartesian frame writable. This module writes bad statuses on
|
|
34
|
+
purpose, and OPC UA nulls such a value, so a null value is passed over silently instead of being
|
|
35
|
+
logged as invalid.
|
|
36
|
+
"""
|
|
37
|
+
|
|
38
|
+
def __init__(
|
|
39
|
+
self,
|
|
40
|
+
*,
|
|
41
|
+
written: Callable[[Pose], Awaitable[None]] | None = None,
|
|
42
|
+
minimum_access_level: int | None = None,
|
|
43
|
+
**kwargs: Any,
|
|
44
|
+
) -> None:
|
|
45
|
+
"""Remember who to tell about a client's write, if anybody."""
|
|
46
|
+
super().__init__(minimum_access_level=minimum_access_level, **kwargs)
|
|
47
|
+
self._written = written
|
|
48
|
+
|
|
49
|
+
@lifecycle(after=CartesianFrame.lifecycle_frame)
|
|
50
|
+
async def lifecycle_observed(self) -> AsyncGenerator[None]:
|
|
51
|
+
"""Take the write bit off a Location nobody may write."""
|
|
52
|
+
if self._written is None:
|
|
53
|
+
await self.ua_node.set_writable(False)
|
|
54
|
+
yield
|
|
55
|
+
# no shutdown
|
|
56
|
+
|
|
57
|
+
async def on_value_change(self, handle: int, dv: ua.DataValue) -> None:
|
|
58
|
+
"""Keep the children in step, then tell the owner what a client wrote."""
|
|
59
|
+
value = dv.Value.Value if dv is not None and dv.Value is not None else None
|
|
60
|
+
if not isinstance(value, ua.ThreeDFrame):
|
|
61
|
+
return
|
|
62
|
+
await super().on_value_change(handle, dv)
|
|
63
|
+
if self._written is not None:
|
|
64
|
+
await self._written(Pose.from_ua(value, length_unit=METRES, angle_unit=DEGREES))
|
|
65
|
+
|
|
66
|
+
|
|
67
|
+
class _Head(_Observed, PositionFrame):
|
|
68
|
+
"""The ``PositionFrame`` of a SpatialObject: a Location, read from the tree and so read-only."""
|
|
69
|
+
|
|
70
|
+
|
|
71
|
+
@dataclass(slots=True)
|
|
72
|
+
class _Frame:
|
|
73
|
+
"""One rendered Location: which frame it is, and what it last read.
|
|
74
|
+
|
|
75
|
+
:ivar constant: Whether the constant access bit is set. It is set on the first message that says
|
|
76
|
+
the frame is static, because a frame may first arrive on ``/tf``.
|
|
77
|
+
:ivar status: The status last written beside the pose, or ``None``. Compared every tick, because
|
|
78
|
+
a frame that goes quiet and returns unmoved has changed only this.
|
|
79
|
+
:ivar bearers: The nine value-bearing nodes, browsed on the first bad-status write.
|
|
80
|
+
"""
|
|
81
|
+
|
|
82
|
+
frame: str
|
|
83
|
+
browse: str
|
|
84
|
+
location: CartesianFrame
|
|
85
|
+
folder: str | None
|
|
86
|
+
position: Position | None = None
|
|
87
|
+
orientation: Orientation | None = None
|
|
88
|
+
base: ua.NodeId | None = None
|
|
89
|
+
constant: bool = False
|
|
90
|
+
status: ua.StatusCode | None = None
|
|
91
|
+
bearers: _Bearers | None = None
|
|
92
|
+
|
|
93
|
+
@property
|
|
94
|
+
def node(self) -> Node:
|
|
95
|
+
"""Return the node this Location is."""
|
|
96
|
+
return self.location.ua_node
|
|
97
|
+
|
|
98
|
+
|
|
99
|
+
class _Bearers(NamedTuple):
|
|
100
|
+
"""The nine value-bearing nodes of one Location, named so they cannot be unpacked in the wrong order.
|
|
101
|
+
|
|
102
|
+
``X``, ``Y`` and ``Z`` are unqualified while ``A``, ``B`` and ``C`` sit in the RSL namespace
|
|
103
|
+
(OPC 10000-210's own asymmetry). ``frame`` holds the whole ``3DFrame``.
|
|
104
|
+
"""
|
|
105
|
+
|
|
106
|
+
frame: Node
|
|
107
|
+
position: Node
|
|
108
|
+
x: Node
|
|
109
|
+
y: Node
|
|
110
|
+
z: Node
|
|
111
|
+
orientation: Node
|
|
112
|
+
a: Node
|
|
113
|
+
b: Node
|
|
114
|
+
c: Node
|
|
115
|
+
|
|
116
|
+
|
|
117
|
+
@dataclass(frozen=True, slots=True, kw_only=True)
|
|
118
|
+
class _Quiet:
|
|
119
|
+
"""One tick's answer to which frames have gone quiet.
|
|
120
|
+
|
|
121
|
+
It is built once per poll so that all frames are judged against one clock reading.
|
|
122
|
+
|
|
123
|
+
:ivar present: Whether anything is publishing on the transform topics at all.
|
|
124
|
+
:ivar seen: When each frame was last in a message, on the Runtime's clock.
|
|
125
|
+
:ivar now: The current time on that clock.
|
|
126
|
+
:ivar within: How long a frame may go unpublished and still speak for itself.
|
|
127
|
+
:ivar roots: The roots of the rendered tree, which no message carries.
|
|
128
|
+
"""
|
|
129
|
+
|
|
130
|
+
present: bool
|
|
131
|
+
seen: Mapping[str, float]
|
|
132
|
+
now: float
|
|
133
|
+
within: float
|
|
134
|
+
roots: frozenset[str]
|
|
135
|
+
|
|
136
|
+
def status_of(self, frame: str, link: FrameLink | None) -> ua.StatusCode:
|
|
137
|
+
"""Return the status code one frame's Location reads this tick.
|
|
138
|
+
|
|
139
|
+
:param frame: The frame being judged.
|
|
140
|
+
:param link: What the frame network holds for it, or ``None``. Only its ``static`` flag is
|
|
141
|
+
used, because quiet is the normal state of a static frame.
|
|
142
|
+
"""
|
|
143
|
+
return transform_status(
|
|
144
|
+
present=self.present,
|
|
145
|
+
static=link is not None and link.static,
|
|
146
|
+
rooted=frame in self.roots,
|
|
147
|
+
seen=self.seen.get(frame),
|
|
148
|
+
now=self.now,
|
|
149
|
+
within=self.within,
|
|
150
|
+
)
|
|
151
|
+
|
|
152
|
+
|
|
153
|
+
@dataclass(slots=True)
|
|
154
|
+
class _Published:
|
|
155
|
+
"""One declared outward frame: the writable Location and what was last sent.
|
|
156
|
+
|
|
157
|
+
Its pose is whatever the client last wrote, so none is cached here.
|
|
158
|
+
|
|
159
|
+
:ivar declared: The declaration this Location exists for.
|
|
160
|
+
:ivar location: The writable Location.
|
|
161
|
+
:ivar base: What the ``Base`` was last written as.
|
|
162
|
+
:ivar sent: The transform last put on the wire. A static frame is published only when it
|
|
163
|
+
differs.
|
|
164
|
+
"""
|
|
165
|
+
|
|
166
|
+
declared: PublishedFrame
|
|
167
|
+
location: CartesianFrame
|
|
168
|
+
base: ua.NodeId | None = None
|
|
169
|
+
sent: Transform | None = None
|
|
170
|
+
|
|
171
|
+
|
|
172
|
+
@dataclass(slots=True)
|
|
173
|
+
class _Owner:
|
|
174
|
+
"""One machinery item's SpatialObject, live: what it declared and what it has rendered.
|
|
175
|
+
|
|
176
|
+
:ivar folders: Frame folders created so far, so each is counted and announced once.
|
|
177
|
+
"""
|
|
178
|
+
|
|
179
|
+
item: Any
|
|
180
|
+
binding: TFBinding
|
|
181
|
+
spatial: SpatialObject
|
|
182
|
+
frames: dict[str, _Frame] = field(default_factory=dict)
|
|
183
|
+
folders: set[str] = field(default_factory=set)
|
|
184
|
+
claimed: dict[str, str] = field(default_factory=dict)
|
|
185
|
+
refused: set[str] = field(default_factory=set)
|
|
186
|
+
alternatives: dict[tuple[str, str], _Frame] = field(default_factory=dict)
|
|
187
|
+
unresolved: set[tuple[str, str]] = field(default_factory=set)
|
|
188
|
+
published: dict[str, _Published] = field(default_factory=dict)
|
|
189
|
+
capped: bool = False
|
|
190
|
+
wanted: set[str] = field(default_factory=set)
|
|
191
|
+
|
|
192
|
+
@property
|
|
193
|
+
def node(self) -> Node:
|
|
194
|
+
"""Return the node this SpatialObject is."""
|
|
195
|
+
return self.spatial.ua_node
|
|
@@ -0,0 +1,154 @@
|
|
|
1
|
+
# SPDX-FileCopyrightText: 2026 Technologie-Initiative SmartFactory KL e.V.
|
|
2
|
+
#
|
|
3
|
+
# SPDX-License-Identifier: MIT
|
|
4
|
+
|
|
5
|
+
"""The SpatialObject of a machinery item that declared a TF Binding."""
|
|
6
|
+
|
|
7
|
+
from __future__ import annotations
|
|
8
|
+
|
|
9
|
+
from typing import TYPE_CHECKING, Any
|
|
10
|
+
|
|
11
|
+
from opensmi.server.spatial_object import SpatialObject
|
|
12
|
+
|
|
13
|
+
from opensmi.ros2.server.bindings import TFBinding
|
|
14
|
+
from opensmi.ros2.server.config import ROS2Config, TransformConfig
|
|
15
|
+
from opensmi.ros2.server.errors import (
|
|
16
|
+
DeclarationError,
|
|
17
|
+
)
|
|
18
|
+
from opensmi.ros2.server.mutation import ROS2MutationMixin
|
|
19
|
+
from opensmi.ros2.server.transforms.conversions import _ORIGIN
|
|
20
|
+
from opensmi.ros2.server.transforms.records import (
|
|
21
|
+
_Head,
|
|
22
|
+
)
|
|
23
|
+
|
|
24
|
+
if TYPE_CHECKING:
|
|
25
|
+
from collections.abc import Mapping
|
|
26
|
+
|
|
27
|
+
from opensmi.ros2.runtime.interface import RuntimeInterface
|
|
28
|
+
from opensmi.ros2.runtime.tf import TFWatch
|
|
29
|
+
|
|
30
|
+
|
|
31
|
+
class ROS2SpatialMixin(ROS2MutationMixin):
|
|
32
|
+
"""Gives a machinery item that declared a TF Binding its SpatialObject and its TF reading.
|
|
33
|
+
|
|
34
|
+
Goes on the Machine and on Components, because OPC 10000-210 6.1.1 defines the SpatialObjectType
|
|
35
|
+
as an AddIn extending an existing object. It also opens the item's TF watch. The facet
|
|
36
|
+
reference-counts, so any number of items share one pair of subscriptions, and the watch must
|
|
37
|
+
exist before a required TF Binding waits on it. Topics and depth come from the Machine's
|
|
38
|
+
:class:`~opensmi.ros2.server.config.TransformConfig`, so every item reads the same frame
|
|
39
|
+
network.
|
|
40
|
+
"""
|
|
41
|
+
|
|
42
|
+
def __init__(self, *args: Any, **kwargs: Any) -> None:
|
|
43
|
+
"""Start out with no SpatialObject, and pass every argument to opensmi."""
|
|
44
|
+
super().__init__(*args, **kwargs)
|
|
45
|
+
self._ros2_spatial_object: SpatialObject | None = None
|
|
46
|
+
self._ros2_tf_watch: TFWatch | None = None
|
|
47
|
+
|
|
48
|
+
@property
|
|
49
|
+
def ros2_tf_binding(self) -> TFBinding | None:
|
|
50
|
+
"""Return the one TF Binding this item declared, or ``None``.
|
|
51
|
+
|
|
52
|
+
A machinery item has one head frame, and OPC 10000-210 gives a SpatialObject one
|
|
53
|
+
``PositionFrame``.
|
|
54
|
+
|
|
55
|
+
:raises DeclarationError: When this item declares more than one.
|
|
56
|
+
"""
|
|
57
|
+
declared = [each for each in getattr(self, "ros2_bindings", ()) if isinstance(each, TFBinding)]
|
|
58
|
+
if not declared:
|
|
59
|
+
return None
|
|
60
|
+
if len(declared) > 1:
|
|
61
|
+
listed = ", ".join(repr(each.name) for each in declared)
|
|
62
|
+
message = (
|
|
63
|
+
f"{type(self).__name__} declares {len(declared)} TF Bindings ({listed}); a "
|
|
64
|
+
f"machinery item is one thing in space, so it has one head frame and one "
|
|
65
|
+
f"SpatialObject, and OPC 10000-210 gives that object exactly one PositionFrame"
|
|
66
|
+
)
|
|
67
|
+
raise DeclarationError(message)
|
|
68
|
+
return declared[0]
|
|
69
|
+
|
|
70
|
+
@property
|
|
71
|
+
def ros2_spatial_object(self) -> SpatialObject | None:
|
|
72
|
+
"""Return this item's SpatialObject, or ``None`` when it declared no TF Binding."""
|
|
73
|
+
return self._ros2_spatial_object
|
|
74
|
+
|
|
75
|
+
@property
|
|
76
|
+
def ros2_transform_presence(self) -> Mapping[str, bool]:
|
|
77
|
+
"""Return, per TF Binding name, whether anything is publishing transforms right now.
|
|
78
|
+
|
|
79
|
+
Presence only, never a particular frame: a required TF Binding that waited for ``tool0``
|
|
80
|
+
would keep the Machine from starting until somebody switched an arm on.
|
|
81
|
+
"""
|
|
82
|
+
binding = self.ros2_tf_binding
|
|
83
|
+
if binding is None:
|
|
84
|
+
return {}
|
|
85
|
+
return {binding.name: bool(self._ros2_runtime_for_tf().tf.satisfied)}
|
|
86
|
+
|
|
87
|
+
async def _init_ros2_spatial_object(self) -> None:
|
|
88
|
+
"""Create this item's SpatialObject and open its TF watch, if it declared a TF Binding.
|
|
89
|
+
|
|
90
|
+
The ``PositionFrame`` starts at zero metres on the World Frame; the first poll re-bases it
|
|
91
|
+
onto its head frame's TF parent. The SpatialObject is created here instead of by opensmi's
|
|
92
|
+
spatial-object mixin, because that mixin needs a typed-parent property a Component need not
|
|
93
|
+
have.
|
|
94
|
+
|
|
95
|
+
:raises DeclarationError: When the Machine has no spatial-object list.
|
|
96
|
+
"""
|
|
97
|
+
binding = self.ros2_tf_binding
|
|
98
|
+
if binding is None:
|
|
99
|
+
return
|
|
100
|
+
try:
|
|
101
|
+
listed = self.ros2_root_machine.spatial_object_list
|
|
102
|
+
except Exception as error:
|
|
103
|
+
message = (
|
|
104
|
+
f"{type(self).__name__} declares the TF Binding {binding.name!r} and its Machine "
|
|
105
|
+
f"has no spatial object list; a SpatialObject is an AddIn on an object inside one"
|
|
106
|
+
)
|
|
107
|
+
raise DeclarationError(message) from error
|
|
108
|
+
spatial = SpatialObject(position_frame=_Head(initial_pose=_ORIGIN, initial_base=listed.world_frame))
|
|
109
|
+
spatial.parent = self
|
|
110
|
+
await spatial.ua_create_node(self.ua_node)
|
|
111
|
+
await spatial.init()
|
|
112
|
+
await listed.add_spatial_object(spatial)
|
|
113
|
+
self._ros2_spatial_object = spatial
|
|
114
|
+
# The Machine's topics and depth, so every item on it reads the same frame network.
|
|
115
|
+
settings = self.ros2_transform_settings
|
|
116
|
+
self._ros2_tf_watch = await self._ros2_runtime_for_tf().tf.watch(
|
|
117
|
+
topic=settings.path,
|
|
118
|
+
static_topic=settings.static_path,
|
|
119
|
+
depth=settings.depth,
|
|
120
|
+
# Whether the topics are also advertised is decided here: `satisfied` discounts our own publisher,
|
|
121
|
+
# so the count must be right before anything waits on it.
|
|
122
|
+
broadcasting=binding.broadcasts,
|
|
123
|
+
)
|
|
124
|
+
|
|
125
|
+
async def _stop_spatial_object(self) -> None:
|
|
126
|
+
"""Close this item's TF watch. Idempotent.
|
|
127
|
+
|
|
128
|
+
It runs before the Runtime stops, so an item torn down alone stops reading.
|
|
129
|
+
"""
|
|
130
|
+
if self._ros2_tf_watch is None:
|
|
131
|
+
return
|
|
132
|
+
watch, self._ros2_tf_watch = self._ros2_tf_watch, None
|
|
133
|
+
await watch.close()
|
|
134
|
+
|
|
135
|
+
@property
|
|
136
|
+
def ros2_transform_settings(self) -> TransformConfig:
|
|
137
|
+
"""Return where this item's Machine reads TF from, and how often it polls.
|
|
138
|
+
|
|
139
|
+
A Component answers with its Machine's settings. An item whose Machine is not one of ours
|
|
140
|
+
gets the defaults.
|
|
141
|
+
"""
|
|
142
|
+
config: ROS2Config | None = getattr(self, "ros2_config", None)
|
|
143
|
+
return (config or ROS2Config()).transforms
|
|
144
|
+
|
|
145
|
+
def _ros2_runtime_for_tf(self) -> RuntimeInterface:
|
|
146
|
+
"""Return the Runtime this item reaches TF through.
|
|
147
|
+
|
|
148
|
+
:raises DeclarationError: When there is none (a wiring fault).
|
|
149
|
+
"""
|
|
150
|
+
runtime: RuntimeInterface | None = getattr(self, "runtime", None)
|
|
151
|
+
if runtime is None: # pragma: no cover -- every caller runs after the Runtime is injected
|
|
152
|
+
message = f"{type(self).__name__} declares a TF Binding and carries no Runtime"
|
|
153
|
+
raise DeclarationError(message)
|
|
154
|
+
return runtime
|
|
@@ -0,0 +1,183 @@
|
|
|
1
|
+
Metadata-Version: 2.4
|
|
2
|
+
Name: OpenSMI-ROS2
|
|
3
|
+
Version: 0.1.0
|
|
4
|
+
Summary: Exposes a ROS2 system as an OPC UA server built on opensmi.server and the SkillSet information model.
|
|
5
|
+
License-Expression: MIT
|
|
6
|
+
Project-URL: Repository, https://github.com/SmartFactory-KL/opensmi-ros2
|
|
7
|
+
Project-URL: Documentation, https://smartfactory-kl.github.io/opensmi-ros2/
|
|
8
|
+
Project-URL: Issues, https://github.com/SmartFactory-KL/opensmi-ros2/issues
|
|
9
|
+
Project-URL: Changelog, https://github.com/SmartFactory-KL/opensmi-ros2/blob/main/docs/migration.md
|
|
10
|
+
Classifier: Development Status :: 3 - Alpha
|
|
11
|
+
Classifier: Framework :: AsyncIO
|
|
12
|
+
Classifier: Intended Audience :: Developers
|
|
13
|
+
Classifier: Intended Audience :: Manufacturing
|
|
14
|
+
Classifier: Operating System :: POSIX :: Linux
|
|
15
|
+
Classifier: Programming Language :: Python :: 3
|
|
16
|
+
Classifier: Programming Language :: Python :: 3.11
|
|
17
|
+
Classifier: Programming Language :: Python :: 3.12
|
|
18
|
+
Classifier: Topic :: Scientific/Engineering :: Interface Engine/Protocol Translator
|
|
19
|
+
Classifier: Typing :: Typed
|
|
20
|
+
Requires-Python: >=3.11
|
|
21
|
+
Description-Content-Type: text/markdown
|
|
22
|
+
License-File: LICENSES/MIT.txt
|
|
23
|
+
Requires-Dist: OpenSMI-Server<0.5,>=0.4.1
|
|
24
|
+
Requires-Dist: OpenSMI-Core<0.9,>=0.8.1
|
|
25
|
+
Requires-Dist: asyncua<3,>=2.0.1
|
|
26
|
+
Requires-Dist: structlog<27,>=25.1
|
|
27
|
+
Requires-Dist: typing-extensions<5,>=4.16
|
|
28
|
+
Dynamic: license-file
|
|
29
|
+
|
|
30
|
+
|
|
31
|
+
|
|
32
|
+
[](https://smartfactory-kl.github.io/opensmi-ros2/)
|
|
33
|
+
[](https://pypi.org/project/opensmi-ros2/)
|
|
34
|
+
[](https://pypi.org/project/opensmi-ros2/)
|
|
35
|
+
[](https://github.com/SmartFactory-KL/opensmi-ros2/blob/main/LICENSES/MIT.txt)
|
|
36
|
+
|
|
37
|
+
# OpenSMI-ROS2
|
|
38
|
+
|
|
39
|
+
OpenSMI-ROS2 serves a ROS 2 system as an [OPC UA](https://opcfoundation.org/about/opc-technologies/opc-ua/) server. It builds on opensmi.server and the
|
|
40
|
+
SmartFactory-KL SkillSet information model, so an OPC UA client sees a robot as a Machine with
|
|
41
|
+
Components that carry Skills, Methods and Monitoring variables instead of a list of [topics](https://docs.ros.org/en/jazzy/Concepts/Basic/About-Topics.html), [services](https://docs.ros.org/en/jazzy/Concepts/Basic/About-Services.html)
|
|
42
|
+
and [actions](https://docs.ros.org/en/jazzy/Concepts/Basic/About-Actions.html).
|
|
43
|
+
|
|
44
|
+
You choose what to expose by declaring Bindings on a Component, in Python or in one TOML file. A
|
|
45
|
+
Binding ties one ROS 2 [topic](https://docs.ros.org/en/jazzy/Concepts/Basic/About-Topics.html), [service](https://docs.ros.org/en/jazzy/Concepts/Basic/About-Services.html), [action](https://docs.ros.org/en/jazzy/Concepts/Basic/About-Actions.html),
|
|
46
|
+
[parameter set](https://docs.ros.org/en/jazzy/Concepts/Basic/About-Parameters.html), [lifecycle node](https://design.ros2.org/articles/node_lifecycle.html),
|
|
47
|
+
[TF tree](https://docs.ros.org/en/jazzy/Concepts/Intermediate/About-Tf2.html) or diagnostics topic to its place in the OPC UA address space.
|
|
48
|
+
|
|
49
|
+
|
|
50
|
+
|
|
51
|
+
OpenSMI-ROS2 is the project name. The Python distribution and the command-line executable are named
|
|
52
|
+
`opensmi-ros2`, and the public Python namespace is `opensmi.ros2`. A Binding maps a ROS 2 interface to
|
|
53
|
+
an OPC UA representation; [docs/bindings.md](https://github.com/SmartFactory-KL/opensmi-ros2/blob/main/docs/bindings.md) lists the eight kinds.
|
|
54
|
+
|
|
55
|
+
> [!warning]
|
|
56
|
+
> This library is pre-1.0. Expect changes to the machine file, the OPC UA address space and the Python API;
|
|
57
|
+
> [docs/migration.md](https://github.com/SmartFactory-KL/opensmi-ros2/blob/main/docs/migration.md) lists every change that breaks a client.
|
|
58
|
+
|
|
59
|
+
## Features
|
|
60
|
+
|
|
61
|
+
| ROS 2 side | OPC UA side | Direction |
|
|
62
|
+
| --- | --- | --- |
|
|
63
|
+
| [Topic](https://docs.ros.org/en/jazzy/Concepts/Basic/About-Topics.html) | Monitoring variables | ROS 2 to OPC UA |
|
|
64
|
+
| [Topic](https://docs.ros.org/en/jazzy/Concepts/Basic/About-Topics.html) | Skill that publishes while it runs | OPC UA to ROS 2 |
|
|
65
|
+
| [Service](https://docs.ros.org/en/jazzy/Concepts/Basic/About-Services.html) | Method | OPC UA to ROS 2 |
|
|
66
|
+
| [Action](https://docs.ros.org/en/jazzy/Concepts/Basic/About-Actions.html) | Skill with feedback and a Result | OPC UA to ROS 2 |
|
|
67
|
+
| [Lifecycle node](https://design.ros2.org/articles/node_lifecycle.html) or lifecycle manager | StartupSkill | both |
|
|
68
|
+
| [TF tree](https://docs.ros.org/en/jazzy/Concepts/Intermediate/About-Tf2.html) | [Locations](https://reference.opcfoundation.org/specs/OPC-10000-210) inside a SpatialObject (OPC 10000-210, Relative Spatial Location) | both, per frame |
|
|
69
|
+
| [`/diagnostics`](https://docs.ros.org/en/jazzy/p/diagnostic_msgs/) | One member per diagnostic id, and an event per level change | ROS 2 to OPC UA |
|
|
70
|
+
| A node's [ROS 2 parameters](https://docs.ros.org/en/jazzy/Concepts/Basic/About-Parameters.html) | Writable Parameters | both |
|
|
71
|
+
|
|
72
|
+
A whole server starts from one TOML file with `opensmi-ros2 serve`, and every Machine carries a
|
|
73
|
+
`ROS2Introspection` Component that lists the ROS 2 graph. The [architecture](https://github.com/SmartFactory-KL/opensmi-ros2/blob/main/docs/architecture.md)
|
|
74
|
+
page has the rest.
|
|
75
|
+
|
|
76
|
+
## Quick start
|
|
77
|
+
|
|
78
|
+
You need Linux, ROS 2 Jazzy and Python 3.11 or newer. From a clone:
|
|
79
|
+
|
|
80
|
+
```sh
|
|
81
|
+
. /opt/ros/jazzy/setup.bash
|
|
82
|
+
python3 -m venv --system-site-packages .venv
|
|
83
|
+
. .venv/bin/activate
|
|
84
|
+
python -m pip install -c constraints.txt -e .
|
|
85
|
+
```
|
|
86
|
+
|
|
87
|
+
Keep the `-c constraints.txt`: it pins the opensmi versions the code is tested against. Then save
|
|
88
|
+
this as `machine.toml`:
|
|
89
|
+
|
|
90
|
+
```toml
|
|
91
|
+
[machine]
|
|
92
|
+
name = "Robot"
|
|
93
|
+
|
|
94
|
+
[machine.identification]
|
|
95
|
+
serial_number = "0001"
|
|
96
|
+
manufacturer = "Example"
|
|
97
|
+
product_instance_uri = "urn:example:robot"
|
|
98
|
+
|
|
99
|
+
[[component]]
|
|
100
|
+
name = "Platform"
|
|
101
|
+
|
|
102
|
+
[component.identification]
|
|
103
|
+
serial_number = "0001-platform"
|
|
104
|
+
manufacturer = "Example"
|
|
105
|
+
|
|
106
|
+
[[component.monitoring]]
|
|
107
|
+
name = "Odom"
|
|
108
|
+
path = "/odom"
|
|
109
|
+
message_type = "nav_msgs/msg/Odometry"
|
|
110
|
+
```
|
|
111
|
+
|
|
112
|
+
and start the server:
|
|
113
|
+
|
|
114
|
+
```sh
|
|
115
|
+
opensmi-ros2 serve machine.toml
|
|
116
|
+
```
|
|
117
|
+
|
|
118
|
+
It listens on `opc.tcp://localhost:4841/server`, and the odometry is the variable
|
|
119
|
+
`Platform/Monitoring/Odom`. [Getting started](https://github.com/SmartFactory-KL/opensmi-ros2/blob/main/docs/getting-started.md) explains the checks and what
|
|
120
|
+
you see in a client. To operate a Machine from a client, with the Lock, a Skill and its errors, run the
|
|
121
|
+
script in the [client quickstart](https://github.com/SmartFactory-KL/opensmi-ros2/blob/main/docs/client-quickstart.md).
|
|
122
|
+
|
|
123
|
+
## Examples
|
|
124
|
+
|
|
125
|
+
[`examples/`](https://github.com/SmartFactory-KL/opensmi-ros2/blob/main/examples/README.md) holds the example Machine in TOML and Python, the Machine and
|
|
126
|
+
client of the [client quickstart](https://github.com/SmartFactory-KL/opensmi-ros2/blob/main/docs/client-quickstart.md), and two complete simulated robots that
|
|
127
|
+
run in Docker with one command. Click a picture for the video of a whole run:
|
|
128
|
+
|
|
129
|
+
| [`nav2-rox-argo`](https://github.com/SmartFactory-KL/opensmi-ros2/blob/main/examples/nav2-rox-argo/README.md) | [`moveit-hc10-robotiq`](https://github.com/SmartFactory-KL/opensmi-ros2/blob/main/examples/moveit-hc10-robotiq/README.md) |
|
|
130
|
+
| --- | --- |
|
|
131
|
+
| [](https://github.com/SmartFactory-KL/opensmi-ros2/blob/main/examples/nav2-rox-argo/media/rox-argo.mp4) | [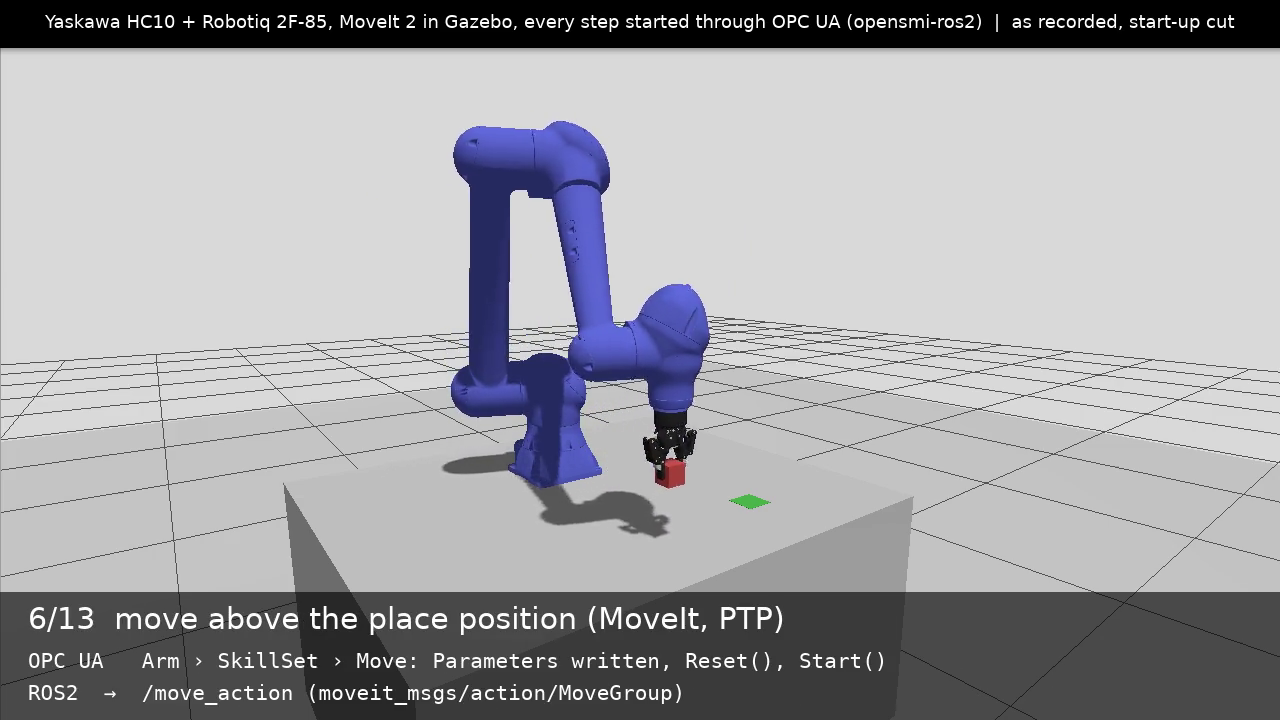](https://github.com/SmartFactory-KL/opensmi-ros2/blob/main/examples/moveit-hc10-robotiq/media/hc10-pick-and-place.mp4) |
|
|
132
|
+
| A Neobotix ROX Argo with Nav2 in Gazebo | A Yaskawa HC10 with a Robotiq 2F-85 and MoveIt in Gazebo |
|
|
133
|
+
|
|
134
|
+
## Documentation
|
|
135
|
+
|
|
136
|
+
The [documentation](https://github.com/SmartFactory-KL/opensmi-ros2/blob/main/docs/README.md) covers:
|
|
137
|
+
|
|
138
|
+
- [Getting started](https://github.com/SmartFactory-KL/opensmi-ros2/blob/main/docs/getting-started.md): install, serve a Machine, run and stop.
|
|
139
|
+
- [Client quickstart](https://github.com/SmartFactory-KL/opensmi-ros2/blob/main/docs/client-quickstart.md): a runnable OPC UA client that logs in, takes the
|
|
140
|
+
Lock, starts a Skill and shows the errors the server answers with.
|
|
141
|
+
- [Architecture](https://github.com/SmartFactory-KL/opensmi-ros2/blob/main/docs/architecture.md): the two halves and the Bindings.
|
|
142
|
+
- [Configuration](https://github.com/SmartFactory-KL/opensmi-ros2/blob/main/docs/configuration.md): the machine file, `[ros2]` and the opensmi server.
|
|
143
|
+
- [Writing a server in Python](https://github.com/SmartFactory-KL/opensmi-ros2/blob/main/docs/python-api.md).
|
|
144
|
+
- [Bindings](https://github.com/SmartFactory-KL/opensmi-ros2/blob/main/docs/bindings.md): the reference for all eight kinds, with fields, rules and examples.
|
|
145
|
+
- [Browse paths](https://github.com/SmartFactory-KL/opensmi-ros2/blob/main/docs/browse-paths.md) and [publishing Bindings](https://github.com/SmartFactory-KL/opensmi-ros2/blob/main/docs/publishing-bindings.md).
|
|
146
|
+
- [Deployment](https://github.com/SmartFactory-KL/opensmi-ros2/blob/main/docs/deployment.md): users, encryption, the ROS 2 network and the robot's own safety.
|
|
147
|
+
- [Testing](https://github.com/SmartFactory-KL/opensmi-ros2/blob/main/docs/testing.md).
|
|
148
|
+
- [Changes that break a client](https://github.com/SmartFactory-KL/opensmi-ros2/blob/main/docs/migration.md).
|
|
149
|
+
|
|
150
|
+
## Versioning
|
|
151
|
+
|
|
152
|
+
OpenSMI-ROS2 follows [Semantic Versioning](https://semver.org). Before 1.0.0 a change that breaks
|
|
153
|
+
the machine file, the OPC UA address space or the Python API raises the minor version and is listed
|
|
154
|
+
in [docs/migration.md](https://github.com/SmartFactory-KL/opensmi-ros2/blob/main/docs/migration.md); a patch release never breaks anything.
|
|
155
|
+
|
|
156
|
+
## Contributing
|
|
157
|
+
|
|
158
|
+
[CONTRIBUTING.md](https://github.com/SmartFactory-KL/opensmi-ros2/blob/main/CONTRIBUTING.md) covers the setup, the checks CI runs, the rules for the public API
|
|
159
|
+
and the commit conventions (Conventional Commits, with a changelog generated by git-cliff).
|
|
160
|
+
|
|
161
|
+
## Contact
|
|
162
|
+
|
|
163
|
+
Benjamin Blumhofer, Technologie-Initiative SmartFactory KL e.V.,
|
|
164
|
+
<benjamin.blumhofer@smartfactory.de>. Report bugs and questions in the
|
|
165
|
+
[issue tracker](https://github.com/SmartFactory-KL/opensmi-ros2/issues).
|
|
166
|
+
|
|
167
|
+
## AI disclaimer
|
|
168
|
+
|
|
169
|
+
OpenSMI-ROS2 builds on two earlier versions of a project that was written by hand. The software
|
|
170
|
+
design, the architecture and the decisions behind it come from the maintainers. An AI coding
|
|
171
|
+
assistant (Claude, by Anthropic) helped with the implementation. The maintainers review what is
|
|
172
|
+
merged and are responsible for it, but code written with AI help can still contain mistakes. Test
|
|
173
|
+
it before you rely on it, and do not run it on a real machine without safeguards.
|
|
174
|
+
|
|
175
|
+
## License
|
|
176
|
+
|
|
177
|
+
OpenSMI-ROS2 is licensed under the MIT License; see [LICENSES/MIT.txt](https://github.com/SmartFactory-KL/opensmi-ros2/blob/main/LICENSES/MIT.txt). Copyright
|
|
178
|
+
2026 Technologie-Initiative SmartFactory KL e.V.
|
|
179
|
+
|
|
180
|
+
Some files in the repository are third-party and keep their own licences, as recorded in
|
|
181
|
+
[REUSE.toml](https://github.com/SmartFactory-KL/opensmi-ros2/blob/main/REUSE.toml): the vendored ROS 2 interface definitions in `catalog/packages/`
|
|
182
|
+
(BSD-3-Clause and Apache-2.0) and the vendored ROS 2 parser in `tools/catalog/_vendor/` (Apache-2.0).
|
|
183
|
+
The licence texts are in [LICENSES/](https://github.com/SmartFactory-KL/opensmi-ros2/tree/main/LICENSES).
|
|
@@ -0,0 +1,89 @@
|
|
|
1
|
+
opensmi/ros2/__init__.py,sha256=4EbHpmnS_OlroE2kq02LTkWbk17r8WfjSvJ2KcFlOok,4488
|
|
2
|
+
opensmi/ros2/__main__.py,sha256=C6MmIuZCq22F_zxwaMYZOLreAcW67AvNLrWFc4O9ytw,270
|
|
3
|
+
opensmi/ros2/cli.py,sha256=X_aK8VCHTXB2ZuuZ7MuVadta2TLRe1Gq8mN19EUPA3c,5704
|
|
4
|
+
opensmi/ros2/py.typed,sha256=47DEQpj8HBSa-_TImW-5JCeuQeRkm5NMpJWZG3hSuFU,0
|
|
5
|
+
opensmi/ros2/runtime/__init__.py,sha256=YW_Y_1Kqw8RR0evJGoMCKo_bd-m6DP6W3OCuAhYam7k,2398
|
|
6
|
+
opensmi/ros2/runtime/_decode.py,sha256=zkJiA_fig-9XD4LxVF9PQs6gfGsEREQNEFN79oxEMjk,3812
|
|
7
|
+
opensmi/ros2/runtime/_encode.py,sha256=ITHmJxotBcasc5b62AvidNiEvvu484mwT6Cxn9OYozU,4236
|
|
8
|
+
opensmi/ros2/runtime/_parser.py,sha256=GOgX-GuVjftSTlUIbwKumSd5szDZwDum2mPKINbNmRo,6820
|
|
9
|
+
opensmi/ros2/runtime/errors.py,sha256=io-AZEkl1H4WX0XYPIB0QF0J3MM0FDmC86-czrOMUk0,4862
|
|
10
|
+
opensmi/ros2/runtime/goal.py,sha256=2gHnqTX149yqF33OlBvoay3qisCTgffOGOz8nBrOiHM,9216
|
|
11
|
+
opensmi/ros2/runtime/graph.py,sha256=SsDnNk-ay-o09p5L0tG1O83y-2Nbtj_hRWkKRnB5aAo,10933
|
|
12
|
+
opensmi/ros2/runtime/guard.py,sha256=OiFNyA7LJnF50MKnDc58MjeGRu6ssHSe1YuTLOfOq0U,8695
|
|
13
|
+
opensmi/ros2/runtime/interface.py,sha256=zkYR3hhxKxNbw3Gv9JCwt-MR8Os6Qc83lLa3dhMRQkI,4619
|
|
14
|
+
opensmi/ros2/runtime/outcomes.py,sha256=ZKCPREsmw0Zr_OgBOwe9t0tHJv0fSS7trx2PnEYkTAo,3454
|
|
15
|
+
opensmi/ros2/runtime/parameters.py,sha256=NHpls_fA4XvI6wMfiOQ_gdyhFDVRGesg4Teibxf4-w0,29312
|
|
16
|
+
opensmi/ros2/runtime/publisher.py,sha256=i5QIXz0l5X6Dnz0Z5EYpqCSzJvfyz6Oc1FPqj2cfHdI,4929
|
|
17
|
+
opensmi/ros2/runtime/qos.py,sha256=8KrqshQ1lA1dt9K1eFZ1MkKw7PFyrmNIWhprIfJm-30,15764
|
|
18
|
+
opensmi/ros2/runtime/runtime.py,sha256=bD2WalvPhvddN9gDCThi430aot5c7WqZ1Qq8lBuq-Y8,50318
|
|
19
|
+
opensmi/ros2/runtime/selection.py,sha256=Oh12xYP83zaoJXBmiCm0iMqjBr1_6atq7pZ6QrdA3bU,6304
|
|
20
|
+
opensmi/ros2/runtime/stamp.py,sha256=UBhIGTQP49tWjbhK58kLYtYlLDo4a37ig0vO6Tm2lXY,4175
|
|
21
|
+
opensmi/ros2/runtime/subscription.py,sha256=nMG5yC4iLt6u3vV4IY8ct-LNmkF22ddMK4zsP17FlXE,14144
|
|
22
|
+
opensmi/ros2/runtime/tf.py,sha256=q37yR36xt6GwW6Kion6sr9oqPtciQQarXbHLRAtGyA4,29984
|
|
23
|
+
opensmi/ros2/runtime/messages/__init__.py,sha256=Mlg1UHZYCsB07jJYyJfKdWYZogIk93_4IhT56s00P9E,18551
|
|
24
|
+
opensmi/ros2/runtime/messages/industrial_msgs.py,sha256=iDw00lgg6H74zRGWjf98HUFBOeRejrSG8bZU5BPf5vk,2873
|
|
25
|
+
opensmi/ros2/runtime/messages/industrial_msgs.pyi,sha256=NzYhvKrRd6lj9MWKZlAvy6JmTuCnEj3QEXzbUFNHRHQ,4565
|
|
26
|
+
opensmi/ros2/runtime/messages/motoros2_interfaces.py,sha256=MeSee7rNRsVh2XodRynUFnNlzgnx0YbEehzM4xtm438,4313
|
|
27
|
+
opensmi/ros2/runtime/messages/motoros2_interfaces.pyi,sha256=LDtjLOzfEdzshImmfB70oVGeeUdk0_3sSs4BwMWVEOY,8585
|
|
28
|
+
opensmi/ros2/runtime/messages/neo_msgs2.py,sha256=P0FJKGq-Lj8NGkTTpeAFw7bTGVx0r80_ueqwdEgfJpc,2119
|
|
29
|
+
opensmi/ros2/runtime/messages/neo_msgs2.pyi,sha256=hIrbe4DxVg2qnaO7OgQAGDrJfUDjwhgqr3v7y1Fdubs,3785
|
|
30
|
+
opensmi/ros2/runtime/messages/neo_srvs2.py,sha256=coBE-0FKthqXNayK4JMkMs6A0ksCuMxxm3HW_ZZJUYc,3771
|
|
31
|
+
opensmi/ros2/runtime/messages/neo_srvs2.pyi,sha256=JZhQyPy1bBNhaweXg-J6BmIax0gkZyZLze93jZ6TwDU,6485
|
|
32
|
+
opensmi/ros2/server/__init__.py,sha256=FHXvyzE7gtHcn4AgIq3ejnO2iacueADDTQry4Lfy9No,4923
|
|
33
|
+
opensmi/ros2/server/access.py,sha256=gzzleuHvgZoBzwE-BJaA8hBjjvtUfVKcDr2mRjqKFdw,5123
|
|
34
|
+
opensmi/ros2/server/browse_names.py,sha256=np4C54TDJQ5WE6O4vfyEZ_8v_ySB51EnxgZU7GdRGg0,3790
|
|
35
|
+
opensmi/ros2/server/component.py,sha256=uDkzVNWUX_9jpDQAEAxf9ODAbKG2E6jjfN-3woRcIzk,15979
|
|
36
|
+
opensmi/ros2/server/config.py,sha256=z1xs9DGTDRbH7CjLRj4g6gOtjkZsTW8RpCayJa-KB3Y,22321
|
|
37
|
+
opensmi/ros2/server/containers.py,sha256=aEO6F67hkQfcvYYTz-J5R--GZRerJwXE3tDp1jw8jkE,8005
|
|
38
|
+
opensmi/ros2/server/drivers.py,sha256=Nhm_FsQbaoW8rnWB2D-OPbDhE57hki7JglFRvEjhh4U,20004
|
|
39
|
+
opensmi/ros2/server/errors.py,sha256=SxE32k3NPHim8Ed2FDkLigcENpzWf3ha1N2NeOYMusM,6669
|
|
40
|
+
opensmi/ros2/server/events.py,sha256=jkJiX3g-UgTh5vltJxEZYr4z127MAOY9c430Hy0Hing,18027
|
|
41
|
+
opensmi/ros2/server/introspection.py,sha256=0H4Kvoks_addSMit0fWUNjdawvsYmjcCo7bmDiJfiqg,38318
|
|
42
|
+
opensmi/ros2/server/keyed.py,sha256=I9md_kbipm4Ni0vIXNQDso_wO4_0K0wxCanxAT-RswU,32987
|
|
43
|
+
opensmi/ros2/server/lifecycle.py,sha256=OkbTaF3emYLdwh-stglx8ZkWYIiSuYcwpnlwmwx6aNU,9307
|
|
44
|
+
opensmi/ros2/server/limits.py,sha256=bqkHXv8AvnISwAf_xgd-eRkPYJITX6YO2xJvmzJ-QHE,2766
|
|
45
|
+
opensmi/ros2/server/loader.py,sha256=YgpPJFCw0DAXRxQc6oJ03zCQmrn04c0GZvJJxQI39oE,39491
|
|
46
|
+
opensmi/ros2/server/machine.py,sha256=E7oMoDXDm3caFVbOlIfK4CXutA8lZXUqwVjDk9A4HAY,10823
|
|
47
|
+
opensmi/ros2/server/method.py,sha256=nk_xAf_4qS8N7SsGfyTrIkCzDHkDTL7JF9g6r4JT1tM,14962
|
|
48
|
+
opensmi/ros2/server/mirror.py,sha256=bRxUKGH_mKt0ih9aUpKUuMgmWRXfP1-76dLQ8klfFEU,27000
|
|
49
|
+
opensmi/ros2/server/mutation.py,sha256=4CgoZ_OiWwXuy-JL0RyFsxZ4fM4vIs56qOMCt8-q454,44796
|
|
50
|
+
opensmi/ros2/server/parameters.py,sha256=k6ndwc0KZnE0LvR2j7caPeeyVrBqDcqSsDe8T34AgCA,31917
|
|
51
|
+
opensmi/ros2/server/projection.py,sha256=LH6HvPlB1dow8-ZmaMsuhygn0vKYqWwM0Ahohk3xwg4,50341
|
|
52
|
+
opensmi/ros2/server/provenance.py,sha256=xZlhU7aqLY2bDDa4pt9E4GI8BabTfaFRb5GbYpJDMBk,5124
|
|
53
|
+
opensmi/ros2/server/publisher.py,sha256=2AqJs1aYKMRqUEj22f6ud1GFei2fcnvJMUmp6WX8xqM,36827
|
|
54
|
+
opensmi/ros2/server/recipes.py,sha256=4gc5dftcz5k8NR8gz1VlxsLNCTk31IDpMdKbFS-mbPo,22561
|
|
55
|
+
opensmi/ros2/server/required.py,sha256=KcXqXkzWz1Z9eUm1MA4IKDkT746W1T327WyvFJwfMKo,29954
|
|
56
|
+
opensmi/ros2/server/skill.py,sha256=ttsp98GZB6nmxDuVpnA8ojnlYmCpzNiE2rS1fqoPE9I,17607
|
|
57
|
+
opensmi/ros2/server/spatial.py,sha256=6g3Oq-vEaRJKjtQYMhx1dTkNwRcdpfm8BRCyt4K604g,11805
|
|
58
|
+
opensmi/ros2/server/startup.py,sha256=xeIrwrBooRf2ErHebhQdJ_cSR7CdJMUu2ttgaSa907k,28231
|
|
59
|
+
opensmi/ros2/server/status.py,sha256=M8jIbxtQ-RgOVPOWglVmNC6moqOP9f-f1gQYTRkGwyE,4806
|
|
60
|
+
opensmi/ros2/server/structures.py,sha256=bBkCUAbVUTgnEN0vsqk64vMlVgNBWE6kXwqIKUc6gf0,5283
|
|
61
|
+
opensmi/ros2/server/bindings/__init__.py,sha256=wV97tRddns_6-l-frIEFY-FZaAEDwXIwKZVpm9cPboc,4044
|
|
62
|
+
opensmi/ros2/server/bindings/_base.py,sha256=l2u4aO3tYk2EveGVotVxIGa5tB4056aIBhJ8GQyPZGA,6520
|
|
63
|
+
opensmi/ros2/server/bindings/action.py,sha256=OIvVn6VjDwX2wrkzoVp3nQUh5dsCauImjs4l9LBBhDY,6400
|
|
64
|
+
opensmi/ros2/server/bindings/keyed.py,sha256=mVoteGCnfVRV79cGzCeq26OMLsDv-HvR9N7O2ozcN0A,6521
|
|
65
|
+
opensmi/ros2/server/bindings/lifecycle.py,sha256=ecUwAFDM8xpwV5yjOp3Pn9VpfYYJeoaWMzOzZPgXlLA,6742
|
|
66
|
+
opensmi/ros2/server/bindings/method.py,sha256=UScrq-3fNkcB4eyzeo8SVHRQ7IM2Mz6bA1DGvF7PkiU,6486
|
|
67
|
+
opensmi/ros2/server/bindings/monitoring.py,sha256=b7_A64X1ByzawOyy7WKpCD_mfKdYu5B7y8tjNAeyuaQ,5879
|
|
68
|
+
opensmi/ros2/server/bindings/parameter.py,sha256=SrSAgL8IUbPCOA0d6rZc6Z8tt1TtWUdOErcwy2uF2ps,6670
|
|
69
|
+
opensmi/ros2/server/bindings/publisher.py,sha256=kZAQmxV6fn1VVf1htzM8lum4k7ZR8ZwTJrq09RaMvHg,10237
|
|
70
|
+
opensmi/ros2/server/bindings/registry.py,sha256=QXt5tgRRZaBKB2Vq_G7UxjvrrnylPMwXWC9XHXan7O8,3693
|
|
71
|
+
opensmi/ros2/server/bindings/tf.py,sha256=kEgMu3yzeqt0QxrJcEMOEPl1dUMNxpvkeedi_Puwpak,13249
|
|
72
|
+
opensmi/ros2/server/nodesets/Opc.Ua.SmartFactory.ROS2.NodeSet2.xml,sha256=C97p0c5f1AVnFgQI7VBjgezR81-HwOxWDu19yHmgb4s,4575
|
|
73
|
+
opensmi/ros2/server/nodesets/__init__.py,sha256=Se5E3zTtyUMSBdJN544foinCnbhpDwHiJ_k06DLjq5c,781
|
|
74
|
+
opensmi/ros2/server/nodesets/smart_factory_ros2.py,sha256=8KwrEDzWlFQbJ4K1JDtJ_q4RGARLR6OvEZj8KQ4t4YQ,937
|
|
75
|
+
opensmi/ros2/server/projections/__init__.py,sha256=YhiCWWgukwrLjeGMP-Lmf-_fVL0P9bQE6hn5LHnNU5g,1809
|
|
76
|
+
opensmi/ros2/server/projections/scope.py,sha256=JdvCMZQIU_GWF_ughJYNn20wwSx_3672YDJE_a67JAk,10211
|
|
77
|
+
opensmi/ros2/server/transforms/__init__.py,sha256=O4kG18Z6_SJp8Q8ZvF3MQ_0oSLQyiFektV0PGZynGv8,2160
|
|
78
|
+
opensmi/ros2/server/transforms/conversions.py,sha256=xL1hlhxPlbcuvYcOmtoHscgBmCS7fs_9dQy299mXc0I,2274
|
|
79
|
+
opensmi/ros2/server/transforms/filing.py,sha256=PFY039NsnPNX6zMHinIU6Ps5f3AZMQSPJrPAxOnNEmY,14184
|
|
80
|
+
opensmi/ros2/server/transforms/mirror.py,sha256=-TIJTzgBBU4yJkd0NKJw4Bu-VW8htVqbQTjLFYIGS5Y,20630
|
|
81
|
+
opensmi/ros2/server/transforms/outward.py,sha256=tLjcoMlO-NvI0EoRIbrrSfFeVqlZZ-6VvxTC42Z_N1w,8461
|
|
82
|
+
opensmi/ros2/server/transforms/records.py,sha256=cf_sdrtSQWUnS-V6-n7kzhdYR1ZV2YRrH80vFxZ7yn4,7121
|
|
83
|
+
opensmi/ros2/server/transforms/spatial.py,sha256=jQZabW6zC8R_S-DGiRDOFd1jfhkszj6Y99IVHMQq7Os,6726
|
|
84
|
+
opensmi_ros2-0.1.0.dist-info/licenses/LICENSES/MIT.txt,sha256=ALMo5wk71jfktt9hl5vWIAhOpNmQtLUvRtD_HoYeJKU,1100
|
|
85
|
+
opensmi_ros2-0.1.0.dist-info/METADATA,sha256=817bKJ0xDU4aYFqOmHbCDAk6UOkUJgPbiuJ_6WBhGKQ,11625
|
|
86
|
+
opensmi_ros2-0.1.0.dist-info/WHEEL,sha256=mOdXR9C3wMVov7cSY8PY-XCzo3SmmWCHvGQr5csJoao,91
|
|
87
|
+
opensmi_ros2-0.1.0.dist-info/entry_points.txt,sha256=3byp3ZoVAn1DdNkHNVRLUmahFt1bdkJPuGHbHMHS3UY,55
|
|
88
|
+
opensmi_ros2-0.1.0.dist-info/top_level.txt,sha256=RNwRHgN-Y6DKEdMS39Fx2JG5UVX9gQ0t2Cw8X8hmIqM,8
|
|
89
|
+
opensmi_ros2-0.1.0.dist-info/RECORD,,
|
|
@@ -0,0 +1,18 @@
|
|
|
1
|
+
MIT License
|
|
2
|
+
|
|
3
|
+
Copyright (c) 2026 Technologie-Initiative SmartFactory KL e.V.
|
|
4
|
+
|
|
5
|
+
Permission is hereby granted, free of charge, to any person obtaining a copy of this software and
|
|
6
|
+
associated documentation files (the "Software"), to deal in the Software without restriction, including
|
|
7
|
+
without limitation the rights to use, copy, modify, merge, publish, distribute, sublicense, and/or sell
|
|
8
|
+
copies of the Software, and to permit persons to whom the Software is furnished to do so, subject to the
|
|
9
|
+
following conditions:
|
|
10
|
+
|
|
11
|
+
The above copyright notice and this permission notice shall be included in all copies or substantial
|
|
12
|
+
portions of the Software.
|
|
13
|
+
|
|
14
|
+
THE SOFTWARE IS PROVIDED "AS IS", WITHOUT WARRANTY OF ANY KIND, EXPRESS OR IMPLIED, INCLUDING BUT NOT
|
|
15
|
+
LIMITED TO THE WARRANTIES OF MERCHANTABILITY, FITNESS FOR A PARTICULAR PURPOSE AND NONINFRINGEMENT. IN NO
|
|
16
|
+
EVENT SHALL THE AUTHORS OR COPYRIGHT HOLDERS BE LIABLE FOR ANY CLAIM, DAMAGES OR OTHER LIABILITY, WHETHER
|
|
17
|
+
IN AN ACTION OF CONTRACT, TORT OR OTHERWISE, ARISING FROM, OUT OF OR IN CONNECTION WITH THE SOFTWARE OR THE
|
|
18
|
+
USE OR OTHER DEALINGS IN THE SOFTWARE.
|
|
@@ -0,0 +1 @@
|
|
|
1
|
+
opensmi
|