stl2bem 0.1.0__tar.gz
This diff represents the content of publicly available package versions that have been released to one of the supported registries. The information contained in this diff is provided for informational purposes only and reflects changes between package versions as they appear in their respective public registries.
- stl2bem-0.1.0/LICENSE +21 -0
- stl2bem-0.1.0/PKG-INFO +205 -0
- stl2bem-0.1.0/README.md +161 -0
- stl2bem-0.1.0/pyproject.toml +47 -0
- stl2bem-0.1.0/setup.cfg +4 -0
- stl2bem-0.1.0/stl2bem/__init__.py +20 -0
- stl2bem-0.1.0/stl2bem/analysis.py +156 -0
- stl2bem-0.1.0/stl2bem/analytic.py +100 -0
- stl2bem-0.1.0/stl2bem/backend.py +116 -0
- stl2bem-0.1.0/stl2bem/bem_core.py +385 -0
- stl2bem-0.1.0/stl2bem/chief.py +117 -0
- stl2bem-0.1.0/stl2bem/kernels.py +322 -0
- stl2bem-0.1.0/stl2bem/panels.py +188 -0
- stl2bem-0.1.0/stl2bem/prep.py +115 -0
- stl2bem-0.1.0/stl2bem/run.py +241 -0
- stl2bem-0.1.0/stl2bem/shapes.py +146 -0
- stl2bem-0.1.0/stl2bem/sofa.py +88 -0
- stl2bem-0.1.0/stl2bem/stl_io.py +208 -0
- stl2bem-0.1.0/stl2bem/viz.py +119 -0
- stl2bem-0.1.0/stl2bem.egg-info/PKG-INFO +205 -0
- stl2bem-0.1.0/stl2bem.egg-info/SOURCES.txt +24 -0
- stl2bem-0.1.0/stl2bem.egg-info/dependency_links.txt +1 -0
- stl2bem-0.1.0/stl2bem.egg-info/entry_points.txt +3 -0
- stl2bem-0.1.0/stl2bem.egg-info/requires.txt +29 -0
- stl2bem-0.1.0/stl2bem.egg-info/top_level.txt +1 -0
- stl2bem-0.1.0/tests/test_core.py +368 -0
stl2bem-0.1.0/LICENSE
ADDED
|
@@ -0,0 +1,21 @@
|
|
|
1
|
+
MIT License
|
|
2
|
+
|
|
3
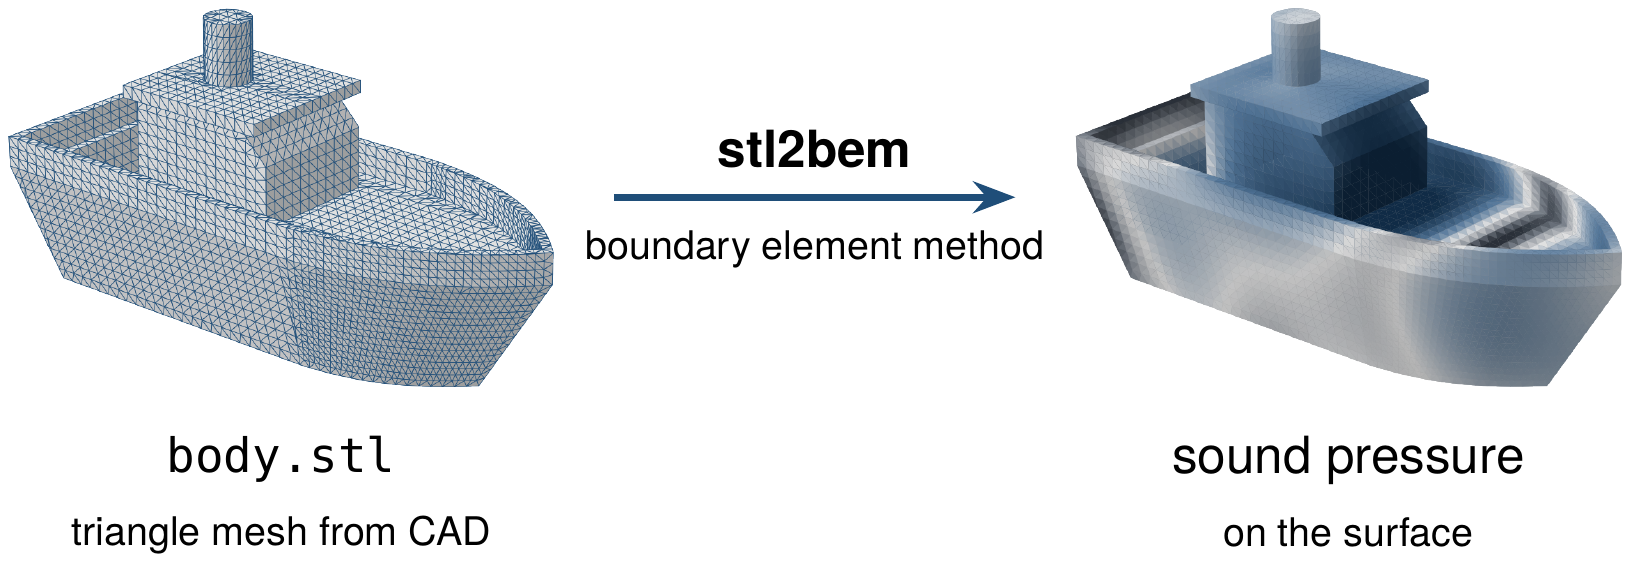
|
+
Copyright (c) 2026 Junhyeong Kwon
|
|
4
|
+
|
|
5
|
+
Permission is hereby granted, free of charge, to any person obtaining a copy
|
|
6
|
+
of this software and associated documentation files (the "Software"), to deal
|
|
7
|
+
in the Software without restriction, including without limitation the rights
|
|
8
|
+
to use, copy, modify, merge, publish, distribute, sublicense, and/or sell
|
|
9
|
+
copies of the Software, and to permit persons to whom the Software is
|
|
10
|
+
furnished to do so, subject to the following conditions:
|
|
11
|
+
|
|
12
|
+
The above copyright notice and this permission notice shall be included in all
|
|
13
|
+
copies or substantial portions of the Software.
|
|
14
|
+
|
|
15
|
+
THE SOFTWARE IS PROVIDED "AS IS", WITHOUT WARRANTY OF ANY KIND, EXPRESS OR
|
|
16
|
+
IMPLIED, INCLUDING BUT NOT LIMITED TO THE WARRANTIES OF MERCHANTABILITY,
|
|
17
|
+
FITNESS FOR A PARTICULAR PURPOSE AND NONINFRINGEMENT. IN NO EVENT SHALL THE
|
|
18
|
+
AUTHORS OR COPYRIGHT HOLDERS BE LIABLE FOR ANY CLAIM, DAMAGES OR OTHER
|
|
19
|
+
LIABILITY, WHETHER IN AN ACTION OF CONTRACT, TORT OR OTHERWISE, ARISING FROM,
|
|
20
|
+
OUT OF OR IN CONNECTION WITH THE SOFTWARE OR THE USE OR OTHER DEALINGS IN THE
|
|
21
|
+
SOFTWARE.
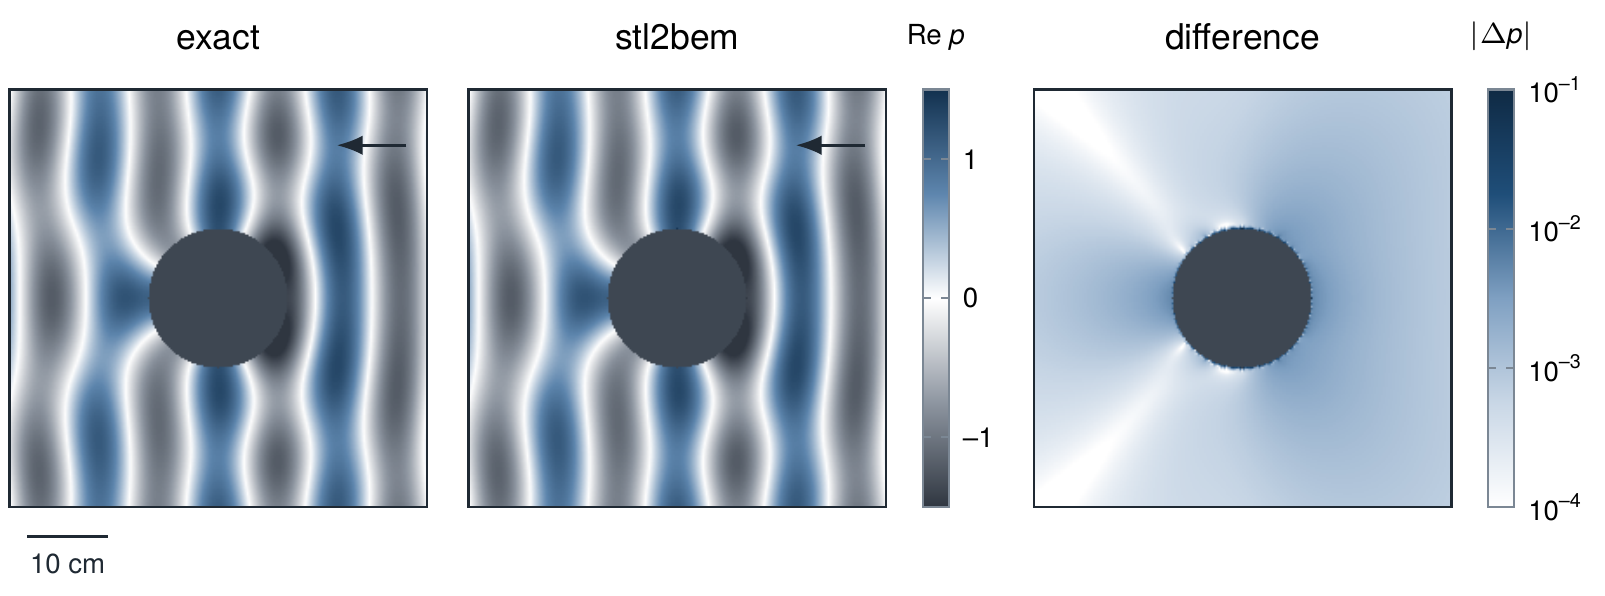
|
stl2bem-0.1.0/PKG-INFO
ADDED
|
@@ -0,0 +1,205 @@
|
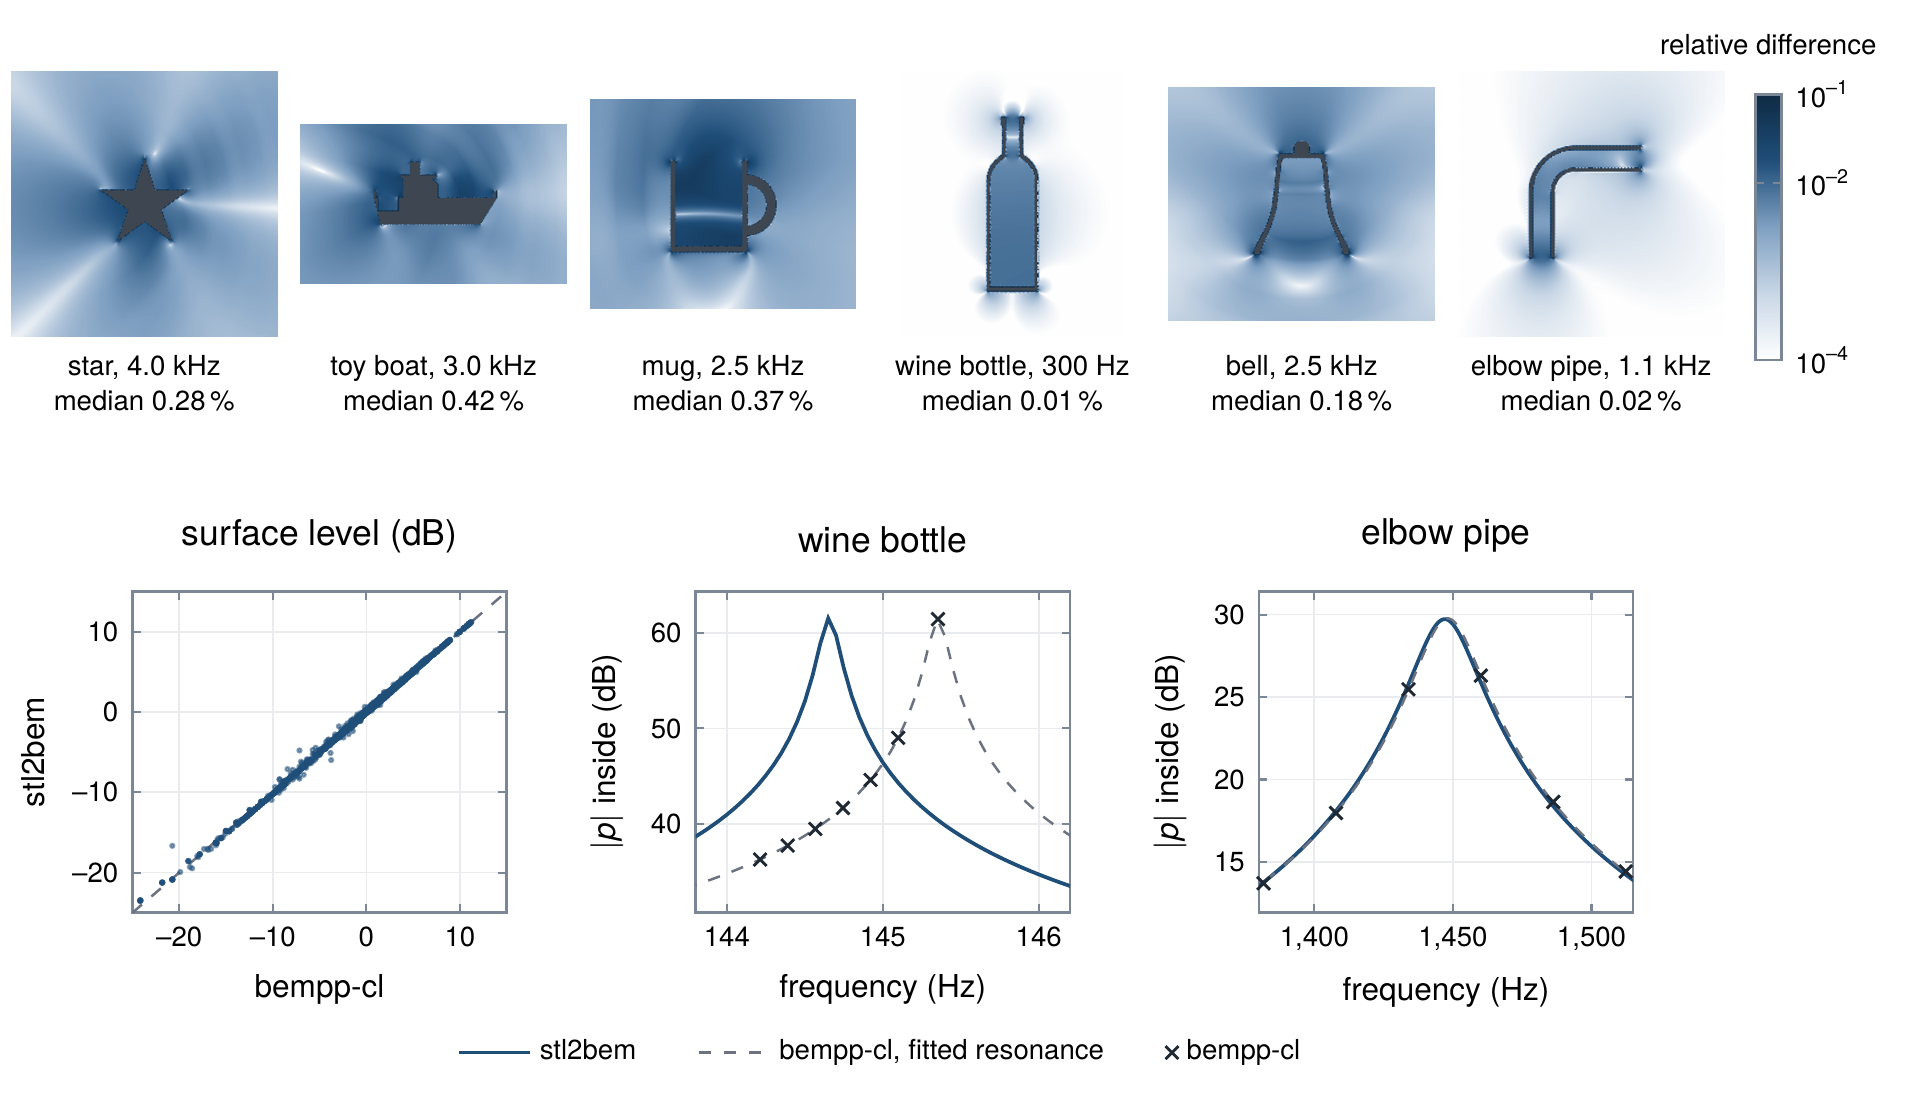
|
|
1
|
+
Metadata-Version: 2.4
|
|
2
|
+
Name: stl2bem
|
|
3
|
+
Version: 0.1.0
|
|
4
|
+
Summary: Boundary element solver for sound scattering by rigid objects given as closed STL meshes, on the CPU or GPU
|
|
5
|
+
Author: Junhyeong Kwon
|
|
6
|
+
License-Expression: MIT
|
|
7
|
+
Project-URL: Repository, https://github.com/Kwon-Junhyeong/stl2bem
|
|
8
|
+
Project-URL: Issues, https://github.com/Kwon-Junhyeong/stl2bem/issues
|
|
9
|
+
Keywords: acoustics,boundary element method,BEM,microphone array,steering vector,array manifold,scattering,direction of arrival,CHIEF,GPU
|
|
10
|
+
Classifier: Development Status :: 4 - Beta
|
|
11
|
+
Classifier: Intended Audience :: Science/Research
|
|
12
|
+
Classifier: Operating System :: OS Independent
|
|
13
|
+
Classifier: Programming Language :: Python :: 3
|
|
14
|
+
Classifier: Programming Language :: Python :: 3 :: Only
|
|
15
|
+
Classifier: Topic :: Scientific/Engineering :: Physics
|
|
16
|
+
Classifier: Topic :: Multimedia :: Sound/Audio :: Analysis
|
|
17
|
+
Requires-Python: >=3.10
|
|
18
|
+
Description-Content-Type: text/markdown
|
|
19
|
+
License-File: LICENSE
|
|
20
|
+
Requires-Dist: numpy>=1.22
|
|
21
|
+
Requires-Dist: scipy>=1.8
|
|
22
|
+
Requires-Dist: h5py>=3.0
|
|
23
|
+
Requires-Dist: tqdm
|
|
24
|
+
Provides-Extra: gpu
|
|
25
|
+
Requires-Dist: cupy-cuda12x; extra == "gpu"
|
|
26
|
+
Provides-Extra: prep
|
|
27
|
+
Requires-Dist: scikit-image>=0.19; extra == "prep"
|
|
28
|
+
Provides-Extra: plot
|
|
29
|
+
Requires-Dist: matplotlib; extra == "plot"
|
|
30
|
+
Requires-Dist: pillow; extra == "plot"
|
|
31
|
+
Provides-Extra: sofa
|
|
32
|
+
Requires-Dist: sofar>=1.1; extra == "sofa"
|
|
33
|
+
Provides-Extra: crosscheck
|
|
34
|
+
Requires-Dist: bempp-cl>=0.4; extra == "crosscheck"
|
|
35
|
+
Provides-Extra: dev
|
|
36
|
+
Requires-Dist: pytest; extra == "dev"
|
|
37
|
+
Requires-Dist: scikit-image>=0.19; extra == "dev"
|
|
38
|
+
Requires-Dist: matplotlib; extra == "dev"
|
|
39
|
+
Requires-Dist: pillow; extra == "dev"
|
|
40
|
+
Requires-Dist: sofar>=1.1; extra == "dev"
|
|
41
|
+
Requires-Dist: build; extra == "dev"
|
|
42
|
+
Requires-Dist: twine; extra == "dev"
|
|
43
|
+
Dynamic: license-file
|
|
44
|
+
|
|
45
|
+
# stl2bem
|
|
46
|
+
|
|
47
|
+
Computes the sound pressure on and around a rigid object from a closed STL mesh, with the boundary element method.
|
|
48
|
+
It runs on a CPU or an NVIDIA GPU and writes tables over directions and frequencies, for example the response of
|
|
49
|
+
every microphone on a device, as HDF5 or SOFA files.
|
|
50
|
+
|
|
51
|
+
|
|
52
|
+
|
|
53
|
+
<table>
|
|
54
|
+
<tr>
|
|
55
|
+
<td width="33%"><img src="https://raw.githubusercontent.com/Kwon-Junhyeong/stl2bem/main/docs/img/gallery_star.gif" alt="star, 4 kHz"></td>
|
|
56
|
+
<td width="33%"><img src="https://raw.githubusercontent.com/Kwon-Junhyeong/stl2bem/main/docs/img/gallery_boat.gif" alt="toy boat, 3 kHz"></td>
|
|
57
|
+
<td width="33%"><img src="https://raw.githubusercontent.com/Kwon-Junhyeong/stl2bem/main/docs/img/gallery_mug.gif" alt="mug, 2.5 kHz"></td>
|
|
58
|
+
</tr>
|
|
59
|
+
<tr>
|
|
60
|
+
<td align="center">star, 4 kHz</td><td align="center">toy boat, 3 kHz</td><td align="center">mug, 2.5 kHz</td>
|
|
61
|
+
</tr>
|
|
62
|
+
<tr>
|
|
63
|
+
<td><img src="https://raw.githubusercontent.com/Kwon-Junhyeong/stl2bem/main/docs/img/gallery_bottle.gif" alt="wine bottle, 144 Hz"></td>
|
|
64
|
+
<td><img src="https://raw.githubusercontent.com/Kwon-Junhyeong/stl2bem/main/docs/img/gallery_bell.gif" alt="bell, 2.5 kHz"></td>
|
|
65
|
+
<td><img src="https://raw.githubusercontent.com/Kwon-Junhyeong/stl2bem/main/docs/img/gallery_pipe.gif" alt="elbow pipe, 1.4 kHz"></td>
|
|
66
|
+
</tr>
|
|
67
|
+
<tr>
|
|
68
|
+
<td align="center">wine bottle, 144 Hz</td><td align="center">bell, 2.5 kHz</td><td align="center">elbow pipe, 1.4 kHz</td>
|
|
69
|
+
</tr>
|
|
70
|
+
</table>
|
|
71
|
+
|
|
72
|
+
Plane waves passing six objects modeled in Fusion (3,800 to 12,000 triangles each): real part of the total
|
|
73
|
+
pressure on a slice through each object, over one period. Surface pressure and cavity resonances of the same
|
|
74
|
+
objects are in [docs/validation.md](https://github.com/Kwon-Junhyeong/stl2bem/blob/main/docs/validation.md#gallery).
|
|
75
|
+
|
|
76
|
+
## Install
|
|
77
|
+
|
|
78
|
+
```bash
|
|
79
|
+
git clone https://github.com/Kwon-Junhyeong/stl2bem
|
|
80
|
+
cd stl2bem
|
|
81
|
+
pip install . # NumPy, SciPy, h5py (CPU)
|
|
82
|
+
pip install ".[prep,sofa]" # optional: merging CAD parts, SOFA export
|
|
83
|
+
pip install cupy-cuda12x # optional GPU backend; pick the CuPy package of your CUDA version
|
|
84
|
+
```
|
|
85
|
+
|
|
86
|
+
## Quick start
|
|
87
|
+
|
|
88
|
+
```bash
|
|
89
|
+
stl2bem --stl device.stl --units mm --mics mics.csv --out out/ --dry_run # check mesh, microphones, resources
|
|
90
|
+
stl2bem --stl device.stl --units mm --mics mics.csv --out out/ # 0-8 kHz, 1-degree direction grid
|
|
91
|
+
stl2bem --stl device.stl --units mm --mics mics.csv --out out/ --source_distance 0.5 # sources 0.5 m away
|
|
92
|
+
```
|
|
93
|
+
|
|
94
|
+
`mics.csv` has one `x, y, z` row per microphone, in the STL units; each microphone is moved to the closest point of
|
|
95
|
+
the surface. Without `--source_distance` the sources are plane waves (far field). The dry run prints the distance
|
|
96
|
+
2D²/λ beyond which that holds for your body; closer sources need `--source_distance`. It also estimates the
|
|
97
|
+
run time: the default grid of 65,160 directions takes minutes on a GPU but hours on a CPU, and `--n_el 19`
|
|
98
|
+
(10 degrees in elevation) makes a CPU run about eight times faster. `stl2bem --help` lists all options.
|
|
99
|
+
|
|
100
|
+
From Python:
|
|
101
|
+
|
|
102
|
+
```python
|
|
103
|
+
import numpy as np
|
|
104
|
+
from stl2bem import build_mesh, surface_receivers, solve_table, spherical_doa_grid
|
|
105
|
+
|
|
106
|
+
mesh = build_mesh("device.stl", units="mm", recenter="none")
|
|
107
|
+
mics, weights, _ = surface_receivers(np.loadtxt("mics.csv", delimiter=",") / 1000, mesh)
|
|
108
|
+
doa, az, el = spherical_doa_grid(360, 19) # 1 deg azimuth, 10 deg elevation
|
|
109
|
+
freqs = np.linspace(0, 4000, 129)
|
|
110
|
+
solve_table(mesh.verts, mesh.tris, mesh.centroids, mesh.normals, mesh.areas, freqs, doa, "table.h5",
|
|
111
|
+
receivers=mics, receiver_elements=weights)
|
|
112
|
+
```
|
|
113
|
+
|
|
114
|
+
The pressure on a plane through the body, as in the gallery:
|
|
115
|
+
|
|
116
|
+
```python
|
|
117
|
+
from stl2bem.viz import plane_grid, field_on_points
|
|
118
|
+
pts, shape = plane_grid(center=(0, 0, 0), u=(1, 0, 0), v=(0, 0, 1), half=(0.2, 0.2), n=(241, 241))
|
|
119
|
+
field = field_on_points(mesh, 2000.0, doa=(1, 0, 0), points=pts).reshape(shape) # NaN inside the body
|
|
120
|
+
```
|
|
121
|
+
|
|
122
|
+
The localization error that the body causes for a free-field SRP-PHAT:
|
|
123
|
+
|
|
124
|
+
```python
|
|
125
|
+
from stl2bem.analysis import load_table, free_field, doa_error, summarize
|
|
126
|
+
body = load_table("table.h5", elevations=[0])
|
|
127
|
+
print(summarize(doa_error(body, free_field(body), band=(300, 3000), method="srp-phat", search="azimuth")))
|
|
128
|
+
```
|
|
129
|
+
|
|
130
|
+
## Output
|
|
131
|
+
|
|
132
|
+
One HDF5 file per body:
|
|
133
|
+
|
|
134
|
+
| dataset | shape | meaning |
|
|
135
|
+
|---|---|---|
|
|
136
|
+
| `p` | (R, D, F) complex64 | total pressure at receiver r for source d at frequency f, relative to the incident pressure at the origin |
|
|
137
|
+
| `doa_grid` | (D, 3) | unit vectors towards the sources; az x el grids are stored az-major (`i_az * n_el + i_el`) |
|
|
138
|
+
| `source_positions` | (D, 3) | point sources only: their positions (m) |
|
|
139
|
+
| `freqs` | (F,) | Hz |
|
|
140
|
+
| `positions` | (R, 3) | where `p` is evaluated (m, mesh frame); `centroids` is an older name for the same array |
|
|
141
|
+
| `chief_points` | (N_c, 3) | only when CHIEF is used: the interior points |
|
|
142
|
+
|
|
143
|
+
Attributes hold the mesh report, the solver options and the convention. `--sofa` (or
|
|
144
|
+
`python -m stl2bem.sofa table.h5`) also writes the table as a SOFA file (AES69, GeneralTF).
|
|
145
|
+
|
|
146
|
+
**Convention.** e^{+jωt}, incident wave exp(+jk d·r). For a source signal s(t) from direction d, the FFT/STFT bin
|
|
147
|
+
(usual e^{-jωt} kernel) at microphone m is S(ω)·p[m, d, ω], so tables and FFT-domain signals combine directly
|
|
148
|
+
without conjugation. The phase reference is the center of the bounding box (`--recenter bbox`); `--recenter none`
|
|
149
|
+
keeps the CAD origin.
|
|
150
|
+
|
|
151
|
+
## Accuracy
|
|
152
|
+
|
|
153
|
+
|
|
154
|
+
|
|
155
|
+
Rigid sphere with 5,120 elements at ka = 3.7 against the exact solution: the median difference is 8.6 × 10⁻⁴ of
|
|
156
|
+
the incident amplitude. The singular part of the integrals is evaluated exactly, and microphones on the surface are
|
|
157
|
+
second-order accurate, also on edges and vertices.
|
|
158
|
+
|
|
159
|
+
|
|
160
|
+
|
|
161
|
+
The six gallery meshes solved again with [bempp-cl](https://github.com/bempp/bempp-cl), which uses a different
|
|
162
|
+
formulation (Burton-Miller, linear elements): the fields differ by 0.01-0.4 % (median) and the resonance
|
|
163
|
+
frequencies by at most 0.5 %. One frequency with 6,840 directions takes 1 s for 4,800 elements and 11 s for
|
|
164
|
+
14,700 on an RTX 4060 Ti (8 GB).
|
|
165
|
+
|
|
166
|
+
Convergence, the comparison with the original code, resonances and timings: [docs/validation.md](https://github.com/Kwon-Junhyeong/stl2bem/blob/main/docs/validation.md).
|
|
167
|
+
Equations and implementation: [docs/method.md](https://github.com/Kwon-Junhyeong/stl2bem/blob/main/docs/method.md).
|
|
168
|
+
|
|
169
|
+
## Preparing CAD
|
|
170
|
+
|
|
171
|
+
The solver needs one closed, consistently oriented surface. A single solid exported from CAD usually is one (all
|
|
172
|
+
gallery models are); an assembly usually is not, because its parts overlap. `stl2bem-prep` merges the parts:
|
|
173
|
+
|
|
174
|
+
```bash
|
|
175
|
+
stl2bem-prep chassis.stl board.stl battery.stl --pitch 8 --units mm --out body.stl
|
|
176
|
+
```
|
|
177
|
+
|
|
178
|
+
It voxelizes the parts (pitch = element size), fills enclosed cavities and extracts a closed surface. Features
|
|
179
|
+
smaller than the pitch disappear and thin plates become one pitch thick; `--align_z` keeps a flat microphone board
|
|
180
|
+
flat. In Fusion, set the maximum edge length of the STL export to about λ/6 at the highest frequency; the mesh
|
|
181
|
+
report prints the frequency limit from the mean edge length.
|
|
182
|
+
|
|
183
|
+
## Limits
|
|
184
|
+
|
|
185
|
+
* Rigid bodies in free space: no absorption, no vibrating surfaces, no floor or walls.
|
|
186
|
+
* Dense matrices: for N elements the GPU needs about 2.5 GB + 20 bytes × N² (an 8 GB GPU handles about 15,000
|
|
187
|
+
elements) and the CPU about 1.5 GB + 55 bytes × N² of RAM; time grows with N³. The dry run prints both.
|
|
188
|
+
* CHIEF points need room inside the body. Thin-walled objects (in the gallery, the bottle and the pipe) are solved
|
|
189
|
+
with the CBIE alone, which is safe there: their irregular frequencies start near c / 2t for wall thickness t,
|
|
190
|
+
far above the band the mesh resolves.
|
|
191
|
+
* `--formulation burton-miller` is experimental: as accurate as the default away from resonances, but it damps
|
|
192
|
+
sharp cavity resonances. See [docs/method.md](https://github.com/Kwon-Junhyeong/stl2bem/blob/main/docs/method.md#burton-miller-experimental-option).
|
|
193
|
+
|
|
194
|
+
## Used in
|
|
195
|
+
|
|
196
|
+
An earlier version of this solver computed the microphone responses of a robot body in:
|
|
197
|
+
|
|
198
|
+
* [robot-body-sound-localization](https://github.com/Kwon-Junhyeong/robot-body-sound-localization): direction of
|
|
199
|
+
a speaker from four microphones on a robot body, by matching recordings to the computed responses.
|
|
200
|
+
* [calibration-free-sound-localization](https://github.com/Kwon-Junhyeong/calibration-free-sound-localization):
|
|
201
|
+
the same task without calibrating the microphone channels.
|
|
202
|
+
|
|
203
|
+
## License
|
|
204
|
+
|
|
205
|
+
MIT (see [LICENSE](https://github.com/Kwon-Junhyeong/stl2bem/blob/main/LICENSE)).
|
stl2bem-0.1.0/README.md
ADDED
|
@@ -0,0 +1,161 @@
|
|
|
1
|
+
# stl2bem
|
|
2
|
+
|
|
3
|
+
Computes the sound pressure on and around a rigid object from a closed STL mesh, with the boundary element method.
|
|
4
|
+
It runs on a CPU or an NVIDIA GPU and writes tables over directions and frequencies, for example the response of
|
|
5
|
+
every microphone on a device, as HDF5 or SOFA files.
|
|
6
|
+
|
|
7
|
+

|
|
8
|
+
|
|
9
|
+
<table>
|
|
10
|
+
<tr>
|
|
11
|
+
<td width="33%"><img src="https://raw.githubusercontent.com/Kwon-Junhyeong/stl2bem/main/docs/img/gallery_star.gif" alt="star, 4 kHz"></td>
|
|
12
|
+
<td width="33%"><img src="https://raw.githubusercontent.com/Kwon-Junhyeong/stl2bem/main/docs/img/gallery_boat.gif" alt="toy boat, 3 kHz"></td>
|
|
13
|
+
<td width="33%"><img src="https://raw.githubusercontent.com/Kwon-Junhyeong/stl2bem/main/docs/img/gallery_mug.gif" alt="mug, 2.5 kHz"></td>
|
|
14
|
+
</tr>
|
|
15
|
+
<tr>
|
|
16
|
+
<td align="center">star, 4 kHz</td><td align="center">toy boat, 3 kHz</td><td align="center">mug, 2.5 kHz</td>
|
|
17
|
+
</tr>
|
|
18
|
+
<tr>
|
|
19
|
+
<td><img src="https://raw.githubusercontent.com/Kwon-Junhyeong/stl2bem/main/docs/img/gallery_bottle.gif" alt="wine bottle, 144 Hz"></td>
|
|
20
|
+
<td><img src="https://raw.githubusercontent.com/Kwon-Junhyeong/stl2bem/main/docs/img/gallery_bell.gif" alt="bell, 2.5 kHz"></td>
|
|
21
|
+
<td><img src="https://raw.githubusercontent.com/Kwon-Junhyeong/stl2bem/main/docs/img/gallery_pipe.gif" alt="elbow pipe, 1.4 kHz"></td>
|
|
22
|
+
</tr>
|
|
23
|
+
<tr>
|
|
24
|
+
<td align="center">wine bottle, 144 Hz</td><td align="center">bell, 2.5 kHz</td><td align="center">elbow pipe, 1.4 kHz</td>
|
|
25
|
+
</tr>
|
|
26
|
+
</table>
|
|
27
|
+
|
|
28
|
+
Plane waves passing six objects modeled in Fusion (3,800 to 12,000 triangles each): real part of the total
|
|
29
|
+
pressure on a slice through each object, over one period. Surface pressure and cavity resonances of the same
|
|
30
|
+
objects are in [docs/validation.md](https://github.com/Kwon-Junhyeong/stl2bem/blob/main/docs/validation.md#gallery).
|
|
31
|
+
|
|
32
|
+
## Install
|
|
33
|
+
|
|
34
|
+
```bash
|
|
35
|
+
git clone https://github.com/Kwon-Junhyeong/stl2bem
|
|
36
|
+
cd stl2bem
|
|
37
|
+
pip install . # NumPy, SciPy, h5py (CPU)
|
|
38
|
+
pip install ".[prep,sofa]" # optional: merging CAD parts, SOFA export
|
|
39
|
+
pip install cupy-cuda12x # optional GPU backend; pick the CuPy package of your CUDA version
|
|
40
|
+
```
|
|
41
|
+
|
|
42
|
+
## Quick start
|
|
43
|
+
|
|
44
|
+
```bash
|
|
45
|
+
stl2bem --stl device.stl --units mm --mics mics.csv --out out/ --dry_run # check mesh, microphones, resources
|
|
46
|
+
stl2bem --stl device.stl --units mm --mics mics.csv --out out/ # 0-8 kHz, 1-degree direction grid
|
|
47
|
+
stl2bem --stl device.stl --units mm --mics mics.csv --out out/ --source_distance 0.5 # sources 0.5 m away
|
|
48
|
+
```
|
|
49
|
+
|
|
50
|
+
`mics.csv` has one `x, y, z` row per microphone, in the STL units; each microphone is moved to the closest point of
|
|
51
|
+
the surface. Without `--source_distance` the sources are plane waves (far field). The dry run prints the distance
|
|
52
|
+
2D²/λ beyond which that holds for your body; closer sources need `--source_distance`. It also estimates the
|
|
53
|
+
run time: the default grid of 65,160 directions takes minutes on a GPU but hours on a CPU, and `--n_el 19`
|
|
54
|
+
(10 degrees in elevation) makes a CPU run about eight times faster. `stl2bem --help` lists all options.
|
|
55
|
+
|
|
56
|
+
From Python:
|
|
57
|
+
|
|
58
|
+
```python
|
|
59
|
+
import numpy as np
|
|
60
|
+
from stl2bem import build_mesh, surface_receivers, solve_table, spherical_doa_grid
|
|
61
|
+
|
|
62
|
+
mesh = build_mesh("device.stl", units="mm", recenter="none")
|
|
63
|
+
mics, weights, _ = surface_receivers(np.loadtxt("mics.csv", delimiter=",") / 1000, mesh)
|
|
64
|
+
doa, az, el = spherical_doa_grid(360, 19) # 1 deg azimuth, 10 deg elevation
|
|
65
|
+
freqs = np.linspace(0, 4000, 129)
|
|
66
|
+
solve_table(mesh.verts, mesh.tris, mesh.centroids, mesh.normals, mesh.areas, freqs, doa, "table.h5",
|
|
67
|
+
receivers=mics, receiver_elements=weights)
|
|
68
|
+
```
|
|
69
|
+
|
|
70
|
+
The pressure on a plane through the body, as in the gallery:
|
|
71
|
+
|
|
72
|
+
```python
|
|
73
|
+
from stl2bem.viz import plane_grid, field_on_points
|
|
74
|
+
pts, shape = plane_grid(center=(0, 0, 0), u=(1, 0, 0), v=(0, 0, 1), half=(0.2, 0.2), n=(241, 241))
|
|
75
|
+
field = field_on_points(mesh, 2000.0, doa=(1, 0, 0), points=pts).reshape(shape) # NaN inside the body
|
|
76
|
+
```
|
|
77
|
+
|
|
78
|
+
The localization error that the body causes for a free-field SRP-PHAT:
|
|
79
|
+
|
|
80
|
+
```python
|
|
81
|
+
from stl2bem.analysis import load_table, free_field, doa_error, summarize
|
|
82
|
+
body = load_table("table.h5", elevations=[0])
|
|
83
|
+
print(summarize(doa_error(body, free_field(body), band=(300, 3000), method="srp-phat", search="azimuth")))
|
|
84
|
+
```
|
|
85
|
+
|
|
86
|
+
## Output
|
|
87
|
+
|
|
88
|
+
One HDF5 file per body:
|
|
89
|
+
|
|
90
|
+
| dataset | shape | meaning |
|
|
91
|
+
|---|---|---|
|
|
92
|
+
| `p` | (R, D, F) complex64 | total pressure at receiver r for source d at frequency f, relative to the incident pressure at the origin |
|
|
93
|
+
| `doa_grid` | (D, 3) | unit vectors towards the sources; az x el grids are stored az-major (`i_az * n_el + i_el`) |
|
|
94
|
+
| `source_positions` | (D, 3) | point sources only: their positions (m) |
|
|
95
|
+
| `freqs` | (F,) | Hz |
|
|
96
|
+
| `positions` | (R, 3) | where `p` is evaluated (m, mesh frame); `centroids` is an older name for the same array |
|
|
97
|
+
| `chief_points` | (N_c, 3) | only when CHIEF is used: the interior points |
|
|
98
|
+
|
|
99
|
+
Attributes hold the mesh report, the solver options and the convention. `--sofa` (or
|
|
100
|
+
`python -m stl2bem.sofa table.h5`) also writes the table as a SOFA file (AES69, GeneralTF).
|
|
101
|
+
|
|
102
|
+
**Convention.** e^{+jωt}, incident wave exp(+jk d·r). For a source signal s(t) from direction d, the FFT/STFT bin
|
|
103
|
+
(usual e^{-jωt} kernel) at microphone m is S(ω)·p[m, d, ω], so tables and FFT-domain signals combine directly
|
|
104
|
+
without conjugation. The phase reference is the center of the bounding box (`--recenter bbox`); `--recenter none`
|
|
105
|
+
keeps the CAD origin.
|
|
106
|
+
|
|
107
|
+
## Accuracy
|
|
108
|
+
|
|
109
|
+

|
|
110
|
+
|
|
111
|
+
Rigid sphere with 5,120 elements at ka = 3.7 against the exact solution: the median difference is 8.6 × 10⁻⁴ of
|
|
112
|
+
the incident amplitude. The singular part of the integrals is evaluated exactly, and microphones on the surface are
|
|
113
|
+
second-order accurate, also on edges and vertices.
|
|
114
|
+
|
|
115
|
+

|
|
116
|
+
|
|
117
|
+
The six gallery meshes solved again with [bempp-cl](https://github.com/bempp/bempp-cl), which uses a different
|
|
118
|
+
formulation (Burton-Miller, linear elements): the fields differ by 0.01-0.4 % (median) and the resonance
|
|
119
|
+
frequencies by at most 0.5 %. One frequency with 6,840 directions takes 1 s for 4,800 elements and 11 s for
|
|
120
|
+
14,700 on an RTX 4060 Ti (8 GB).
|
|
121
|
+
|
|
122
|
+
Convergence, the comparison with the original code, resonances and timings: [docs/validation.md](https://github.com/Kwon-Junhyeong/stl2bem/blob/main/docs/validation.md).
|
|
123
|
+
Equations and implementation: [docs/method.md](https://github.com/Kwon-Junhyeong/stl2bem/blob/main/docs/method.md).
|
|
124
|
+
|
|
125
|
+
## Preparing CAD
|
|
126
|
+
|
|
127
|
+
The solver needs one closed, consistently oriented surface. A single solid exported from CAD usually is one (all
|
|
128
|
+
gallery models are); an assembly usually is not, because its parts overlap. `stl2bem-prep` merges the parts:
|
|
129
|
+
|
|
130
|
+
```bash
|
|
131
|
+
stl2bem-prep chassis.stl board.stl battery.stl --pitch 8 --units mm --out body.stl
|
|
132
|
+
```
|
|
133
|
+
|
|
134
|
+
It voxelizes the parts (pitch = element size), fills enclosed cavities and extracts a closed surface. Features
|
|
135
|
+
smaller than the pitch disappear and thin plates become one pitch thick; `--align_z` keeps a flat microphone board
|
|
136
|
+
flat. In Fusion, set the maximum edge length of the STL export to about λ/6 at the highest frequency; the mesh
|
|
137
|
+
report prints the frequency limit from the mean edge length.
|
|
138
|
+
|
|
139
|
+
## Limits
|
|
140
|
+
|
|
141
|
+
* Rigid bodies in free space: no absorption, no vibrating surfaces, no floor or walls.
|
|
142
|
+
* Dense matrices: for N elements the GPU needs about 2.5 GB + 20 bytes × N² (an 8 GB GPU handles about 15,000
|
|
143
|
+
elements) and the CPU about 1.5 GB + 55 bytes × N² of RAM; time grows with N³. The dry run prints both.
|
|
144
|
+
* CHIEF points need room inside the body. Thin-walled objects (in the gallery, the bottle and the pipe) are solved
|
|
145
|
+
with the CBIE alone, which is safe there: their irregular frequencies start near c / 2t for wall thickness t,
|
|
146
|
+
far above the band the mesh resolves.
|
|
147
|
+
* `--formulation burton-miller` is experimental: as accurate as the default away from resonances, but it damps
|
|
148
|
+
sharp cavity resonances. See [docs/method.md](https://github.com/Kwon-Junhyeong/stl2bem/blob/main/docs/method.md#burton-miller-experimental-option).
|
|
149
|
+
|
|
150
|
+
## Used in
|
|
151
|
+
|
|
152
|
+
An earlier version of this solver computed the microphone responses of a robot body in:
|
|
153
|
+
|
|
154
|
+
* [robot-body-sound-localization](https://github.com/Kwon-Junhyeong/robot-body-sound-localization): direction of
|
|
155
|
+
a speaker from four microphones on a robot body, by matching recordings to the computed responses.
|
|
156
|
+
* [calibration-free-sound-localization](https://github.com/Kwon-Junhyeong/calibration-free-sound-localization):
|
|
157
|
+
the same task without calibrating the microphone channels.
|
|
158
|
+
|
|
159
|
+
## License
|
|
160
|
+
|
|
161
|
+
MIT (see [LICENSE](https://github.com/Kwon-Junhyeong/stl2bem/blob/main/LICENSE)).
|
|
@@ -0,0 +1,47 @@
|
|
|
1
|
+
[build-system]
|
|
2
|
+
requires = ["setuptools>=77"]
|
|
3
|
+
build-backend = "setuptools.build_meta"
|
|
4
|
+
|
|
5
|
+
[project]
|
|
6
|
+
name = "stl2bem"
|
|
7
|
+
version = "0.1.0"
|
|
8
|
+
description = "Boundary element solver for sound scattering by rigid objects given as closed STL meshes, on the CPU or GPU"
|
|
9
|
+
readme = "README.md"
|
|
10
|
+
requires-python = ">=3.10"
|
|
11
|
+
license = "MIT"
|
|
12
|
+
license-files = ["LICENSE"]
|
|
13
|
+
authors = [{ name = "Junhyeong Kwon" }]
|
|
14
|
+
keywords = ["acoustics", "boundary element method", "BEM", "microphone array", "steering vector",
|
|
15
|
+
"array manifold", "scattering", "direction of arrival", "CHIEF", "GPU"]
|
|
16
|
+
classifiers = [
|
|
17
|
+
"Development Status :: 4 - Beta",
|
|
18
|
+
"Intended Audience :: Science/Research",
|
|
19
|
+
"Operating System :: OS Independent",
|
|
20
|
+
"Programming Language :: Python :: 3",
|
|
21
|
+
"Programming Language :: Python :: 3 :: Only",
|
|
22
|
+
"Topic :: Scientific/Engineering :: Physics",
|
|
23
|
+
"Topic :: Multimedia :: Sound/Audio :: Analysis",
|
|
24
|
+
]
|
|
25
|
+
dependencies = ["numpy>=1.22", "scipy>=1.8", "h5py>=3.0", "tqdm"]
|
|
26
|
+
|
|
27
|
+
[project.optional-dependencies]
|
|
28
|
+
gpu = ["cupy-cuda12x"] # CUDA 12; for other CUDA versions install the matching CuPy
|
|
29
|
+
prep = ["scikit-image>=0.19"]
|
|
30
|
+
plot = ["matplotlib", "pillow"]
|
|
31
|
+
sofa = ["sofar>=1.1"]
|
|
32
|
+
crosscheck = ["bempp-cl>=0.4"]
|
|
33
|
+
dev = ["pytest", "scikit-image>=0.19", "matplotlib", "pillow", "sofar>=1.1", "build", "twine"]
|
|
34
|
+
|
|
35
|
+
[project.urls]
|
|
36
|
+
Repository = "https://github.com/Kwon-Junhyeong/stl2bem"
|
|
37
|
+
Issues = "https://github.com/Kwon-Junhyeong/stl2bem/issues"
|
|
38
|
+
|
|
39
|
+
[project.scripts]
|
|
40
|
+
stl2bem = "stl2bem.run:main"
|
|
41
|
+
stl2bem-prep = "stl2bem.prep:main"
|
|
42
|
+
|
|
43
|
+
[tool.setuptools]
|
|
44
|
+
packages = ["stl2bem"]
|
|
45
|
+
|
|
46
|
+
[tool.pytest.ini_options]
|
|
47
|
+
testpaths = ["tests"]
|
stl2bem-0.1.0/setup.cfg
ADDED
|
@@ -0,0 +1,20 @@
|
|
|
1
|
+
"""stl2bem: sound scattering by rigid objects from STL files (CBIE + CHIEF boundary element method), for plane
|
|
2
|
+
waves (far field) or point sources (near field), on the GPU (CuPy) or the CPU (NumPy)."""
|
|
3
|
+
from .analytic import rigid_sphere, rigid_sphere_point
|
|
4
|
+
from .backend import HAS_CUPY, Backend, gpu_available
|
|
5
|
+
from .bem_core import (compute_p_total_panel_major, estimate_cost, solve_table,
|
|
6
|
+
spherical_doa_grid, write_free_field)
|
|
7
|
+
from .chief import chief_points, points_inside
|
|
8
|
+
from .panels import (auto_panel_targets, load_mic_positions, map_to_elements, project_to_surface,
|
|
9
|
+
surface_receivers)
|
|
10
|
+
from .stl_io import Mesh, build_mesh, mesh_from_arrays, read_stl, write_stl
|
|
11
|
+
|
|
12
|
+
__version__ = "0.1.0"
|
|
13
|
+
|
|
14
|
+
__all__ = [
|
|
15
|
+
"build_mesh", "mesh_from_arrays", "read_stl", "write_stl", "Mesh",
|
|
16
|
+
"chief_points", "points_inside",
|
|
17
|
+
"load_mic_positions", "auto_panel_targets", "map_to_elements", "project_to_surface", "surface_receivers",
|
|
18
|
+
"spherical_doa_grid", "estimate_cost", "solve_table", "compute_p_total_panel_major",
|
|
19
|
+
"write_free_field", "rigid_sphere", "rigid_sphere_point", "Backend", "HAS_CUPY", "gpu_available",
|
|
20
|
+
]
|
|
@@ -0,0 +1,156 @@
|
|
|
1
|
+
"""Analysis of response tables: loading, free-field references, direction-of-arrival error caused by the body.
|
|
2
|
+
|
|
3
|
+
Typical question: an array is mounted on a device; the localization algorithm uses free-field steering vectors
|
|
4
|
+
(microphone positions only). How far off are its estimates because of the body? `doa_error` feeds the table of the
|
|
5
|
+
body (the "truth") to an estimator steered with another model (free field, or another table) and returns the angular
|
|
6
|
+
error per source direction.
|
|
7
|
+
|
|
8
|
+
from stl2bem.analysis import load_table, free_field, doa_error
|
|
9
|
+
body = load_table("p_total_robot_..._4panel.h5")
|
|
10
|
+
err = doa_error(body, free_field(body), band=(300, 2600), method="srp-phat", search="azimuth")
|
|
11
|
+
"""
|
|
12
|
+
from __future__ import annotations
|
|
13
|
+
|
|
14
|
+
from dataclasses import dataclass, field
|
|
15
|
+
|
|
16
|
+
import h5py
|
|
17
|
+
import numpy as np
|
|
18
|
+
|
|
19
|
+
|
|
20
|
+
@dataclass
|
|
21
|
+
class Table:
|
|
22
|
+
p: np.ndarray # (R, D, F) complex, package convention (see bem_core.CONVENTION)
|
|
23
|
+
doa: np.ndarray # (D, 3) unit vectors towards the source
|
|
24
|
+
freqs: np.ndarray # (F,)
|
|
25
|
+
positions: np.ndarray # (R, 3) receiver positions [m]
|
|
26
|
+
attrs: dict = field(default_factory=dict)
|
|
27
|
+
sources: np.ndarray | None = None # (D, 3) point-source positions [m] (near field); None for plane waves
|
|
28
|
+
|
|
29
|
+
@property
|
|
30
|
+
def az_el(self):
|
|
31
|
+
"""(azimuth, elevation) in degrees of every direction."""
|
|
32
|
+
az = np.degrees(np.arctan2(self.doa[:, 1], self.doa[:, 0])) % 360
|
|
33
|
+
el = np.degrees(np.arcsin(np.clip(self.doa[:, 2], -1, 1)))
|
|
34
|
+
return az, el
|
|
35
|
+
|
|
36
|
+
def select(self, receivers=None, doa=None, freqs=None) -> "Table":
|
|
37
|
+
r = slice(None) if receivers is None else receivers
|
|
38
|
+
d = slice(None) if doa is None else doa
|
|
39
|
+
f = slice(None) if freqs is None else freqs
|
|
40
|
+
return Table(self.p[r][:, d][:, :, f], self.doa[d], self.freqs[f], self.positions[r], dict(self.attrs),
|
|
41
|
+
None if self.sources is None else self.sources[d])
|
|
42
|
+
|
|
43
|
+
|
|
44
|
+
def load_table(path, receivers=None, elevations=None, band=None) -> Table:
|
|
45
|
+
"""Read a table; optionally only some receivers, the directions at given elevations (degrees, nearest grid
|
|
46
|
+
row of an az x el grid) and the frequencies within band=(lo, hi) Hz. Reads only what is needed."""
|
|
47
|
+
with h5py.File(path, "r") as f:
|
|
48
|
+
doa = f["doa_grid"][:].astype(np.float64)
|
|
49
|
+
freqs = f["freqs"][:].astype(np.float64)
|
|
50
|
+
pos = (f["positions"] if "positions" in f else f["centroids"])[:].astype(np.float64)
|
|
51
|
+
attrs = {k: (v.decode() if isinstance(v, bytes) else v) for k, v in f.attrs.items()}
|
|
52
|
+
r_idx = np.arange(len(pos)) if receivers is None else np.asarray(receivers)
|
|
53
|
+
if elevations is not None:
|
|
54
|
+
el = np.degrees(np.arcsin(np.clip(doa[:, 2], -1, 1)))
|
|
55
|
+
levels = np.unique(np.round(el, 6))
|
|
56
|
+
d_idx = np.concatenate([np.nonzero(np.isclose(el, levels[np.argmin(np.abs(levels - e))]))[0]
|
|
57
|
+
for e in np.atleast_1d(elevations)])
|
|
58
|
+
else:
|
|
59
|
+
d_idx = np.arange(len(doa))
|
|
60
|
+
f_idx = (np.arange(len(freqs)) if band is None
|
|
61
|
+
else np.nonzero((freqs >= band[0]) & (freqs <= band[1]))[0])
|
|
62
|
+
p = f["p"][np.sort(r_idx)][:, np.sort(d_idx)][:, :, np.sort(f_idx)]
|
|
63
|
+
src = f["source_positions"][:][np.sort(d_idx)] if "source_positions" in f else None
|
|
64
|
+
return Table(p, doa[np.sort(d_idx)], freqs[np.sort(f_idx)], pos[np.sort(r_idx)], attrs, src)
|
|
65
|
+
|
|
66
|
+
|
|
67
|
+
def free_field(t: Table, positions=None, doa=None, c: float = 343.0) -> Table:
|
|
68
|
+
"""Free-field table (no body) at the given (or the table's) receiver positions and directions; point sources
|
|
69
|
+
if the table has them (same normalization as the solver: 1 at the origin)."""
|
|
70
|
+
pos = t.positions if positions is None else np.asarray(positions, np.float64)
|
|
71
|
+
k = 2 * np.pi * t.freqs / c
|
|
72
|
+
if t.sources is not None and doa is None:
|
|
73
|
+
s = t.sources
|
|
74
|
+
r = np.linalg.norm(pos[:, None] - s[None], axis=2) # (R, D)
|
|
75
|
+
r0 = np.linalg.norm(s, axis=1)[None]
|
|
76
|
+
dr = ((pos * pos).sum(1)[:, None] - 2 * pos @ s.T) / (r + r0)
|
|
77
|
+
p = (r0 / r)[:, :, None] * np.exp(-1j * dr[:, :, None] * k[None, None, :])
|
|
78
|
+
return Table(p, t.doa.copy(), t.freqs.copy(), pos, {"mesh_type": "free_field"}, s.copy())
|
|
79
|
+
d = t.doa if doa is None else np.asarray(doa, np.float64)
|
|
80
|
+
p = np.exp(1j * (pos @ d.T)[:, :, None] * k[None, None, :])
|
|
81
|
+
return Table(p, d, t.freqs.copy(), pos, {"mesh_type": "free_field"})
|
|
82
|
+
|
|
83
|
+
|
|
84
|
+
def azimuth_ring(n: int = 360, elevation_deg: float = 0.0) -> np.ndarray:
|
|
85
|
+
a = np.radians(np.arange(n) * 360.0 / n)
|
|
86
|
+
e = np.radians(elevation_deg)
|
|
87
|
+
return np.column_stack([np.cos(e) * np.cos(a), np.cos(e) * np.sin(a), np.full(n, np.sin(e))])
|
|
88
|
+
|
|
89
|
+
|
|
90
|
+
def _srp_phat(X, S):
|
|
91
|
+
"""X (R, F) one source; S (R, G, F) steering. Sum over microphone pairs and bins of PHAT-weighted cross-spectra
|
|
92
|
+
projected on the steering phases (DiBiase 2000)."""
|
|
93
|
+
R = X.shape[0]
|
|
94
|
+
out = np.zeros(S.shape[1])
|
|
95
|
+
for i in range(R):
|
|
96
|
+
for j in range(i + 1, R):
|
|
97
|
+
g = X[i] * np.conj(X[j])
|
|
98
|
+
g = g / (np.abs(g) + 1e-30)
|
|
99
|
+
s = S[i] * np.conj(S[j])
|
|
100
|
+
s = s / (np.abs(s) + 1e-30)
|
|
101
|
+
out += np.real(np.conj(s) @ g)
|
|
102
|
+
return out
|
|
103
|
+
|
|
104
|
+
|
|
105
|
+
def _music(X, S, n_src: int = 1):
|
|
106
|
+
"""Narrowband MUSIC per bin with the rank-one covariance of X, pseudo-spectra normalized and averaged."""
|
|
107
|
+
R, F = X.shape
|
|
108
|
+
out = np.zeros(S.shape[1])
|
|
109
|
+
for fi in range(F):
|
|
110
|
+
x = X[:, fi:fi + 1]
|
|
111
|
+
C = x @ x.conj().T + 1e-9 * np.real(np.vdot(x, x)) * np.eye(R)
|
|
112
|
+
w, V = np.linalg.eigh(C)
|
|
113
|
+
En = V[:, : R - n_src]
|
|
114
|
+
a = S[:, :, fi]
|
|
115
|
+
a = a / (np.linalg.norm(a, axis=0, keepdims=True) + 1e-30)
|
|
116
|
+
ps = 1.0 / (np.sum(np.abs(En.conj().T @ a) ** 2, axis=0) + 1e-12)
|
|
117
|
+
out += ps / ps.max()
|
|
118
|
+
return out
|
|
119
|
+
|
|
120
|
+
|
|
121
|
+
def angle_between(u, v) -> np.ndarray:
|
|
122
|
+
return np.degrees(np.arccos(np.clip(np.sum(u * v, -1), -1, 1)))
|
|
123
|
+
|
|
124
|
+
|
|
125
|
+
def doa_error(truth: Table, model: Table, band=None, method: str = "srp-phat", search: str = "azimuth",
|
|
126
|
+
sources=None) -> dict:
|
|
127
|
+
"""Localization error when the observations come from `truth` and the estimator is steered with `model`.
|
|
128
|
+
|
|
129
|
+
truth, model: tables with the same receivers and frequencies; model.doa is the search grid.
|
|
130
|
+
search='azimuth': estimate the azimuth only (planar arrays, sources near the horizon); the error is the signed
|
|
131
|
+
azimuth difference. search='full': search all model directions; the error is the great-circle angle.
|
|
132
|
+
sources: indices of truth directions to test (default all). Returns a dict of arrays."""
|
|
133
|
+
if truth.p.shape[0] != model.p.shape[0] or not np.allclose(truth.freqs, model.freqs):
|
|
134
|
+
raise ValueError("truth and model need the same receivers and frequencies")
|
|
135
|
+
f_sel = (np.ones(len(truth.freqs), bool) if band is None
|
|
136
|
+
else (truth.freqs >= band[0]) & (truth.freqs <= band[1]))
|
|
137
|
+
S = model.p[:, :, f_sel]
|
|
138
|
+
est_fn = {"srp-phat": _srp_phat, "music": _music}[method]
|
|
139
|
+
src = np.arange(len(truth.doa)) if sources is None else np.asarray(sources)
|
|
140
|
+
est = np.empty((len(src), 3))
|
|
141
|
+
for n, s in enumerate(src):
|
|
142
|
+
est[n] = model.doa[int(np.argmax(est_fn(truth.p[:, s, f_sel], S)))]
|
|
143
|
+
true = truth.doa[src]
|
|
144
|
+
out = {"true": true, "estimate": est, "angle": angle_between(true, est)}
|
|
145
|
+
if search == "azimuth":
|
|
146
|
+
az_t = np.degrees(np.arctan2(true[:, 1], true[:, 0]))
|
|
147
|
+
az_e = np.degrees(np.arctan2(est[:, 1], est[:, 0]))
|
|
148
|
+
out["azimuth_error"] = (az_e - az_t + 180) % 360 - 180
|
|
149
|
+
return out
|
|
150
|
+
|
|
151
|
+
|
|
152
|
+
def summarize(err: dict, key: str = None) -> str:
|
|
153
|
+
e = err[key or ("azimuth_error" if "azimuth_error" in err else "angle")]
|
|
154
|
+
a = np.abs(e)
|
|
155
|
+
return (f"mean |err| {a.mean():.2f} deg, 95th pct {np.percentile(a, 95):.2f}, max {a.max():.2f}, "
|
|
156
|
+
f"mean signed {e.mean():+.2f}")
|