polecraft 0.0.1__tar.gz
This diff represents the content of publicly available package versions that have been released to one of the supported registries. The information contained in this diff is provided for informational purposes only and reflects changes between package versions as they appear in their respective public registries.
- polecraft-0.0.1/CHANGELOG.md +54 -0
- polecraft-0.0.1/LICENSE +201 -0
- polecraft-0.0.1/MANIFEST.in +5 -0
- polecraft-0.0.1/PKG-INFO +146 -0
- polecraft-0.0.1/README.md +114 -0
- polecraft-0.0.1/designs/qdd_outer_12s10p.yaml +51 -0
- polecraft-0.0.1/designs/qdd_outer_24s28p.yaml +51 -0
- polecraft-0.0.1/designs/qdd_outer_36s42p.yaml +53 -0
- polecraft-0.0.1/examples/mesh_a_design.py +44 -0
- polecraft-0.0.1/polecraft/__init__.py +17 -0
- polecraft-0.0.1/polecraft/__main__.py +7 -0
- polecraft-0.0.1/polecraft/cli.py +94 -0
- polecraft-0.0.1/polecraft/core/__init__.py +5 -0
- polecraft-0.0.1/polecraft/core/geometry.py +281 -0
- polecraft-0.0.1/polecraft/core/mesh.py +480 -0
- polecraft-0.0.1/polecraft/core/winding.py +204 -0
- polecraft-0.0.1/polecraft/data/__init__.py +1 -0
- polecraft-0.0.1/polecraft/design.py +292 -0
- polecraft-0.0.1/polecraft/machines/__init__.py +34 -0
- polecraft-0.0.1/polecraft/machines/base.py +85 -0
- polecraft-0.0.1/polecraft/machines/qdd_outer.py +490 -0
- polecraft-0.0.1/polecraft/plot.py +119 -0
- polecraft-0.0.1/polecraft/studies/__init__.py +1 -0
- polecraft-0.0.1/polecraft/timing.py +39 -0
- polecraft-0.0.1/polecraft/validation.py +272 -0
- polecraft-0.0.1/polecraft.egg-info/PKG-INFO +146 -0
- polecraft-0.0.1/polecraft.egg-info/SOURCES.txt +49 -0
- polecraft-0.0.1/polecraft.egg-info/dependency_links.txt +1 -0
- polecraft-0.0.1/polecraft.egg-info/entry_points.txt +2 -0
- polecraft-0.0.1/polecraft.egg-info/requires.txt +10 -0
- polecraft-0.0.1/polecraft.egg-info/top_level.txt +1 -0
- polecraft-0.0.1/pyproject.toml +59 -0
- polecraft-0.0.1/setup.cfg +4 -0
- polecraft-0.0.1/tests/conftest.py +115 -0
- polecraft-0.0.1/tests/core/test_geometry.py +277 -0
- polecraft-0.0.1/tests/core/test_mesh.py +493 -0
- polecraft-0.0.1/tests/core/test_mesh_without_gmsh.py +29 -0
- polecraft-0.0.1/tests/core/test_winding.py +357 -0
- polecraft-0.0.1/tests/data/duplicate_key.yaml +5 -0
- polecraft-0.0.1/tests/data/valid_design.yaml +45 -0
- polecraft-0.0.1/tests/machines/test_machine_contract.py +161 -0
- polecraft-0.0.1/tests/machines/test_qdd_outer.py +148 -0
- polecraft-0.0.1/tests/machines/test_qdd_outer_geometry.py +502 -0
- polecraft-0.0.1/tests/test_cli.py +246 -0
- polecraft-0.0.1/tests/test_design.py +548 -0
- polecraft-0.0.1/tests/test_examples.py +34 -0
- polecraft-0.0.1/tests/test_package.py +32 -0
- polecraft-0.0.1/tests/test_plot.py +250 -0
- polecraft-0.0.1/tests/test_release.py +86 -0
- polecraft-0.0.1/tests/test_timing.py +47 -0
- polecraft-0.0.1/tests/test_validation.py +244 -0
|
@@ -0,0 +1,54 @@
|
|
|
1
|
+
# Changelog
|
|
2
|
+
|
|
3
|
+
All notable changes to Pole-Craft are listed here, newest first. Version
|
|
4
|
+
numbers follow [semantic versioning](https://semver.org); while the version
|
|
5
|
+
is 0.0.x the design-file format and the Python interface may change between
|
|
6
|
+
releases.
|
|
7
|
+
|
|
8
|
+
## [0.0.1] - 2026-11-16
|
|
9
|
+
|
|
10
|
+
First release. It loads a design file, builds the geometry of an outer-rotor
|
|
11
|
+
motor, meshes it and saves a picture. There is no field solver yet, so it
|
|
12
|
+
does not report torque, back-EMF or losses.
|
|
13
|
+
|
|
14
|
+
### Added
|
|
15
|
+
|
|
16
|
+
- Design files in YAML (`format_version: 1`) for outer-rotor surface-magnet
|
|
17
|
+
motors (`type: qdd_outer`), with strict checking: unknown fields, wrong
|
|
18
|
+
types and values out of range are all reported in one message, and
|
|
19
|
+
dimensions that do not fit together are then reported one at a time.
|
|
20
|
+
- Symmetry slice and winding layout for any balanced three-phase slot and
|
|
21
|
+
pole combination with a double-layer tooth-wound winding, and its winding
|
|
22
|
+
factor.
|
|
23
|
+
- Cross-section geometry as labelled regions (stator and rotor steel, coil
|
|
24
|
+
sides, magnets, air), for the repeating slice or the whole machine.
|
|
25
|
+
- Triangle meshing through Gmsh, with a sliding band in the air gap prepared
|
|
26
|
+
for rotation without remeshing.
|
|
27
|
+
- `polecraft mesh <design.yaml>` command: saves a coloured picture of the
|
|
28
|
+
mesh (PNG, SVG or PDF) and prints the mesh size and a timing report.
|
|
29
|
+
- The same steps from Python (`load_design`, `machine_for`, `build_mesh`,
|
|
30
|
+
`plot_mesh`), with an example script in `examples/`.
|
|
31
|
+
- Three example designs: 36 slots with 42 poles, 24 slots with 28 poles and
|
|
32
|
+
12 slots with 10 poles. Their dimensions are placeholders, not measured or
|
|
33
|
+
optimised designs.
|
|
34
|
+
|
|
35
|
+
### Known limits
|
|
36
|
+
|
|
37
|
+
- No field solution: nothing is simulated yet.
|
|
38
|
+
- Outer-rotor surface-magnet motors only, with parallel-sided teeth.
|
|
39
|
+
- Meshing needs the optional Gmsh package (`pip install "polecraft[mesh]"`).
|
|
40
|
+
On Linux, Gmsh also needs a few system libraries; the README lists them.
|
|
41
|
+
- The material names in a design file are stored but not yet checked against
|
|
42
|
+
a material library.
|
|
43
|
+
- Winding, lengthwise and temperature values are read but not used yet: for
|
|
44
|
+
example, nothing checks that the turns fit in the slot.
|
|
45
|
+
- There is no air region outside the rotor yoke or inside the stator bore.
|
|
46
|
+
- The air-gap band is one layer of triangles. Very fine meshes (`--size`
|
|
47
|
+
below about 0.5) and slot and pole counts with little in common give thin
|
|
48
|
+
triangles in the air gap.
|
|
49
|
+
- Pictures of very fine meshes look dark, because the triangle edge lines do
|
|
50
|
+
not thin out.
|
|
51
|
+
- Meshing cannot be interrupted part-way; Ctrl-C takes effect when the mesher
|
|
52
|
+
returns.
|
|
53
|
+
|
|
54
|
+
[0.0.1]: https://github.com/pole-craft/pole-craft/releases/tag/v0.0.1
|
polecraft-0.0.1/LICENSE
ADDED
|
@@ -0,0 +1,201 @@
|
|
|
1
|
+
Apache License
|
|
2
|
+
Version 2.0, January 2004
|
|
3
|
+
http://www.apache.org/licenses/
|
|
4
|
+
|
|
5
|
+
TERMS AND CONDITIONS FOR USE, REPRODUCTION, AND DISTRIBUTION
|
|
6
|
+
|
|
7
|
+
1. Definitions.
|
|
8
|
+
|
|
9
|
+
"License" shall mean the terms and conditions for use, reproduction,
|
|
10
|
+
and distribution as defined by Sections 1 through 9 of this document.
|
|
11
|
+
|
|
12
|
+
"Licensor" shall mean the copyright owner or entity authorized by
|
|
13
|
+
the copyright owner that is granting the License.
|
|
14
|
+
|
|
15
|
+
"Legal Entity" shall mean the union of the acting entity and all
|
|
16
|
+
other entities that control, are controlled by, or are under common
|
|
17
|
+
control with that entity. For the purposes of this definition,
|
|
18
|
+
"control" means (i) the power, direct or indirect, to cause the
|
|
19
|
+
direction or management of such entity, whether by contract or
|
|
20
|
+
otherwise, or (ii) ownership of fifty percent (50%) or more of the
|
|
21
|
+
outstanding shares, or (iii) beneficial ownership of such entity.
|
|
22
|
+
|
|
23
|
+
"You" (or "Your") shall mean an individual or Legal Entity
|
|
24
|
+
exercising permissions granted by this License.
|
|
25
|
+
|
|
26
|
+
"Source" form shall mean the preferred form for making modifications,
|
|
27
|
+
including but not limited to software source code, documentation
|
|
28
|
+
source, and configuration files.
|
|
29
|
+
|
|
30
|
+
"Object" form shall mean any form resulting from mechanical
|
|
31
|
+
transformation or translation of a Source form, including but
|
|
32
|
+
not limited to compiled object code, generated documentation,
|
|
33
|
+
and conversions to other media types.
|
|
34
|
+
|
|
35
|
+
"Work" shall mean the work of authorship, whether in Source or
|
|
36
|
+
Object form, made available under the License, as indicated by a
|
|
37
|
+
copyright notice that is included in or attached to the work
|
|
38
|
+
(an example is provided in the Appendix below).
|
|
39
|
+
|
|
40
|
+
"Derivative Works" shall mean any work, whether in Source or Object
|
|
41
|
+
form, that is based on (or derived from) the Work and for which the
|
|
42
|
+
editorial revisions, annotations, elaborations, or other modifications
|
|
43
|
+
represent, as a whole, an original work of authorship. For the purposes
|
|
44
|
+
of this License, Derivative Works shall not include works that remain
|
|
45
|
+
separable from, or merely link (or bind by name) to the interfaces of,
|
|
46
|
+
the Work and Derivative Works thereof.
|
|
47
|
+
|
|
48
|
+
"Contribution" shall mean any work of authorship, including
|
|
49
|
+
the original version of the Work and any modifications or additions
|
|
50
|
+
to that Work or Derivative Works thereof, that is intentionally
|
|
51
|
+
submitted to Licensor for inclusion in the Work by the copyright owner
|
|
52
|
+
or by an individual or Legal Entity authorized to submit on behalf of
|
|
53
|
+
the copyright owner. For the purposes of this definition, "submitted"
|
|
54
|
+
means any form of electronic, verbal, or written communication sent
|
|
55
|
+
to the Licensor or its representatives, including but not limited to
|
|
56
|
+
communication on electronic mailing lists, source code control systems,
|
|
57
|
+
and issue tracking systems that are managed by, or on behalf of, the
|
|
58
|
+
Licensor for the purpose of discussing and improving the Work, but
|
|
59
|
+
excluding communication that is conspicuously marked or otherwise
|
|
60
|
+
designated in writing by the copyright owner as "Not a Contribution."
|
|
61
|
+
|
|
62
|
+
"Contributor" shall mean Licensor and any individual or Legal Entity
|
|
63
|
+
on behalf of whom a Contribution has been received by Licensor and
|
|
64
|
+
subsequently incorporated within the Work.
|
|
65
|
+
|
|
66
|
+
2. Grant of Copyright License. Subject to the terms and conditions of
|
|
67
|
+
this License, each Contributor hereby grants to You a perpetual,
|
|
68
|
+
worldwide, non-exclusive, no-charge, royalty-free, irrevocable
|
|
69
|
+
copyright license to reproduce, prepare Derivative Works of,
|
|
70
|
+
publicly display, publicly perform, sublicense, and distribute the
|
|
71
|
+
Work and such Derivative Works in Source or Object form.
|
|
72
|
+
|
|
73
|
+
3. Grant of Patent License. Subject to the terms and conditions of
|
|
74
|
+
this License, each Contributor hereby grants to You a perpetual,
|
|
75
|
+
worldwide, non-exclusive, no-charge, royalty-free, irrevocable
|
|
76
|
+
(except as stated in this section) patent license to make, have made,
|
|
77
|
+
use, offer to sell, sell, import, and otherwise transfer the Work,
|
|
78
|
+
where such license applies only to those patent claims licensable
|
|
79
|
+
by such Contributor that are necessarily infringed by their
|
|
80
|
+
Contribution(s) alone or by combination of their Contribution(s)
|
|
81
|
+
with the Work to which such Contribution(s) was submitted. If You
|
|
82
|
+
institute patent litigation against any entity (including a
|
|
83
|
+
cross-claim or counterclaim in a lawsuit) alleging that the Work
|
|
84
|
+
or a Contribution incorporated within the Work constitutes direct
|
|
85
|
+
or contributory patent infringement, then any patent licenses
|
|
86
|
+
granted to You under this License for that Work shall terminate
|
|
87
|
+
as of the date such litigation is filed.
|
|
88
|
+
|
|
89
|
+
4. Redistribution. You may reproduce and distribute copies of the
|
|
90
|
+
Work or Derivative Works thereof in any medium, with or without
|
|
91
|
+
modifications, and in Source or Object form, provided that You
|
|
92
|
+
meet the following conditions:
|
|
93
|
+
|
|
94
|
+
(a) You must give any other recipients of the Work or
|
|
95
|
+
Derivative Works a copy of this License; and
|
|
96
|
+
|
|
97
|
+
(b) You must cause any modified files to carry prominent notices
|
|
98
|
+
stating that You changed the files; and
|
|
99
|
+
|
|
100
|
+
(c) You must retain, in the Source form of any Derivative Works
|
|
101
|
+
that You distribute, all copyright, patent, trademark, and
|
|
102
|
+
attribution notices from the Source form of the Work,
|
|
103
|
+
excluding those notices that do not pertain to any part of
|
|
104
|
+
the Derivative Works; and
|
|
105
|
+
|
|
106
|
+
(d) If the Work includes a "NOTICE" text file as part of its
|
|
107
|
+
distribution, then any Derivative Works that You distribute must
|
|
108
|
+
include a readable copy of the attribution notices contained
|
|
109
|
+
within such NOTICE file, excluding those notices that do not
|
|
110
|
+
pertain to any part of the Derivative Works, in at least one
|
|
111
|
+
of the following places: within a NOTICE text file distributed
|
|
112
|
+
as part of the Derivative Works; within the Source form or
|
|
113
|
+
documentation, if provided along with the Derivative Works; or,
|
|
114
|
+
within a display generated by the Derivative Works, if and
|
|
115
|
+
wherever such third-party notices normally appear. The contents
|
|
116
|
+
of the NOTICE file are for informational purposes only and
|
|
117
|
+
do not modify the License. You may add Your own attribution
|
|
118
|
+
notices within Derivative Works that You distribute, alongside
|
|
119
|
+
or as an addendum to the NOTICE text from the Work, provided
|
|
120
|
+
that such additional attribution notices cannot be construed
|
|
121
|
+
as modifying the License.
|
|
122
|
+
|
|
123
|
+
You may add Your own copyright statement to Your modifications and
|
|
124
|
+
may provide additional or different license terms and conditions
|
|
125
|
+
for use, reproduction, or distribution of Your modifications, or
|
|
126
|
+
for any such Derivative Works as a whole, provided Your use,
|
|
127
|
+
reproduction, and distribution of the Work otherwise complies with
|
|
128
|
+
the conditions stated in this License.
|
|
129
|
+
|
|
130
|
+
5. Submission of Contributions. Unless You explicitly state otherwise,
|
|
131
|
+
any Contribution intentionally submitted for inclusion in the Work
|
|
132
|
+
by You to the Licensor shall be under the terms and conditions of
|
|
133
|
+
this License, without any additional terms or conditions.
|
|
134
|
+
Notwithstanding the above, nothing herein shall supersede or modify
|
|
135
|
+
the terms of any separate license agreement you may have executed
|
|
136
|
+
with Licensor regarding such Contributions.
|
|
137
|
+
|
|
138
|
+
6. Trademarks. This License does not grant permission to use the trade
|
|
139
|
+
names, trademarks, service marks, or product names of the Licensor,
|
|
140
|
+
except as required for reasonable and customary use in describing the
|
|
141
|
+
origin of the Work and reproducing the content of the NOTICE file.
|
|
142
|
+
|
|
143
|
+
7. Disclaimer of Warranty. Unless required by applicable law or
|
|
144
|
+
agreed to in writing, Licensor provides the Work (and each
|
|
145
|
+
Contributor provides its Contributions) on an "AS IS" BASIS,
|
|
146
|
+
WITHOUT WARRANTIES OR CONDITIONS OF ANY KIND, either express or
|
|
147
|
+
implied, including, without limitation, any warranties or conditions
|
|
148
|
+
of TITLE, NON-INFRINGEMENT, MERCHANTABILITY, or FITNESS FOR A
|
|
149
|
+
PARTICULAR PURPOSE. You are solely responsible for determining the
|
|
150
|
+
appropriateness of using or redistributing the Work and assume any
|
|
151
|
+
risks associated with Your exercise of permissions under this License.
|
|
152
|
+
|
|
153
|
+
8. Limitation of Liability. In no event and under no legal theory,
|
|
154
|
+
whether in tort (including negligence), contract, or otherwise,
|
|
155
|
+
unless required by applicable law (such as deliberate and grossly
|
|
156
|
+
negligent acts) or agreed to in writing, shall any Contributor be
|
|
157
|
+
liable to You for damages, including any direct, indirect, special,
|
|
158
|
+
incidental, or consequential damages of any character arising as a
|
|
159
|
+
result of this License or out of the use or inability to use the
|
|
160
|
+
Work (including but not limited to damages for loss of goodwill,
|
|
161
|
+
work stoppage, computer failure or malfunction, or any and all
|
|
162
|
+
other commercial damages or losses), even if such Contributor
|
|
163
|
+
has been advised of the possibility of such damages.
|
|
164
|
+
|
|
165
|
+
9. Accepting Warranty or Additional Liability. While redistributing
|
|
166
|
+
the Work or Derivative Works thereof, You may choose to offer,
|
|
167
|
+
and charge a fee for, acceptance of support, warranty, indemnity,
|
|
168
|
+
or other liability obligations and/or rights consistent with this
|
|
169
|
+
License. However, in accepting such obligations, You may act only
|
|
170
|
+
on Your own behalf and on Your sole responsibility, not on behalf
|
|
171
|
+
of any other Contributor, and only if You agree to indemnify,
|
|
172
|
+
defend, and hold each Contributor harmless for any liability
|
|
173
|
+
incurred by, or claims asserted against, such Contributor by reason
|
|
174
|
+
of your accepting any such warranty or additional liability.
|
|
175
|
+
|
|
176
|
+
END OF TERMS AND CONDITIONS
|
|
177
|
+
|
|
178
|
+
APPENDIX: How to apply the Apache License to your work.
|
|
179
|
+
|
|
180
|
+
To apply the Apache License to your work, attach the following
|
|
181
|
+
boilerplate notice, with the fields enclosed by brackets "[]"
|
|
182
|
+
replaced with your own identifying information. (Don't include
|
|
183
|
+
the brackets!) The text should be enclosed in the appropriate
|
|
184
|
+
comment syntax for the file format. We also recommend that a
|
|
185
|
+
file or class name and description of purpose be included on the
|
|
186
|
+
same "printed page" as the copyright notice for easier
|
|
187
|
+
identification within third-party archives.
|
|
188
|
+
|
|
189
|
+
Copyright [yyyy] [name of copyright owner]
|
|
190
|
+
|
|
191
|
+
Licensed under the Apache License, Version 2.0 (the "License");
|
|
192
|
+
you may not use this file except in compliance with the License.
|
|
193
|
+
You may obtain a copy of the License at
|
|
194
|
+
|
|
195
|
+
http://www.apache.org/licenses/LICENSE-2.0
|
|
196
|
+
|
|
197
|
+
Unless required by applicable law or agreed to in writing, software
|
|
198
|
+
distributed under the License is distributed on an "AS IS" BASIS,
|
|
199
|
+
WITHOUT WARRANTIES OR CONDITIONS OF ANY KIND, either express or implied.
|
|
200
|
+
See the License for the specific language governing permissions and
|
|
201
|
+
limitations under the License.
|
polecraft-0.0.1/PKG-INFO
ADDED
|
@@ -0,0 +1,146 @@
|
|
|
1
|
+
Metadata-Version: 2.4
|
|
2
|
+
Name: polecraft
|
|
3
|
+
Version: 0.0.1
|
|
4
|
+
Summary: Open-source design and simulation tool for quasi-direct-drive (QDD) motors.
|
|
5
|
+
Author: Varun Pandithurai
|
|
6
|
+
License-Expression: Apache-2.0
|
|
7
|
+
Project-URL: Repository, https://github.com/pole-craft/pole-craft
|
|
8
|
+
Project-URL: Issues, https://github.com/pole-craft/pole-craft/issues
|
|
9
|
+
Project-URL: Changelog, https://github.com/pole-craft/pole-craft/blob/main/CHANGELOG.md
|
|
10
|
+
Keywords: motor,electric machine,finite element,QDD,BLDC,PMSM
|
|
11
|
+
Classifier: Development Status :: 2 - Pre-Alpha
|
|
12
|
+
Classifier: Intended Audience :: Science/Research
|
|
13
|
+
Classifier: Operating System :: OS Independent
|
|
14
|
+
Classifier: Programming Language :: Python :: 3
|
|
15
|
+
Classifier: Programming Language :: Python :: 3.11
|
|
16
|
+
Classifier: Programming Language :: Python :: 3.12
|
|
17
|
+
Classifier: Programming Language :: Python :: 3.13
|
|
18
|
+
Classifier: Programming Language :: Python :: 3.14
|
|
19
|
+
Classifier: Topic :: Scientific/Engineering :: Physics
|
|
20
|
+
Requires-Python: >=3.11
|
|
21
|
+
Description-Content-Type: text/markdown
|
|
22
|
+
License-File: LICENSE
|
|
23
|
+
Requires-Dist: numpy>=1.26
|
|
24
|
+
Requires-Dist: scipy>=1.11
|
|
25
|
+
Requires-Dist: matplotlib>=3.8
|
|
26
|
+
Requires-Dist: PyYAML>=6.0
|
|
27
|
+
Provides-Extra: mesh
|
|
28
|
+
Requires-Dist: gmsh>=4.11; extra == "mesh"
|
|
29
|
+
Provides-Extra: dev
|
|
30
|
+
Requires-Dist: pytest>=8.0; extra == "dev"
|
|
31
|
+
Dynamic: license-file
|
|
32
|
+
|
|
33
|
+
# Pole-Craft
|
|
34
|
+
|
|
35
|
+
Open-source design and simulation tool for quasi-direct-drive (QDD) motors.
|
|
36
|
+
|
|
37
|
+
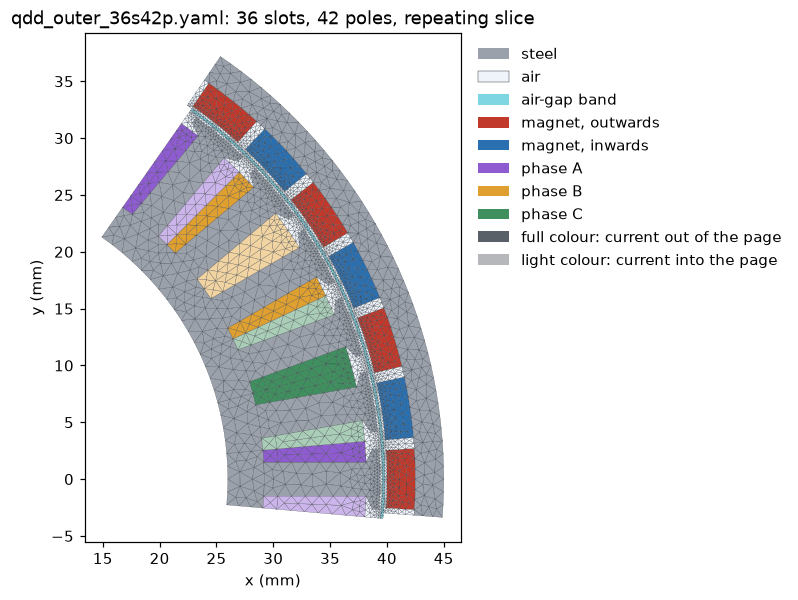
> **Status: early development (version 0.0.1).** Pole-Craft loads a motor design file and checks it, works out the winding layout and the slice of the motor that repeats, builds the cross-section of an outer-rotor motor as labelled regions (steel, coils, magnets, air), meshes it with triangles and saves a picture with the `polecraft mesh` command. **It does not simulate anything yet:** there is no field solver, so it reports no torque, back-EMF or losses. The roadmap below shows what comes next.
|
|
38
|
+
|
|
39
|
+
|
|
40
|
+
|
|
41
|
+
## What it will do
|
|
42
|
+
|
|
43
|
+
Pole-Craft takes a motor described in a simple design file and tells you how it performs:
|
|
44
|
+
|
|
45
|
+
- Builds the motor geometry from parameters (slots, poles, diameters, magnet shape)
|
|
46
|
+
- Runs 2D electromagnetic finite-element analysis
|
|
47
|
+
- Reports torque, cogging, back-EMF, torque constant, losses and efficiency
|
|
48
|
+
- Lets you change magnet grade, steel grade, wire size and turns, and compare the results
|
|
49
|
+
- Sweeps many design variants to find the best one for a target
|
|
50
|
+
|
|
51
|
+
The first focus is surface-magnet outer-rotor and inner-rotor motors of the kind used in QDD robot actuators.
|
|
52
|
+
|
|
53
|
+
## Why
|
|
54
|
+
|
|
55
|
+
Commercial motor design tools are expensive, and their free student versions cannot be used for commercial work. Existing open-source tools are general-purpose. Pole-Craft aims to make exploring QDD motor designs fast, scriptable and free for anyone to use.
|
|
56
|
+
|
|
57
|
+
## Install
|
|
58
|
+
|
|
59
|
+
Needs Python 3.11 or newer.
|
|
60
|
+
|
|
61
|
+
```
|
|
62
|
+
pip install "polecraft[mesh]"
|
|
63
|
+
```
|
|
64
|
+
|
|
65
|
+
The `mesh` extra installs [Gmsh](https://gmsh.info), which does the meshing. Gmsh is licensed under the GPL, so it is kept optional: Pole-Craft does not include any Gmsh code and only calls it if you install it. Plain `pip install polecraft` gives everything except meshing.
|
|
66
|
+
|
|
67
|
+
On Linux, Gmsh needs a few system libraries that servers, containers and WSL often lack. If `polecraft mesh` reports `libGLU.so.1: cannot open shared object file` (or a similar library name), install them. On Debian or Ubuntu:
|
|
68
|
+
|
|
69
|
+
```
|
|
70
|
+
sudo apt-get install libglu1-mesa libxcursor1 libxft2 libxinerama1 libxrender1 libgomp1
|
|
71
|
+
```
|
|
72
|
+
|
|
73
|
+
## Try it
|
|
74
|
+
|
|
75
|
+
Save an example design, for instance [qdd_outer_36s42p.yaml](https://raw.githubusercontent.com/pole-craft/pole-craft/main/designs/qdd_outer_36s42p.yaml), into the folder you are working in. The others are in the [designs folder](https://github.com/pole-craft/pole-craft/tree/main/designs), and a clone of the repository contains them all. Then mesh it and save a picture:
|
|
76
|
+
|
|
77
|
+
```
|
|
78
|
+
polecraft mesh qdd_outer_36s42p.yaml
|
|
79
|
+
```
|
|
80
|
+
|
|
81
|
+
This writes `qdd_outer_36s42p_mesh.png` in the current folder and prints the mesh size and how long each stage took. Only the slice of the motor that repeats is meshed; add `--full` for the whole machine, `-o` to choose the output file (`.png`, `.svg` or `.pdf`), and `--size 0.5` for a finer mesh.
|
|
82
|
+
|
|
83
|
+
The design files are plain YAML, with lengths in millimetres. The dimensions in the examples are placeholders typical of each motor size, not measured or optimised designs. The design-file format may change between 0.0.x versions.
|
|
84
|
+
|
|
85
|
+
## Use from Python
|
|
86
|
+
|
|
87
|
+
The same steps can be run from a script:
|
|
88
|
+
|
|
89
|
+
```python
|
|
90
|
+
from polecraft import load_design, machine_for
|
|
91
|
+
from polecraft.core.mesh import build_mesh
|
|
92
|
+
from polecraft.plot import plot_mesh
|
|
93
|
+
|
|
94
|
+
design = load_design("qdd_outer_36s42p.yaml")
|
|
95
|
+
machine = machine_for(design)
|
|
96
|
+
print(machine.symmetry()) # the slice that repeats
|
|
97
|
+
|
|
98
|
+
geometry = machine.build_geometry() # full=True for the whole machine
|
|
99
|
+
mesh = build_mesh(geometry, size=1.0) # needs Gmsh; smaller size, finer mesh
|
|
100
|
+
print(len(mesh.nodes), len(mesh.triangles))
|
|
101
|
+
|
|
102
|
+
plot_mesh(mesh, geometry, "motor.png")
|
|
103
|
+
```
|
|
104
|
+
|
|
105
|
+
A longer example that also prints the winding layout is in [examples/mesh_a_design.py](https://github.com/pole-craft/pole-craft/blob/main/examples/mesh_a_design.py). The Python interface may change between 0.0.x versions.
|
|
106
|
+
|
|
107
|
+
## Roadmap
|
|
108
|
+
|
|
109
|
+
- [x] Parametric geometry and meshing for QDD motors (outer rotor; inner rotor to follow)
|
|
110
|
+
- [ ] 2D field solver with saturated steel and permanent magnets
|
|
111
|
+
- [ ] Rotation: cogging torque, back-EMF, torque ripple
|
|
112
|
+
- [ ] Material and winding library
|
|
113
|
+
- [ ] Losses, torque-speed curve and efficiency map
|
|
114
|
+
- [ ] Parallel and GPU-accelerated design sweeps
|
|
115
|
+
- [ ] Validation against FEMM and measured motors
|
|
116
|
+
- [ ] Gear module for actuator-level results
|
|
117
|
+
- [ ] 3D verification
|
|
118
|
+
|
|
119
|
+
Changes in each release are listed in the [changelog](https://github.com/pole-craft/pole-craft/blob/main/CHANGELOG.md).
|
|
120
|
+
|
|
121
|
+
## Built with
|
|
122
|
+
|
|
123
|
+
Python, [Gmsh](https://gmsh.info) for meshing, and [FEMM](https://www.femm.info) as an independent reference for validation.
|
|
124
|
+
|
|
125
|
+
## Development setup and running the tests
|
|
126
|
+
|
|
127
|
+
Clone the repository, then install it in a virtual environment together with the test tools:
|
|
128
|
+
|
|
129
|
+
```
|
|
130
|
+
git clone https://github.com/pole-craft/pole-craft.git
|
|
131
|
+
cd pole-craft
|
|
132
|
+
python -m venv .venv
|
|
133
|
+
.venv\Scripts\activate # Linux/macOS: source .venv/bin/activate
|
|
134
|
+
pip install -e ".[dev,mesh]"
|
|
135
|
+
pytest
|
|
136
|
+
```
|
|
137
|
+
|
|
138
|
+
Without the `mesh` extra everything except meshing works, and the meshing tests are skipped.
|
|
139
|
+
|
|
140
|
+
## Contributing
|
|
141
|
+
|
|
142
|
+
The project is just starting. Ideas, questions, bug reports and motor data for validation are welcome: please [open an issue](https://github.com/pole-craft/pole-craft/issues).
|
|
143
|
+
|
|
144
|
+
## License
|
|
145
|
+
|
|
146
|
+
Apache License 2.0. See [LICENSE](https://github.com/pole-craft/pole-craft/blob/main/LICENSE).
|
|
@@ -0,0 +1,114 @@
|
|
|
1
|
+
# Pole-Craft
|
|
2
|
+
|
|
3
|
+
Open-source design and simulation tool for quasi-direct-drive (QDD) motors.
|
|
4
|
+
|
|
5
|
+
> **Status: early development (version 0.0.1).** Pole-Craft loads a motor design file and checks it, works out the winding layout and the slice of the motor that repeats, builds the cross-section of an outer-rotor motor as labelled regions (steel, coils, magnets, air), meshes it with triangles and saves a picture with the `polecraft mesh` command. **It does not simulate anything yet:** there is no field solver, so it reports no torque, back-EMF or losses. The roadmap below shows what comes next.
|
|
6
|
+
|
|
7
|
+

|
|
8
|
+
|
|
9
|
+
## What it will do
|
|
10
|
+
|
|
11
|
+
Pole-Craft takes a motor described in a simple design file and tells you how it performs:
|
|
12
|
+
|
|
13
|
+
- Builds the motor geometry from parameters (slots, poles, diameters, magnet shape)
|
|
14
|
+
- Runs 2D electromagnetic finite-element analysis
|
|
15
|
+
- Reports torque, cogging, back-EMF, torque constant, losses and efficiency
|
|
16
|
+
- Lets you change magnet grade, steel grade, wire size and turns, and compare the results
|
|
17
|
+
- Sweeps many design variants to find the best one for a target
|
|
18
|
+
|
|
19
|
+
The first focus is surface-magnet outer-rotor and inner-rotor motors of the kind used in QDD robot actuators.
|
|
20
|
+
|
|
21
|
+
## Why
|
|
22
|
+
|
|
23
|
+
Commercial motor design tools are expensive, and their free student versions cannot be used for commercial work. Existing open-source tools are general-purpose. Pole-Craft aims to make exploring QDD motor designs fast, scriptable and free for anyone to use.
|
|
24
|
+
|
|
25
|
+
## Install
|
|
26
|
+
|
|
27
|
+
Needs Python 3.11 or newer.
|
|
28
|
+
|
|
29
|
+
```
|
|
30
|
+
pip install "polecraft[mesh]"
|
|
31
|
+
```
|
|
32
|
+
|
|
33
|
+
The `mesh` extra installs [Gmsh](https://gmsh.info), which does the meshing. Gmsh is licensed under the GPL, so it is kept optional: Pole-Craft does not include any Gmsh code and only calls it if you install it. Plain `pip install polecraft` gives everything except meshing.
|
|
34
|
+
|
|
35
|
+
On Linux, Gmsh needs a few system libraries that servers, containers and WSL often lack. If `polecraft mesh` reports `libGLU.so.1: cannot open shared object file` (or a similar library name), install them. On Debian or Ubuntu:
|
|
36
|
+
|
|
37
|
+
```
|
|
38
|
+
sudo apt-get install libglu1-mesa libxcursor1 libxft2 libxinerama1 libxrender1 libgomp1
|
|
39
|
+
```
|
|
40
|
+
|
|
41
|
+
## Try it
|
|
42
|
+
|
|
43
|
+
Save an example design, for instance [qdd_outer_36s42p.yaml](https://raw.githubusercontent.com/pole-craft/pole-craft/main/designs/qdd_outer_36s42p.yaml), into the folder you are working in. The others are in the [designs folder](https://github.com/pole-craft/pole-craft/tree/main/designs), and a clone of the repository contains them all. Then mesh it and save a picture:
|
|
44
|
+
|
|
45
|
+
```
|
|
46
|
+
polecraft mesh qdd_outer_36s42p.yaml
|
|
47
|
+
```
|
|
48
|
+
|
|
49
|
+
This writes `qdd_outer_36s42p_mesh.png` in the current folder and prints the mesh size and how long each stage took. Only the slice of the motor that repeats is meshed; add `--full` for the whole machine, `-o` to choose the output file (`.png`, `.svg` or `.pdf`), and `--size 0.5` for a finer mesh.
|
|
50
|
+
|
|
51
|
+
The design files are plain YAML, with lengths in millimetres. The dimensions in the examples are placeholders typical of each motor size, not measured or optimised designs. The design-file format may change between 0.0.x versions.
|
|
52
|
+
|
|
53
|
+
## Use from Python
|
|
54
|
+
|
|
55
|
+
The same steps can be run from a script:
|
|
56
|
+
|
|
57
|
+
```python
|
|
58
|
+
from polecraft import load_design, machine_for
|
|
59
|
+
from polecraft.core.mesh import build_mesh
|
|
60
|
+
from polecraft.plot import plot_mesh
|
|
61
|
+
|
|
62
|
+
design = load_design("qdd_outer_36s42p.yaml")
|
|
63
|
+
machine = machine_for(design)
|
|
64
|
+
print(machine.symmetry()) # the slice that repeats
|
|
65
|
+
|
|
66
|
+
geometry = machine.build_geometry() # full=True for the whole machine
|
|
67
|
+
mesh = build_mesh(geometry, size=1.0) # needs Gmsh; smaller size, finer mesh
|
|
68
|
+
print(len(mesh.nodes), len(mesh.triangles))
|
|
69
|
+
|
|
70
|
+
plot_mesh(mesh, geometry, "motor.png")
|
|
71
|
+
```
|
|
72
|
+
|
|
73
|
+
A longer example that also prints the winding layout is in [examples/mesh_a_design.py](https://github.com/pole-craft/pole-craft/blob/main/examples/mesh_a_design.py). The Python interface may change between 0.0.x versions.
|
|
74
|
+
|
|
75
|
+
## Roadmap
|
|
76
|
+
|
|
77
|
+
- [x] Parametric geometry and meshing for QDD motors (outer rotor; inner rotor to follow)
|
|
78
|
+
- [ ] 2D field solver with saturated steel and permanent magnets
|
|
79
|
+
- [ ] Rotation: cogging torque, back-EMF, torque ripple
|
|
80
|
+
- [ ] Material and winding library
|
|
81
|
+
- [ ] Losses, torque-speed curve and efficiency map
|
|
82
|
+
- [ ] Parallel and GPU-accelerated design sweeps
|
|
83
|
+
- [ ] Validation against FEMM and measured motors
|
|
84
|
+
- [ ] Gear module for actuator-level results
|
|
85
|
+
- [ ] 3D verification
|
|
86
|
+
|
|
87
|
+
Changes in each release are listed in the [changelog](https://github.com/pole-craft/pole-craft/blob/main/CHANGELOG.md).
|
|
88
|
+
|
|
89
|
+
## Built with
|
|
90
|
+
|
|
91
|
+
Python, [Gmsh](https://gmsh.info) for meshing, and [FEMM](https://www.femm.info) as an independent reference for validation.
|
|
92
|
+
|
|
93
|
+
## Development setup and running the tests
|
|
94
|
+
|
|
95
|
+
Clone the repository, then install it in a virtual environment together with the test tools:
|
|
96
|
+
|
|
97
|
+
```
|
|
98
|
+
git clone https://github.com/pole-craft/pole-craft.git
|
|
99
|
+
cd pole-craft
|
|
100
|
+
python -m venv .venv
|
|
101
|
+
.venv\Scripts\activate # Linux/macOS: source .venv/bin/activate
|
|
102
|
+
pip install -e ".[dev,mesh]"
|
|
103
|
+
pytest
|
|
104
|
+
```
|
|
105
|
+
|
|
106
|
+
Without the `mesh` extra everything except meshing works, and the meshing tests are skipped.
|
|
107
|
+
|
|
108
|
+
## Contributing
|
|
109
|
+
|
|
110
|
+
The project is just starting. Ideas, questions, bug reports and motor data for validation are welcome: please [open an issue](https://github.com/pole-craft/pole-craft/issues).
|
|
111
|
+
|
|
112
|
+
## License
|
|
113
|
+
|
|
114
|
+
Apache License 2.0. See [LICENSE](https://github.com/pole-craft/pole-craft/blob/main/LICENSE).
|
|
@@ -0,0 +1,51 @@
|
|
|
1
|
+
# 12-slot, 10-pole outer-rotor surface-magnet motor, 50 mm outer diameter.
|
|
2
|
+
#
|
|
3
|
+
# The dimensions are placeholders typical of a small motor of this class, not
|
|
4
|
+
# a measured or optimised design. Lengths are in millimetres.
|
|
5
|
+
|
|
6
|
+
format_version: 1
|
|
7
|
+
type: qdd_outer
|
|
8
|
+
slots: 12
|
|
9
|
+
poles: 10
|
|
10
|
+
|
|
11
|
+
# Cross-section, from the outside in. The bore comes out at 19.2 mm diameter.
|
|
12
|
+
geometry:
|
|
13
|
+
air_gap_mm: 0.5
|
|
14
|
+
rotor:
|
|
15
|
+
outer_diameter_mm: 50
|
|
16
|
+
yoke_thickness_mm: 3.5 # back iron behind the magnets
|
|
17
|
+
magnet:
|
|
18
|
+
thickness_mm: 2.0
|
|
19
|
+
arc_fraction: 0.85 # magnet angle / pole angle
|
|
20
|
+
magnetisation: parallel # parallel | radial
|
|
21
|
+
stator:
|
|
22
|
+
tooth_width_mm: 5.0 # parallel-sided teeth
|
|
23
|
+
slot_opening_mm: 2.0
|
|
24
|
+
tooth_tip_height_mm: 0.6
|
|
25
|
+
tooth_tip_taper_mm: 0.8
|
|
26
|
+
slot_depth_mm: 5.0
|
|
27
|
+
yoke_thickness_mm: 3.0
|
|
28
|
+
|
|
29
|
+
# Lengthwise data. The 2D solve uses it only in correction formulas.
|
|
30
|
+
axial:
|
|
31
|
+
stack_length_mm: 10
|
|
32
|
+
magnet_overhang_mm: 0 # per end
|
|
33
|
+
skew_deg: 0
|
|
34
|
+
end_winding_overhang_mm: null # per end; null = estimate from the slot geometry
|
|
35
|
+
|
|
36
|
+
magnet:
|
|
37
|
+
material: N42SH
|
|
38
|
+
temperature_C: 80
|
|
39
|
+
|
|
40
|
+
winding:
|
|
41
|
+
wire_diameter_mm: 0.4 # bare copper
|
|
42
|
+
turns_per_coil: 20
|
|
43
|
+
parallel_strands: 1
|
|
44
|
+
conductor: copper
|
|
45
|
+
connection: star # star | delta
|
|
46
|
+
temperature_C: 100
|
|
47
|
+
|
|
48
|
+
steel:
|
|
49
|
+
stator: M270-35A
|
|
50
|
+
rotor: M270-35A
|
|
51
|
+
stacking_factor: 0.95
|
|
@@ -0,0 +1,51 @@
|
|
|
1
|
+
# 24-slot, 28-pole outer-rotor surface-magnet motor, 70 mm outer diameter.
|
|
2
|
+
#
|
|
3
|
+
# The dimensions are placeholders typical of a motor of this class, not a
|
|
4
|
+
# measured or optimised design. Lengths are in millimetres.
|
|
5
|
+
|
|
6
|
+
format_version: 1
|
|
7
|
+
type: qdd_outer
|
|
8
|
+
slots: 24
|
|
9
|
+
poles: 28
|
|
10
|
+
|
|
11
|
+
# Cross-section, from the outside in. The bore comes out at 34.4 mm diameter.
|
|
12
|
+
geometry:
|
|
13
|
+
air_gap_mm: 0.6
|
|
14
|
+
rotor:
|
|
15
|
+
outer_diameter_mm: 70
|
|
16
|
+
yoke_thickness_mm: 2.5 # back iron behind the magnets
|
|
17
|
+
magnet:
|
|
18
|
+
thickness_mm: 2.5
|
|
19
|
+
arc_fraction: 0.85 # magnet angle / pole angle
|
|
20
|
+
magnetisation: parallel # parallel | radial
|
|
21
|
+
stator:
|
|
22
|
+
tooth_width_mm: 3.4 # parallel-sided teeth
|
|
23
|
+
slot_opening_mm: 1.5
|
|
24
|
+
tooth_tip_height_mm: 0.6
|
|
25
|
+
tooth_tip_taper_mm: 0.6
|
|
26
|
+
slot_depth_mm: 8.0
|
|
27
|
+
yoke_thickness_mm: 3.0
|
|
28
|
+
|
|
29
|
+
# Lengthwise data. The 2D solve uses it only in correction formulas.
|
|
30
|
+
axial:
|
|
31
|
+
stack_length_mm: 12
|
|
32
|
+
magnet_overhang_mm: 0 # per end
|
|
33
|
+
skew_deg: 0
|
|
34
|
+
end_winding_overhang_mm: null # per end; null = estimate from the slot geometry
|
|
35
|
+
|
|
36
|
+
magnet:
|
|
37
|
+
material: N42SH
|
|
38
|
+
temperature_C: 80
|
|
39
|
+
|
|
40
|
+
winding:
|
|
41
|
+
wire_diameter_mm: 0.5 # bare copper
|
|
42
|
+
turns_per_coil: 20
|
|
43
|
+
parallel_strands: 1
|
|
44
|
+
conductor: copper
|
|
45
|
+
connection: star # star | delta
|
|
46
|
+
temperature_C: 100
|
|
47
|
+
|
|
48
|
+
steel:
|
|
49
|
+
stator: M270-35A
|
|
50
|
+
rotor: M270-35A
|
|
51
|
+
stacking_factor: 0.95
|
|
@@ -0,0 +1,53 @@
|
|
|
1
|
+
# Reference design: 36-slot, 42-pole outer-rotor surface-magnet motor,
|
|
2
|
+
# about 90 mm outer diameter.
|
|
3
|
+
#
|
|
4
|
+
# The dimensions are placeholders typical of a motor of this class, not a
|
|
5
|
+
# measured or optimised design. Lengths are in millimetres.
|
|
6
|
+
|
|
7
|
+
format_version: 1
|
|
8
|
+
type: qdd_outer
|
|
9
|
+
slots: 36
|
|
10
|
+
poles: 42
|
|
11
|
+
|
|
12
|
+
# Cross-section, from the outside in. Every radius follows from the outer
|
|
13
|
+
# diameter and the thicknesses below; the bore comes out at 52 mm diameter.
|
|
14
|
+
geometry:
|
|
15
|
+
air_gap_mm: 0.6
|
|
16
|
+
rotor:
|
|
17
|
+
outer_diameter_mm: 90
|
|
18
|
+
yoke_thickness_mm: 2.5 # back iron behind the magnets
|
|
19
|
+
magnet:
|
|
20
|
+
thickness_mm: 2.5
|
|
21
|
+
arc_fraction: 0.85 # magnet angle / pole angle
|
|
22
|
+
magnetisation: parallel # parallel | radial
|
|
23
|
+
stator:
|
|
24
|
+
tooth_width_mm: 3.0 # parallel-sided teeth
|
|
25
|
+
slot_opening_mm: 1.5
|
|
26
|
+
tooth_tip_height_mm: 0.6
|
|
27
|
+
tooth_tip_taper_mm: 0.6
|
|
28
|
+
slot_depth_mm: 9.0
|
|
29
|
+
yoke_thickness_mm: 3.2
|
|
30
|
+
|
|
31
|
+
# Lengthwise data. The 2D solve uses it only in correction formulas.
|
|
32
|
+
axial:
|
|
33
|
+
stack_length_mm: 12
|
|
34
|
+
magnet_overhang_mm: 0 # per end
|
|
35
|
+
skew_deg: 0
|
|
36
|
+
end_winding_overhang_mm: null # per end; null = estimate from the slot geometry
|
|
37
|
+
|
|
38
|
+
magnet:
|
|
39
|
+
material: N42SH
|
|
40
|
+
temperature_C: 80
|
|
41
|
+
|
|
42
|
+
winding:
|
|
43
|
+
wire_diameter_mm: 0.5 # bare copper
|
|
44
|
+
turns_per_coil: 20
|
|
45
|
+
parallel_strands: 1
|
|
46
|
+
conductor: copper
|
|
47
|
+
connection: star # star | delta
|
|
48
|
+
temperature_C: 100
|
|
49
|
+
|
|
50
|
+
steel:
|
|
51
|
+
stator: M270-35A
|
|
52
|
+
rotor: M270-35A
|
|
53
|
+
stacking_factor: 0.95
|