grid-rbd 0.5.0__tar.gz
This diff represents the content of publicly available package versions that have been released to one of the supported registries. The information contained in this diff is provided for informational purposes only and reflects changes between package versions as they appear in their respective public registries.
- grid_rbd-0.5.0/LICENSE +21 -0
- grid_rbd-0.5.0/MANIFEST.in +25 -0
- grid_rbd-0.5.0/PKG-INFO +372 -0
- grid_rbd-0.5.0/README.md +322 -0
- grid_rbd-0.5.0/_build_resources.py +95 -0
- grid_rbd-0.5.0/bindings/grid_rbd/__init__.py +1002 -0
- grid_rbd-0.5.0/bindings/grid_rbd/_cache.py +626 -0
- grid_rbd-0.5.0/bindings/grid_rbd/_compile.py +745 -0
- grid_rbd-0.5.0/bindings/grid_rbd/_configuration.py +35 -0
- grid_rbd-0.5.0/bindings/grid_rbd/_handle.py +2450 -0
- grid_rbd-0.5.0/bindings/grid_rbd/_mujoco.py +143 -0
- grid_rbd-0.5.0/bindings/grid_rbd/_out_transform.py +182 -0
- grid_rbd-0.5.0/bindings/grid_rbd/_payload.py +90 -0
- grid_rbd-0.5.0/bindings/grid_rbd/_surface_common.py +410 -0
- grid_rbd-0.5.0/bindings/grid_rbd/_vjp_common.py +149 -0
- grid_rbd-0.5.0/bindings/grid_rbd/jax/__init__.py +1738 -0
- grid_rbd-0.5.0/bindings/grid_rbd/jax/py.typed +0 -0
- grid_rbd-0.5.0/bindings/grid_rbd/py.typed +0 -0
- grid_rbd-0.5.0/bindings/grid_rbd/torch/__init__.py +1360 -0
- grid_rbd-0.5.0/bindings/grid_rbd/torch/py.typed +0 -0
- grid_rbd-0.5.0/bindings/grid_rbd/wrapper_template.cu +7850 -0
- grid_rbd-0.5.0/bindings/src/_core.cpp +2638 -0
- grid_rbd-0.5.0/external/RBDReference/RBDReference.py +4962 -0
- grid_rbd-0.5.0/external/RBDReference/__init__.py +1 -0
- grid_rbd-0.5.0/external/RBDReference/_centroidal.py +565 -0
- grid_rbd-0.5.0/external/RBDReference/_energy.py +199 -0
- grid_rbd-0.5.0/external/RBDReference/_plant.py +511 -0
- grid_rbd-0.5.0/external/RBDReference/_regressor.py +285 -0
- grid_rbd-0.5.0/external/URDFParser/InertiaSet.py +23 -0
- grid_rbd-0.5.0/external/URDFParser/Joint.py +795 -0
- grid_rbd-0.5.0/external/URDFParser/Link.py +145 -0
- grid_rbd-0.5.0/external/URDFParser/Robot.py +1098 -0
- grid_rbd-0.5.0/external/URDFParser/SpatialAlgebra.py +159 -0
- grid_rbd-0.5.0/external/URDFParser/URDFParser.py +679 -0
- grid_rbd-0.5.0/external/URDFParser/__init__.py +7 -0
- grid_rbd-0.5.0/external/URDFParser/errors.py +48 -0
- grid_rbd-0.5.0/grid_codegen/GRiDCodeGenerator.py +1118 -0
- grid_rbd-0.5.0/grid_codegen/__init__.py +1 -0
- grid_rbd-0.5.0/grid_codegen/_algo_profiles.py +272 -0
- grid_rbd-0.5.0/grid_codegen/_constants_arena.py +2207 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/glass-cgrps.cuh +25 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/glass-defaults.cuh +469 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/glass-dispatch.cuh +149 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/glass-nvidia.cuh +280 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/glass.cuh +190 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L1/argreduce.cuh +416 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L1/asum.cuh +206 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L1/axpy.cuh +244 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L1/axpy_strided.cuh +117 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L1/clip.cuh +48 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L1/copy.cuh +187 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L1/copy_strided.cuh +117 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L1/dot.cuh +273 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L1/dot_strided.cuh +55 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L1/dot_strided_coalesced.cuh +82 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L1/elementwise_logic.cuh +416 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L1/iamax.cuh +395 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L1/ident.cuh +140 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L1/infnorm.cuh +57 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L1/norm.cuh +164 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L1/nrm1_diff.cuh +211 -0
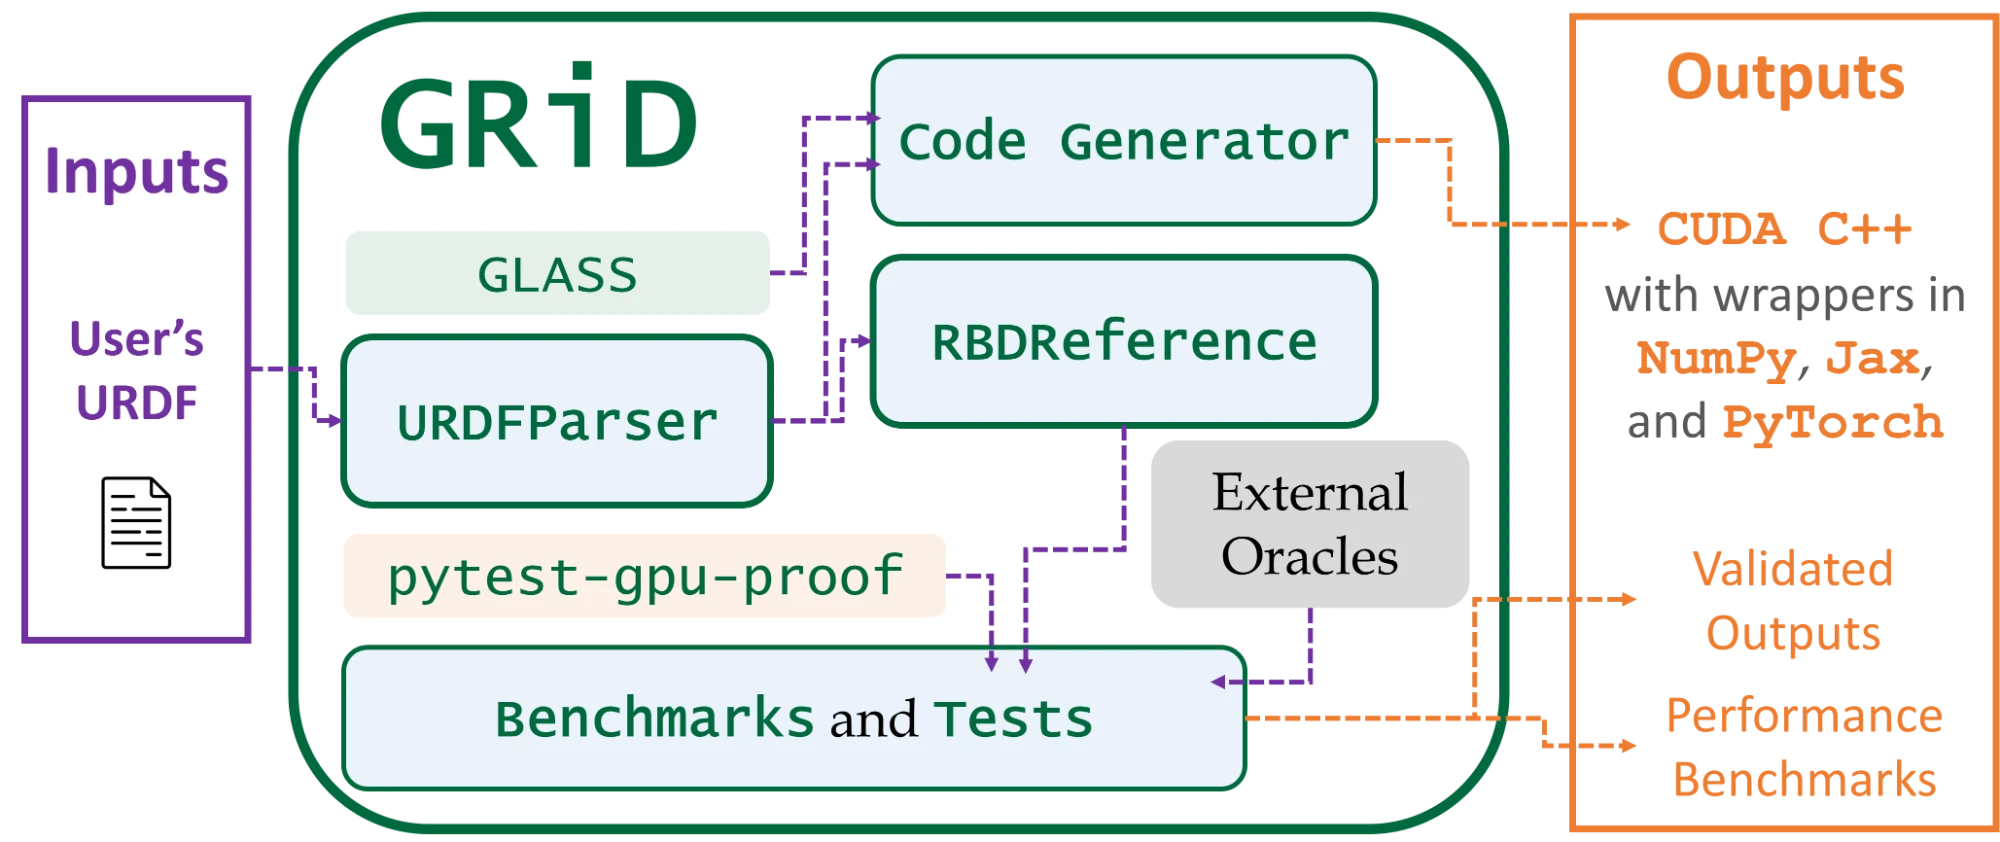
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L1/nrm2.cuh +243 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L1/prefix_sum.cuh +60 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L1/reduce.cuh +563 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L1/rot.cuh +223 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L1/scal.cuh +184 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L1/set_const.cuh +44 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L1/softmax.cuh +228 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L1/swap.cuh +46 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L1/symmetrize.cuh +170 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L1/transpose.cuh +102 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L1/vote.cuh +43 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L2/gemv.cuh +366 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L2/gemv_reduced.cuh +135 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L2/gemv_segmented.cuh +210 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L2/gemv_strided.cuh +70 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L2/ger.cuh +61 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L2/trsv.cuh +318 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L3/congruence.cuh +387 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L3/dimm.cuh +65 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L3/eigh.cuh +293 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L3/gemm.cuh +662 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L3/gemm_batched_indexed.cuh +120 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L3/gemm_reduced.cuh +208 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L3/gemm_strided.cuh +79 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L3/getrf.cuh +366 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L3/gn_step.cuh +90 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L3/inv.cuh +607 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L3/ldlt.cuh +782 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L3/posv.cuh +343 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L3/potrf.cuh +287 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L3/riccati.cuh +191 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L3/syev.cuh +374 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L3/symm.cuh +260 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L3/syrk.cuh +716 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L3/syrk_reduced.cuh +161 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L3/tensor_contract.cuh +307 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/L3/trsm.cuh +362 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/banded/bdmv.cuh +90 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/banded/bdsv.cuh +170 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/banded/block_access.cuh +136 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/barrier.cuh +125 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/dispatch.cuh +299 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/est/svd3.cuh +374 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/flags.cuh +16 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/geom/frame.cuh +45 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/geom/segment.cuh +88 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/geom/sphere.cuh +163 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/geom/transform_points.cuh +86 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/lie/angle.cuh +96 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/lie/pose.cuh +222 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/lie/quat.cuh +663 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/lie/se3.cuh +652 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/lie/so3.cuh +435 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/pcg/solve.cuh +152 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/proj/cone.cuh +169 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/proj/interval.cuh +325 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/spatial/cross.cuh +387 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/spatial/inertia.cuh +173 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/base/spatial/transform.cuh +317 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/cgrps/l1.cuh +276 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/cgrps/l2.cuh +191 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/cgrps/l3.cuh +387 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/internal/box_qp.cuh +157 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/nvidia/l1.cuh +148 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/nvidia/l1_warp.cuh +132 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/nvidia/l2.cuh +456 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/nvidia/l3.cuh +772 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/nvidia/l3_simt.cuh +245 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/nvidia/lapack.cuh +1409 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/nvidia/lapack_thread.cuh +177 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/nvidia/query.cuh +126 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/nvidia/query_simt.cuh +300 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/nvidia/tuning_table.cuh +181 -0
- grid_rbd-0.5.0/grid_codegen/_data/GLASS/src/nvidia/types.cuh +61 -0
- grid_rbd-0.5.0/grid_codegen/_data/launch_configs/baxter/rtx5090_sm120.json +923 -0
- grid_rbd-0.5.0/grid_codegen/_data/launch_configs/g1/rtx5090_sm120.json +1056 -0
- grid_rbd-0.5.0/grid_codegen/_data/launch_configs/go2/rtx5090_sm120.json +1056 -0
- grid_rbd-0.5.0/grid_codegen/_data/launch_configs/h1_2/rtx5090_sm120.json +948 -0
- grid_rbd-0.5.0/grid_codegen/_data/launch_configs/h2_plus/rtx5090_sm120.json +939 -0
- grid_rbd-0.5.0/grid_codegen/_data/launch_configs/iiwa14/rtx5090_sm120.json +1056 -0
- grid_rbd-0.5.0/grid_codegen/_data/licenses/GLASS/LICENSE +21 -0
- grid_rbd-0.5.0/grid_codegen/_data/licenses/RBDReference/LICENSE +21 -0
- grid_rbd-0.5.0/grid_codegen/_data/licenses/URDFParser/LICENSE +21 -0
- grid_rbd-0.5.0/grid_codegen/_data/provenance.json +139 -0
- grid_rbd-0.5.0/grid_codegen/_feature_macros.py +170 -0
- grid_rbd-0.5.0/grid_codegen/_reference_impl.py +603 -0
- grid_rbd-0.5.0/grid_codegen/abi_specs.py +1286 -0
- grid_rbd-0.5.0/grid_codegen/algo_registry.py +925 -0
- grid_rbd-0.5.0/grid_codegen/algorithms/__init__.py +30 -0
- grid_rbd-0.5.0/grid_codegen/algorithms/_aba.py +1572 -0
- grid_rbd-0.5.0/grid_codegen/algorithms/_bounded_spheres.py +112 -0
- grid_rbd-0.5.0/grid_codegen/algorithms/_centroidal.py +910 -0
- grid_rbd-0.5.0/grid_codegen/algorithms/_collision.py +1574 -0
- grid_rbd-0.5.0/grid_codegen/algorithms/_combos.py +143 -0
- grid_rbd-0.5.0/grid_codegen/algorithms/_coriolis.py +762 -0
- grid_rbd-0.5.0/grid_codegen/algorithms/_crba.py +1008 -0
- grid_rbd-0.5.0/grid_codegen/algorithms/_dccrba.py +943 -0
- grid_rbd-0.5.0/grid_codegen/algorithms/_eepose_gradient_hessian.py +3335 -0
- grid_rbd-0.5.0/grid_codegen/algorithms/_eepose_runtime.py +571 -0
- grid_rbd-0.5.0/grid_codegen/algorithms/_f_ext_contact.py +835 -0
- grid_rbd-0.5.0/grid_codegen/algorithms/_f_ext_gradient.py +940 -0
- grid_rbd-0.5.0/grid_codegen/algorithms/_fdsva_so.py +1351 -0
- grid_rbd-0.5.0/grid_codegen/algorithms/_forward_dynamics.py +373 -0
- grid_rbd-0.5.0/grid_codegen/algorithms/_forward_dynamics_gradient.py +673 -0
- grid_rbd-0.5.0/grid_codegen/algorithms/_frame_jacobian.py +1009 -0
- grid_rbd-0.5.0/grid_codegen/algorithms/_idsva_so.py +5054 -0
- grid_rbd-0.5.0/grid_codegen/algorithms/_integrator.py +1265 -0
- grid_rbd-0.5.0/grid_codegen/algorithms/_integrator_gradient.py +2265 -0
- grid_rbd-0.5.0/grid_codegen/algorithms/_inverse_dynamics.py +1015 -0
- grid_rbd-0.5.0/grid_codegen/algorithms/_inverse_dynamics_gradient.py +2358 -0
- grid_rbd-0.5.0/grid_codegen/algorithms/_minv.py +843 -0
- grid_rbd-0.5.0/grid_codegen/algorithms/_mjx_blockpar.py +42 -0
- grid_rbd-0.5.0/grid_codegen/algorithms/_multitarget.py +647 -0
- grid_rbd-0.5.0/grid_codegen/algorithms/_plant.py +2823 -0
- grid_rbd-0.5.0/grid_codegen/algorithms/_regressor.py +496 -0
- grid_rbd-0.5.0/grid_codegen/algorithms/_regressor_energy.py +487 -0
- grid_rbd-0.5.0/grid_codegen/algorithms/_regressor_fd_parameter_gradient.py +346 -0
- grid_rbd-0.5.0/grid_codegen/algorithms/_regressor_gradient.py +578 -0
- grid_rbd-0.5.0/grid_codegen/algorithms/_spherize.py +258 -0
- grid_rbd-0.5.0/grid_codegen/cli.py +185 -0
- grid_rbd-0.5.0/grid_codegen/collision/assets/go2_spherized.urdf +598 -0
- grid_rbd-0.5.0/grid_codegen/collision/assets/iiwa14_spherized.urdf +427 -0
- grid_rbd-0.5.0/grid_codegen/collision/grid_collision_geometry.cuh +750 -0
- grid_rbd-0.5.0/grid_codegen/core_body_gen.py +285 -0
- grid_rbd-0.5.0/grid_codegen/env_knobs.py +39 -0
- grid_rbd-0.5.0/grid_codegen/helpers/__init__.py +17 -0
- grid_rbd-0.5.0/grid_codegen/helpers/_code_generation_helpers.py +1512 -0
- grid_rbd-0.5.0/grid_codegen/helpers/_gpu_err.py +133 -0
- grid_rbd-0.5.0/grid_codegen/helpers/_host_clamp.py +126 -0
- grid_rbd-0.5.0/grid_codegen/helpers/_lin_alg_helpers.py +406 -0
- grid_rbd-0.5.0/grid_codegen/helpers/_spatial_algebra_helpers.py +230 -0
- grid_rbd-0.5.0/grid_codegen/helpers/_topology_helpers.py +1875 -0
- grid_rbd-0.5.0/grid_codegen/kernel_attrs.py +746 -0
- grid_rbd-0.5.0/grid_codegen/launch_config.py +235 -0
- grid_rbd-0.5.0/grid_codegen/resources.py +46 -0
- grid_rbd-0.5.0/grid_codegen/spherize.py +73 -0
- grid_rbd-0.5.0/grid_codegen/wrapper_body_gen.py +1222 -0
- grid_rbd-0.5.0/grid_codegen/wrapper_mjx_docs.py +191 -0
- grid_rbd-0.5.0/grid_codegen/wrapper_plant_gen.py +570 -0
- grid_rbd-0.5.0/grid_codegen/wrapper_surface_docs.py +231 -0
- grid_rbd-0.5.0/grid_rbd.egg-info/PKG-INFO +372 -0
- grid_rbd-0.5.0/grid_rbd.egg-info/SOURCES.txt +103 -0
- grid_rbd-0.5.0/grid_rbd.egg-info/dependency_links.txt +1 -0
- grid_rbd-0.5.0/grid_rbd.egg-info/entry_points.txt +3 -0
- grid_rbd-0.5.0/grid_rbd.egg-info/requires.txt +21 -0
- grid_rbd-0.5.0/grid_rbd.egg-info/top_level.txt +4 -0
- grid_rbd-0.5.0/pyproject.toml +172 -0
- grid_rbd-0.5.0/setup.cfg +4 -0
- grid_rbd-0.5.0/setup.py +38 -0
grid_rbd-0.5.0/LICENSE
ADDED
|
@@ -0,0 +1,21 @@
|
|
|
1
|
+
MIT License
|
|
2
|
+
|
|
3
|
+
Copyright (c) 2021 Hardware Acceleration for Robotics
|
|
4
|
+
|
|
5
|
+
Permission is hereby granted, free of charge, to any person obtaining a copy
|
|
6
|
+
of this software and associated documentation files (the "Software"), to deal
|
|
7
|
+
in the Software without restriction, including without limitation the rights
|
|
8
|
+
to use, copy, modify, merge, publish, distribute, sublicense, and/or sell
|
|
9
|
+
copies of the Software, and to permit persons to whom the Software is
|
|
10
|
+
furnished to do so, subject to the following conditions:
|
|
11
|
+
|
|
12
|
+
The above copyright notice and this permission notice shall be included in all
|
|
13
|
+
copies or substantial portions of the Software.
|
|
14
|
+
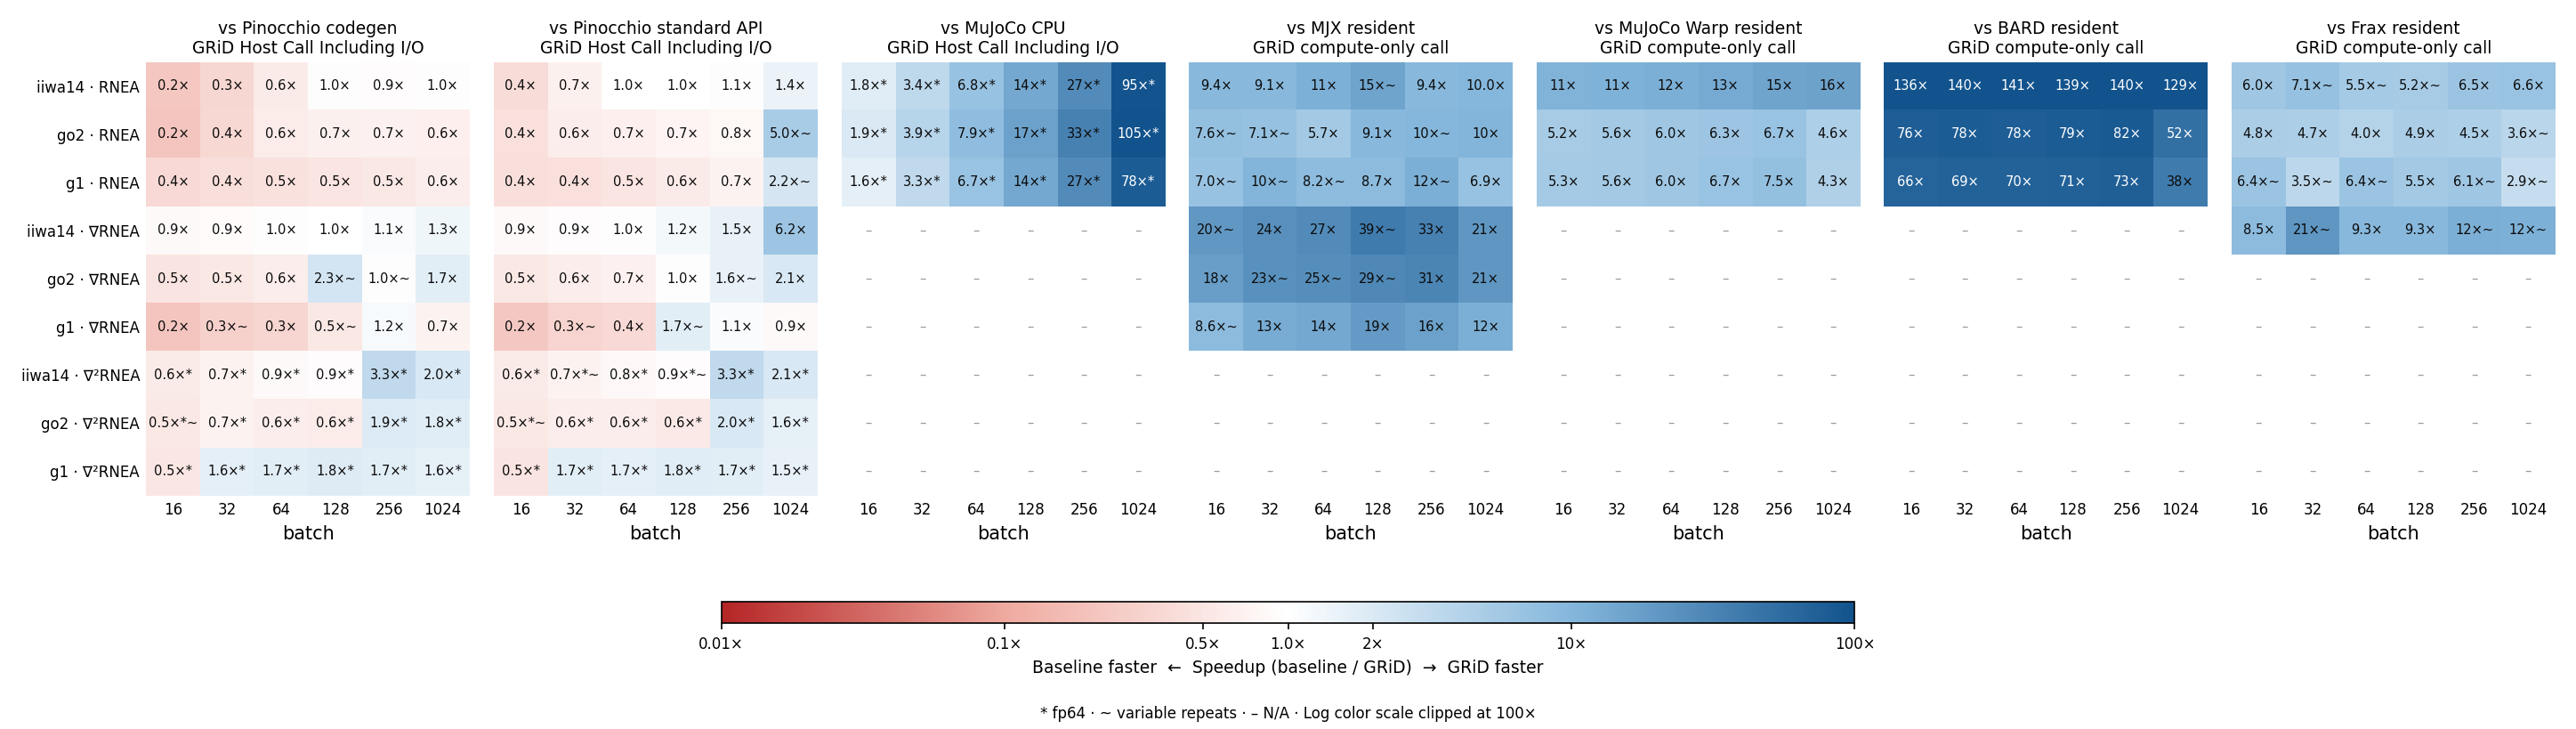
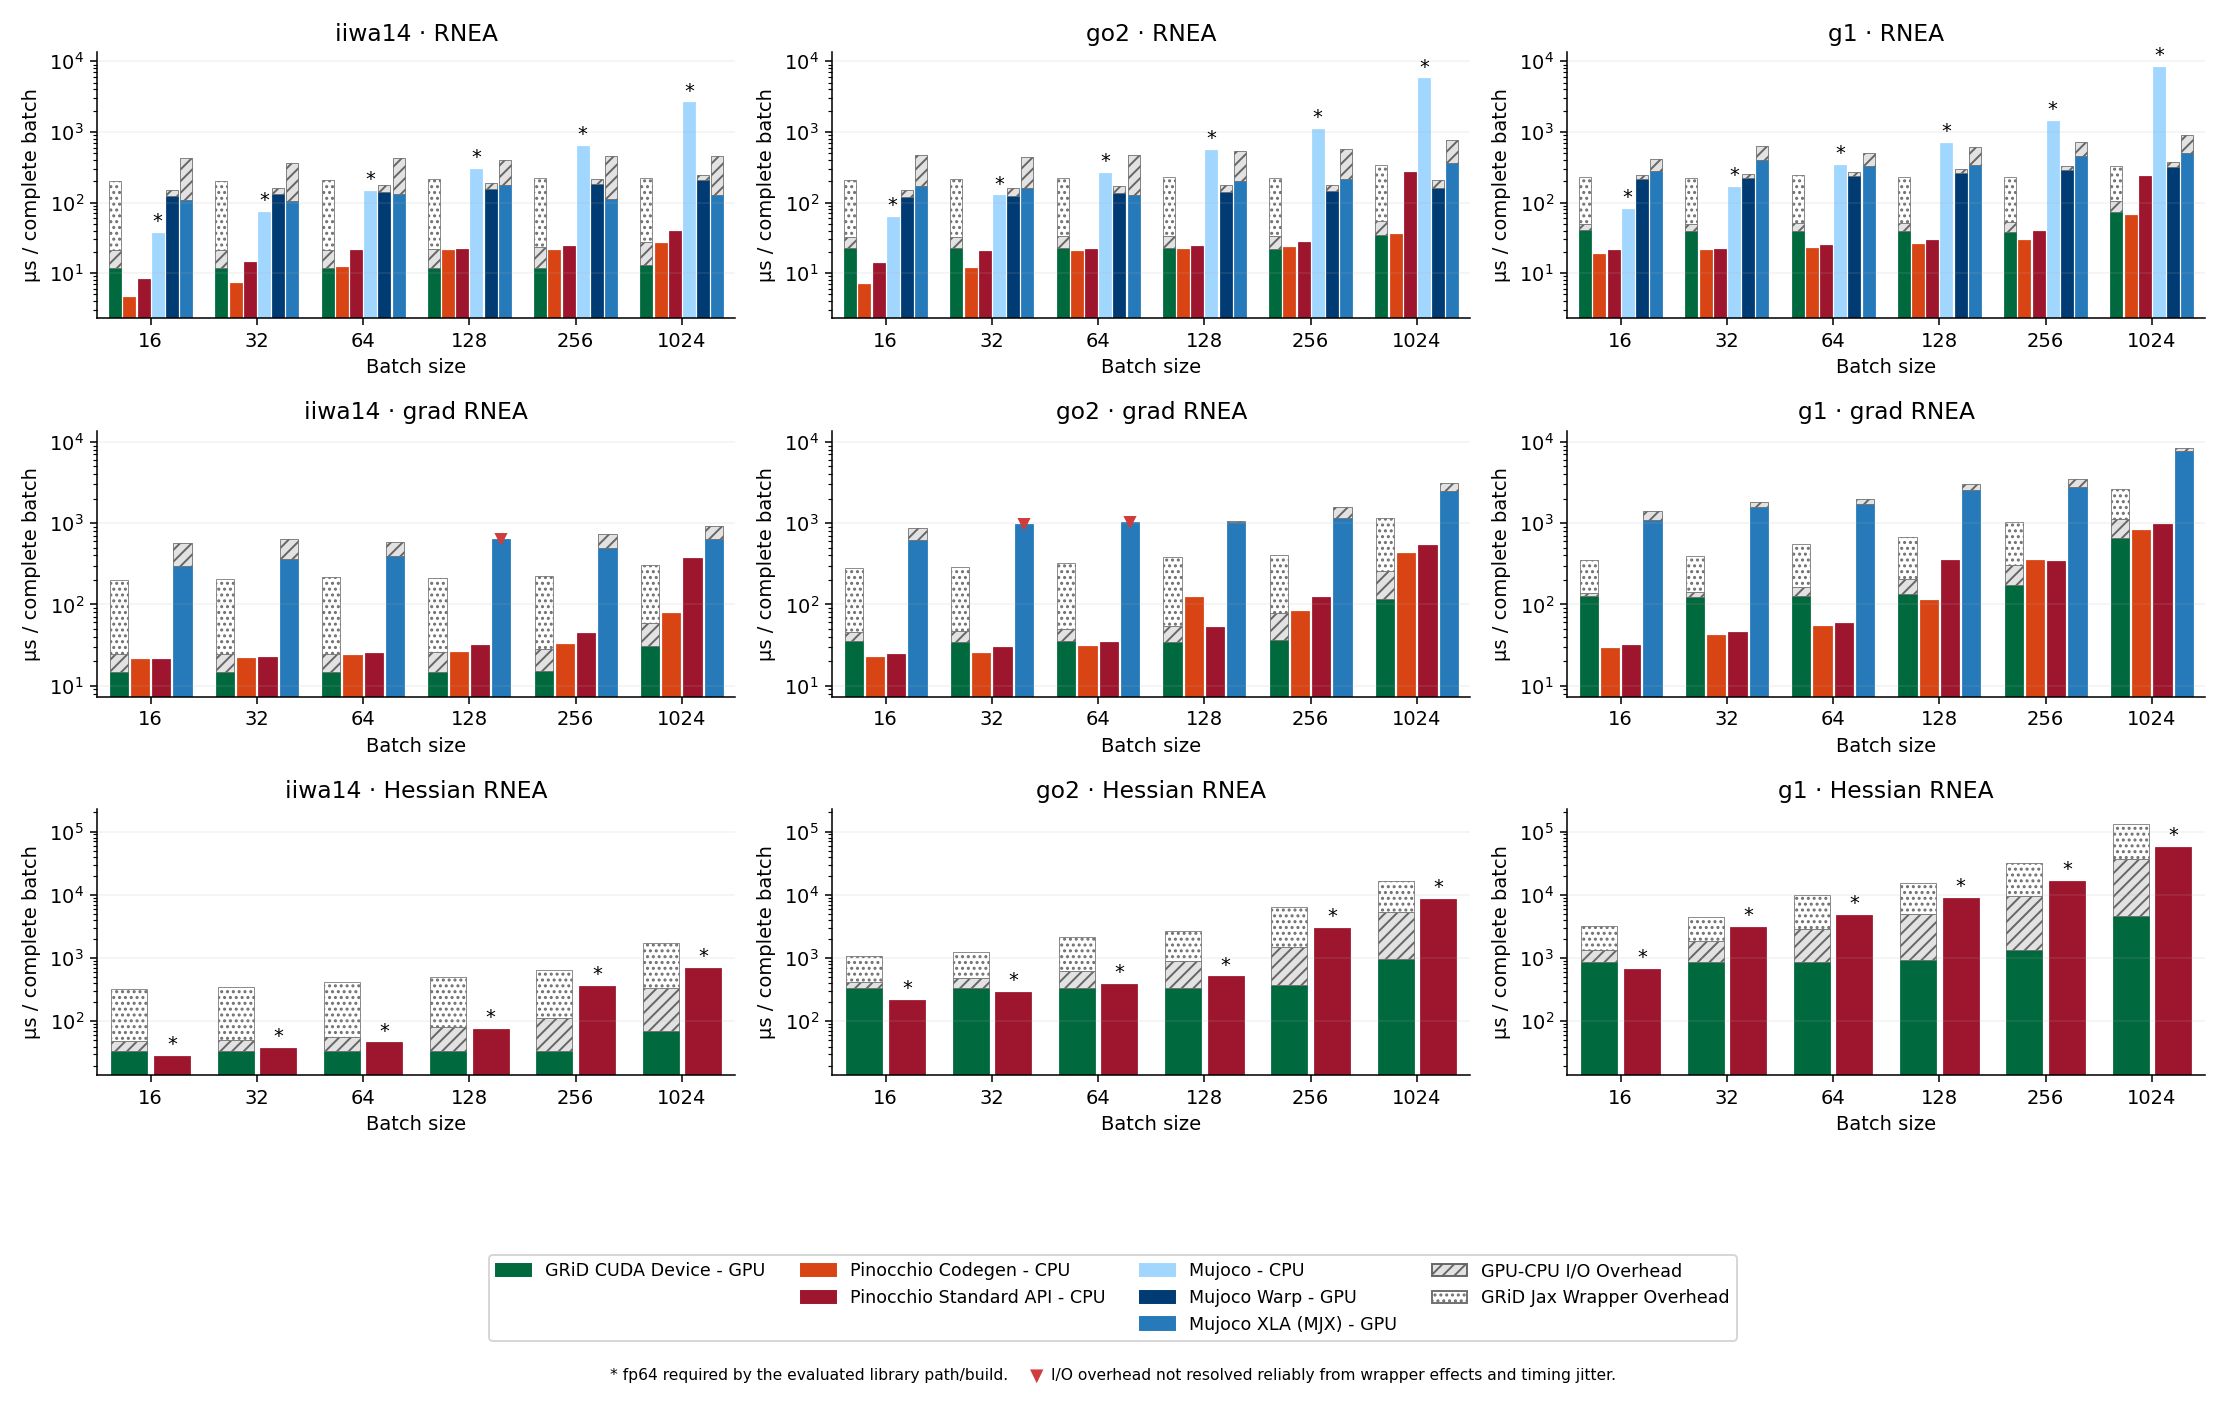
|
|
15
|
+
THE SOFTWARE IS PROVIDED "AS IS", WITHOUT WARRANTY OF ANY KIND, EXPRESS OR
|
|
16
|
+
IMPLIED, INCLUDING BUT NOT LIMITED TO THE WARRANTIES OF MERCHANTABILITY,
|
|
17
|
+
FITNESS FOR A PARTICULAR PURPOSE AND NONINFRINGEMENT. IN NO EVENT SHALL THE
|
|
18
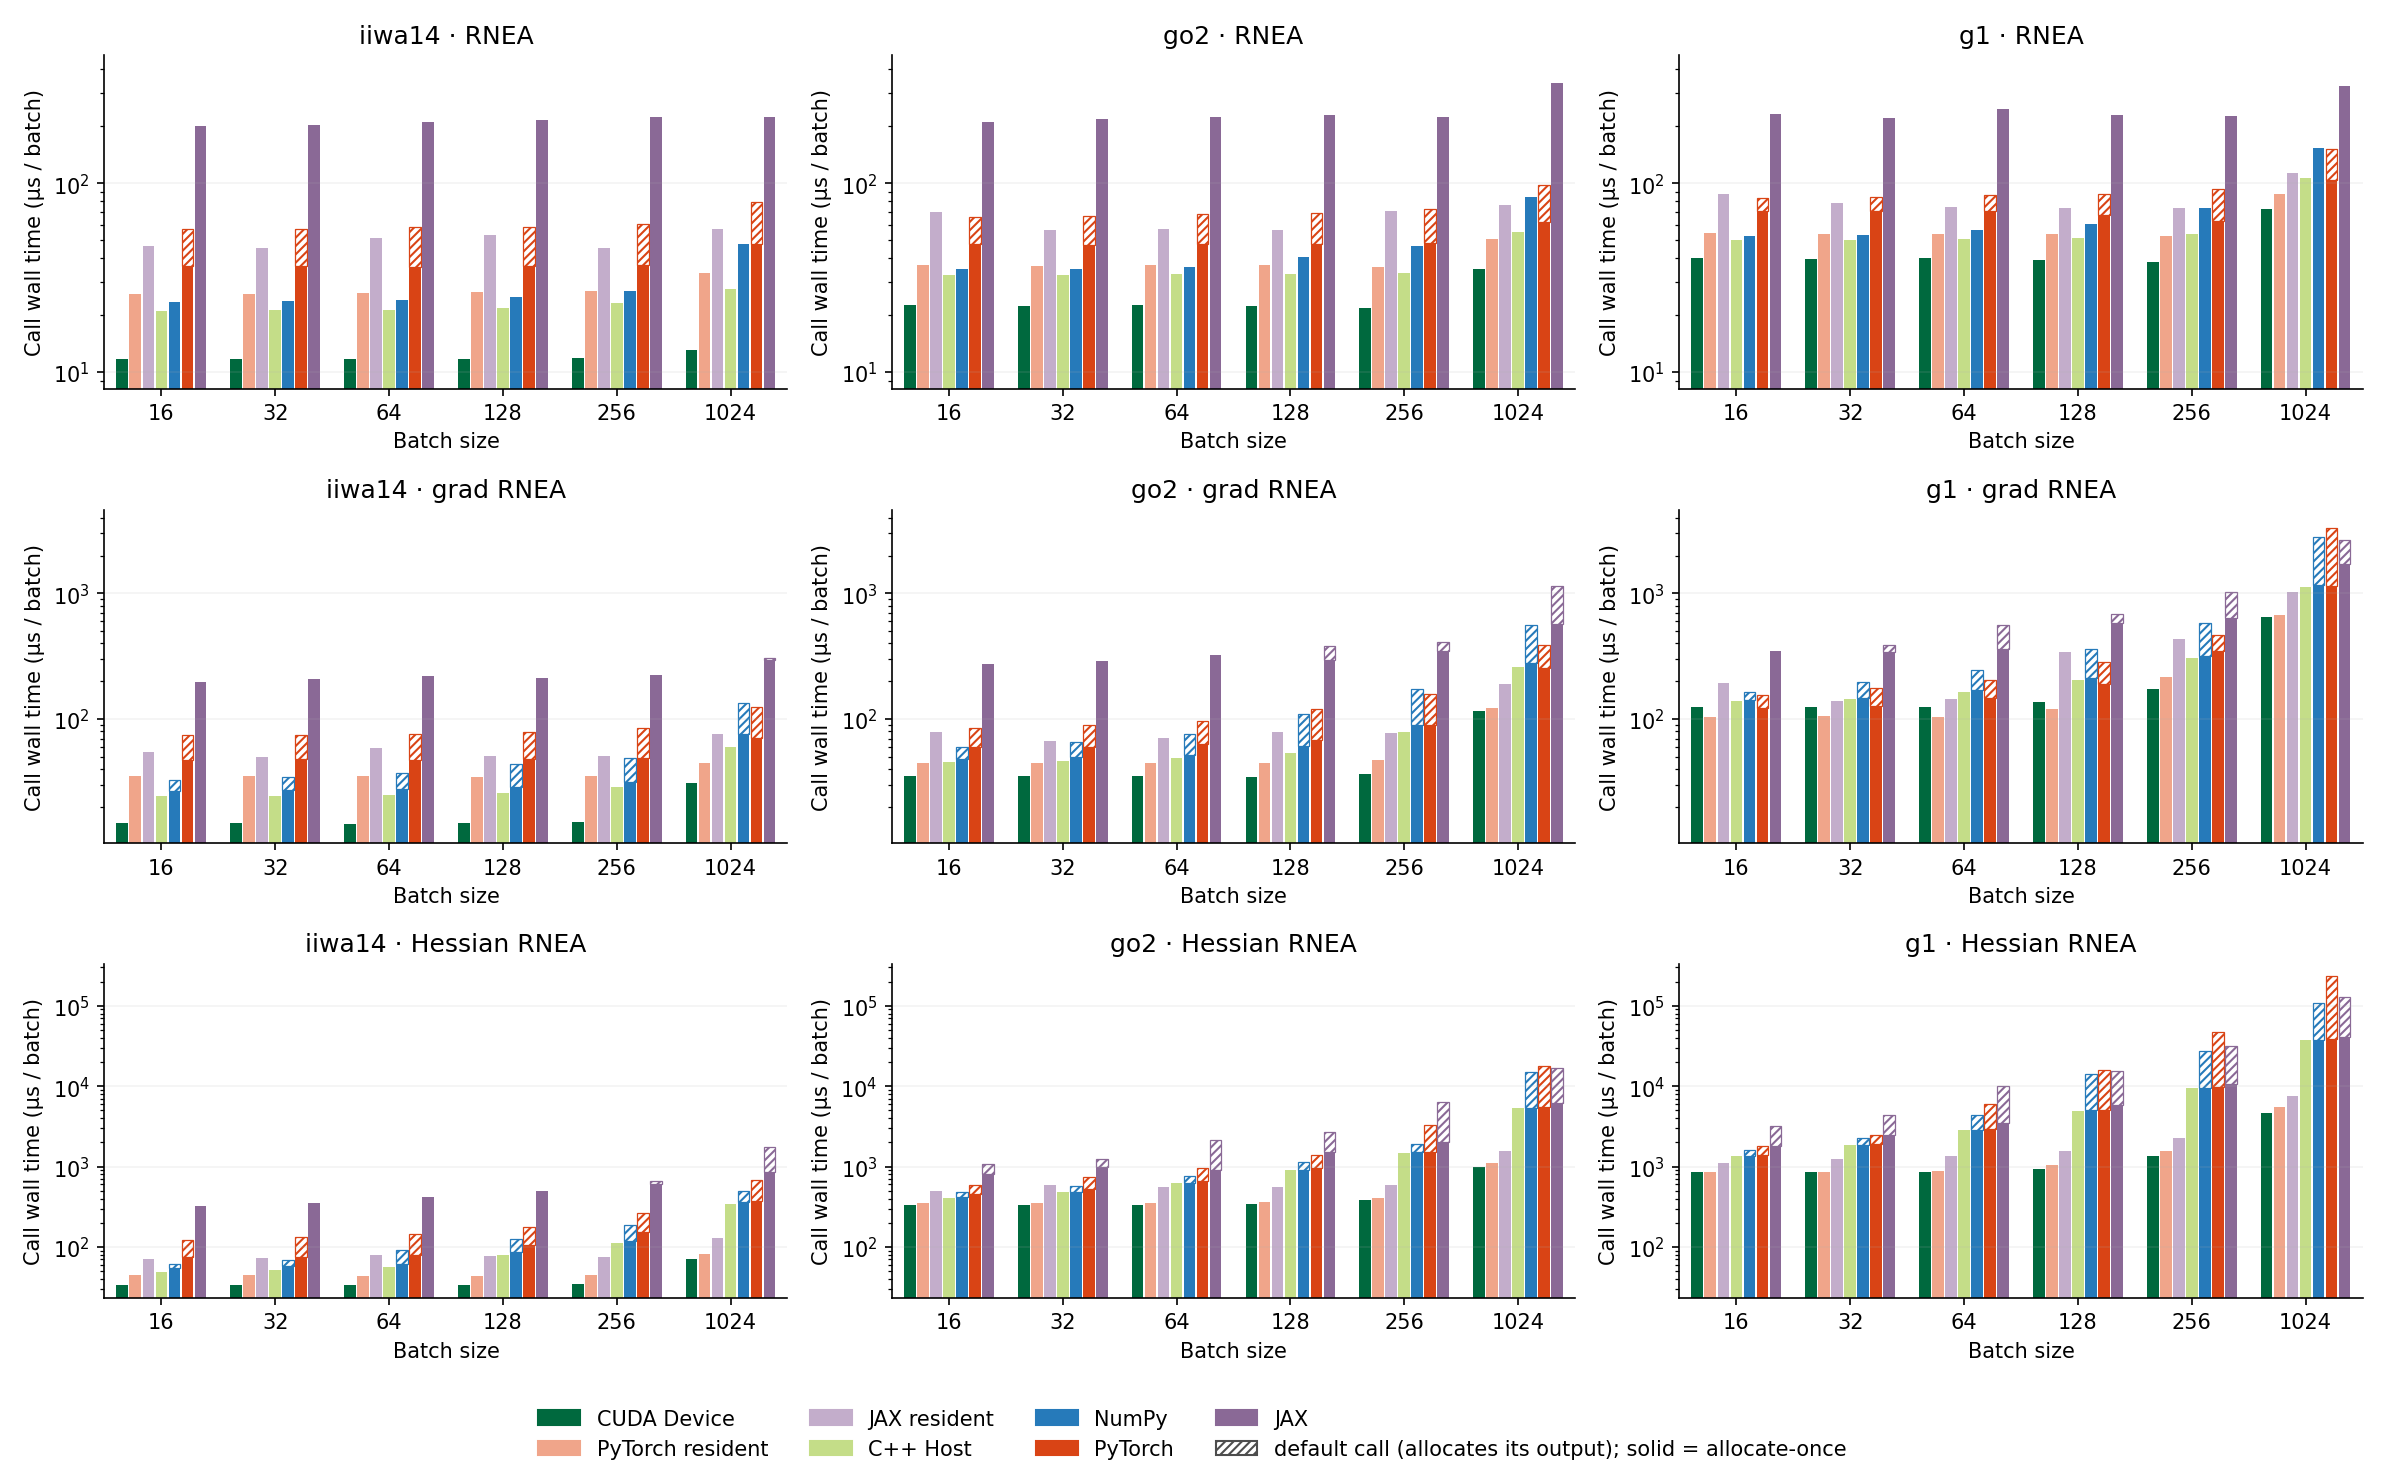
|
+
AUTHORS OR COPYRIGHT HOLDERS BE LIABLE FOR ANY CLAIM, DAMAGES OR OTHER
|
|
19
|
+
LIABILITY, WHETHER IN AN ACTION OF CONTRACT, TORT OR OTHERWISE, ARISING FROM,
|
|
20
|
+
OUT OF OR IN CONNECTION WITH THE SOFTWARE OR THE USE OR OTHER DEALINGS IN THE
|
|
21
|
+
SOFTWARE.
|
|
@@ -0,0 +1,25 @@
|
|
|
1
|
+
include _build_resources.py
|
|
2
|
+
include LICENSE*
|
|
3
|
+
include bindings/src/_core.cpp
|
|
4
|
+
recursive-include grid_codegen *.py *.cuh *.urdf
|
|
5
|
+
recursive-include grid_codegen/_data *
|
|
6
|
+
recursive-include bindings/grid_rbd *.py *.cuh *.cu py.typed
|
|
7
|
+
include external/URDFParser/*.py
|
|
8
|
+
include external/RBDReference/*.py
|
|
9
|
+
global-exclude __pycache__ *.pyc
|
|
10
|
+
prune docs
|
|
11
|
+
prune test
|
|
12
|
+
prune examples
|
|
13
|
+
prune install
|
|
14
|
+
prune config
|
|
15
|
+
prune .github
|
|
16
|
+
prune external/GLASS
|
|
17
|
+
prune external/URDFParser/tests
|
|
18
|
+
prune external/URDFParser/docs
|
|
19
|
+
prune external/RBDReference/tests
|
|
20
|
+
prune external/RBDReference/docs
|
|
21
|
+
prune external/RBDReference/equivalents
|
|
22
|
+
prune bindings/tests
|
|
23
|
+
prune bindings/examples
|
|
24
|
+
prune tools
|
|
25
|
+
exclude gpu-proof.json CLAUDE.md
|
grid_rbd-0.5.0/PKG-INFO
ADDED
|
@@ -0,0 +1,372 @@
|
|
|
1
|
+
Metadata-Version: 2.4
|
|
2
|
+
Name: grid-rbd
|
|
3
|
+
Version: 0.5.0
|
|
4
|
+
Summary: GPU robot dynamics, kinematics and collisions with analytical derivatives
|
|
5
|
+
Author: A2R Lab
|
|
6
|
+
License-Expression: MIT
|
|
7
|
+
Project-URL: Homepage, https://a2r-lab.org/GRiD/
|
|
8
|
+
Project-URL: Repository, https://github.com/A2R-Lab/GRiD
|
|
9
|
+
Project-URL: Documentation, https://a2r-lab.org/GRiD/
|
|
10
|
+
Project-URL: Changelog, https://github.com/A2R-Lab/GRiD/blob/main/CHANGELOG.md
|
|
11
|
+
Project-URL: Issues, https://github.com/A2R-Lab/GRiD/issues
|
|
12
|
+
Project-URL: Paper, https://a2r-lab.org/publication/grid/
|
|
13
|
+
Keywords: robotics,rigid-body-dynamics,kinematics,collision-checking,analytical-derivatives,cuda,gpu,code-generation,trajectory-optimization,jax,pytorch,mujoco,pinocchio
|
|
14
|
+
Classifier: Development Status :: 3 - Alpha
|
|
15
|
+
Classifier: Intended Audience :: Science/Research
|
|
16
|
+
Classifier: Operating System :: POSIX :: Linux
|
|
17
|
+
Classifier: Programming Language :: Python :: 3 :: Only
|
|
18
|
+
Classifier: Programming Language :: Python :: 3.10
|
|
19
|
+
Classifier: Programming Language :: Python :: 3.11
|
|
20
|
+
Classifier: Programming Language :: Python :: 3.12
|
|
21
|
+
Classifier: Programming Language :: C++
|
|
22
|
+
Classifier: Topic :: Scientific/Engineering
|
|
23
|
+
Classifier: Topic :: Scientific/Engineering :: Physics
|
|
24
|
+
Classifier: Topic :: Software Development :: Code Generators
|
|
25
|
+
Classifier: Environment :: GPU :: NVIDIA CUDA
|
|
26
|
+
Classifier: Intended Audience :: Developers
|
|
27
|
+
Classifier: Programming Language :: Python :: Implementation :: CPython
|
|
28
|
+
Classifier: Typing :: Typed
|
|
29
|
+
Requires-Python: >=3.10
|
|
30
|
+
Description-Content-Type: text/markdown
|
|
31
|
+
License-File: LICENSE
|
|
32
|
+
Requires-Dist: numpy>=1.23
|
|
33
|
+
Requires-Dist: sympy>=1.7.1
|
|
34
|
+
Requires-Dist: beautifulsoup4>=4.9.3
|
|
35
|
+
Requires-Dist: lxml>=4.2.1
|
|
36
|
+
Requires-Dist: trimesh>=4
|
|
37
|
+
Requires-Dist: scipy>=1.9
|
|
38
|
+
Requires-Dist: platformdirs>=4.0
|
|
39
|
+
Provides-Extra: jax
|
|
40
|
+
Requires-Dist: jax>=0.4.40; extra == "jax"
|
|
41
|
+
Provides-Extra: torch
|
|
42
|
+
Requires-Dist: torch>=2.1; extra == "torch"
|
|
43
|
+
Provides-Extra: all
|
|
44
|
+
Requires-Dist: grid-rbd[jax]; extra == "all"
|
|
45
|
+
Requires-Dist: grid-rbd[torch]; extra == "all"
|
|
46
|
+
Provides-Extra: dev
|
|
47
|
+
Requires-Dist: grid-rbd[all]; extra == "dev"
|
|
48
|
+
Requires-Dist: pytest>=7.0; extra == "dev"
|
|
49
|
+
Dynamic: license-file
|
|
50
|
+
|
|
51
|
+
# GRiD
|
|
52
|
+
[](https://github.com/A2R-Lab/GRiD/actions/workflows/verify-gpu-proof.yml)
|
|
53
|
+
[](https://a2r-lab.org/GRiD/)
|
|
54
|
+
[](https://github.com/A2R-Lab/GRiD/blob/main/LICENSE)
|
|
55
|
+
[](https://github.com/A2R-Lab/GRiD/blob/main/pyproject.toml)
|
|
56
|
+
[](https://github.com/A2R-Lab/GRiD/blob/main/CLAUDE.md)
|
|
57
|
+
[](#contributors)
|
|
58
|
+
|
|
59
|
+
A GPU-accelerated library for robot dynamics, kinematics, and collisions, with analytical derivatives and Hessians for supported numerical operations.
|
|
60
|
+
|
|
61
|
+
|
|
62
|
+
|
|
63
|
+
GRiD turns a URDF into optimized, per-robot CUDA C++ for rigid-body dynamics, kinematics, their analytical
|
|
64
|
+
first- and second-order derivatives and a trajectory-optimization plant layer, then hands you that code three
|
|
65
|
+
ways — a numpy handle, a `jax.jit`-able FFI surface, or `torch.autograd`-aware ops — from one content-addressed
|
|
66
|
+
`.so` cache. One CUDA block per problem, batched, bit-deterministic and thread-count invariant; the same
|
|
67
|
+
model and API rebuild for each target architecture (one artifact per `sm_XX`), with runtime memory
|
|
68
|
+
adaptation from embedded Jetson class devices to desktop GPUs. Website: https://a2r-lab.org/GRiD/.
|
|
69
|
+
|
|
70
|
+
GRiD builds on our [URDFParser](https://github.com/A2R-Lab/URDFParser), [RBDReference](https://github.com/A2R-Lab/RBDReference), and [GLASS](https://github.com/A2R-Lab/GLASS) packages (URDF parsing, Pinocchio-validated reference dynamics, and GPU linear algebra), together with its own bundled code generator. Using its scripts, users can easily generate and test optimized rigid body dynamics CUDA C++ code for their URDF files.
|
|
71
|
+
|
|
72
|
+
**Status: 0.5.0 is the first packaged release and is alpha software.** APIs may still change between
|
|
73
|
+
minor versions; see [CHANGELOG.md](https://github.com/A2R-Lab/GRiD/blob/main/CHANGELOG.md) for what has
|
|
74
|
+
landed since the paper and what is known to be missing. The [original ICRA 2022 paper](https://a2r-lab.org/publication/grid/)
|
|
75
|
+
describes the implementation preserved in the archival [robot-acceleration/GRiD](https://github.com/robot-acceleration/GRiD)
|
|
76
|
+
repository, not the feature set or performance of this release. See the [project website](https://a2r-lab.org/GRiD/)
|
|
77
|
+
for the overview. Collision routines use the generated CUDA interface; numerical Python interface coverage
|
|
78
|
+
is documented separately.
|
|
79
|
+
|
|
80
|
+
## I want to…
|
|
81
|
+
|
|
82
|
+
| Task | Start here |
|
|
83
|
+
|------|------------|
|
|
84
|
+
| **Call GRiD from Python** (numpy/JAX/torch) | `grid_rbd.load_robot("robot.urdf", backend=...)` — [Python wrappers docs](https://a2r-lab.org/GRiD/user_guide/tutorials/python_wrappers.html) · [agent guide](https://github.com/A2R-Lab/GRiD/blob/main/bindings/examples/AGENT_INTEGRATION_GUIDE.md) |
|
|
85
|
+
| **Generate CUDA for a new robot** | `grid-generate config/robot_assets/iiwa14.urdf` — see Quick Start below |
|
|
86
|
+
| **Fit a humanoid build in RAM** | [fast robot setup](https://a2r-lab.org/GRiD/user_guide/getting_started/fast_robot_setup.html) (`algorithm_list=`, `enable_mujoco_kernels=False`) |
|
|
87
|
+
| **Add an algorithm** | [adding an algorithm](https://a2r-lab.org/GRiD/user_guide/tutorials/adding_an_algorithm.html) |
|
|
88
|
+
| **Run tests / fix a red receipt CI job** | [CUDA validation](https://a2r-lab.org/GRiD/user_guide/tutorials/cuda_validation.html) + `test/run_gpu_proof.sh --help` |
|
|
89
|
+
| **Benchmark** | [benchmarks](https://a2r-lab.org/GRiD/user_guide/tutorials/benchmarks.html) |
|
|
90
|
+
| **Debug a CUDA-vs-numpy mismatch** | [docs/agent_debugging_guide.md](https://github.com/A2R-Lab/GRiD/blob/main/docs/agent_debugging_guide.md) — the bug-class bible |
|
|
91
|
+
| **Get MuJoCo/mjx-convention I/O** | `handle.mujoco.<method>(...)` — values AND derivatives/second-order |
|
|
92
|
+
| **Everything else** | [How do I…?](https://a2r-lab.org/GRiD/how_do_i.html) on the docs site |
|
|
93
|
+
|
|
94
|
+
**Start-here track:** [`examples/README.md`](https://github.com/A2R-Lab/GRiD/blob/main/examples/README.md) routes the four usage tracks — the [`examples/notebooks/`](https://github.com/A2R-Lab/GRiD/tree/main/examples/notebooks/) Python-bindings tour (01-quickstart → 07-inline-cuda), the runnable [`bindings/examples/`](https://github.com/A2R-Lab/GRiD/tree/main/bindings/examples/) scripts, codegen scripts, and hand-written-CUDA walkthroughs.
|
|
95
|
+
|
|
96
|
+
**A checkout contains submodules: run ```git submodule update --init --recursive``` after cloning without `--recursive`.** A PyPI install bundles them.
|
|
97
|
+
|
|
98
|
+
## Quick Start
|
|
99
|
+
|
|
100
|
+
Install from PyPI (Linux x86-64, Python 3.10–3.12; no GPU or compiler needed to install — robot CUDA is
|
|
101
|
+
compiled by `register_robot` using the `nvcc` on your `PATH`):
|
|
102
|
+
```shell
|
|
103
|
+
pip install grid-rbd # code generator + numpy backend + grid-generate / grid-spherize CLIs
|
|
104
|
+
pip install "grid-rbd[jax]" # + JAX FFI surface (install a CUDA jax wheel yourself)
|
|
105
|
+
pip install "grid-rbd[torch]" # + torch backend (install a CUDA torch wheel yourself)
|
|
106
|
+
pip install "grid-rbd[all]" # jax + torch
|
|
107
|
+
```
|
|
108
|
+
|
|
109
|
+
Or work from a checkout (creates a local venv, editable install, registers the CLIs):
|
|
110
|
+
```shell
|
|
111
|
+
git clone --recursive https://github.com/A2R-Lab/GRiD.git && cd GRiD
|
|
112
|
+
bash install/base_install.sh
|
|
113
|
+
source .venv/bin/activate
|
|
114
|
+
```
|
|
115
|
+
|
|
116
|
+
Generate CUDA code for your robot (ten ready-to-use URDFs ship in
|
|
117
|
+
`config/robot_assets/` — iiwa14, go2, fr3, g1, h1_2, …):
|
|
118
|
+
```shell
|
|
119
|
+
# Via the installed CLI (works on a clean base install):
|
|
120
|
+
grid-generate config/robot_assets/iiwa14.urdf # arm, fixed base
|
|
121
|
+
grid-generate config/robot_assets/go2.urdf -f # quadruped, floating base
|
|
122
|
+
grid-generate path/to/robot.urdf [-t EE_JOINT_NAME] [-n NAMESPACE] [-f] [--algorithm-list LIST] [-o OUT.cuh]
|
|
123
|
+
|
|
124
|
+
# Or via a hardcoded zero-config example (these two pull their URDFs from the
|
|
125
|
+
# robot_descriptions package — a DEV dependency; install install/requirements-dev.txt first):
|
|
126
|
+
python examples/codegen/generate_iiwa14.py # iiwa14 fixed base
|
|
127
|
+
python examples/codegen/generate_go2_floating.py # Go2 floating base
|
|
128
|
+
```
|
|
129
|
+
|
|
130
|
+
Validate and debug:
|
|
131
|
+
```shell
|
|
132
|
+
# Print CPU reference values for all algorithms:
|
|
133
|
+
python examples/codegen/print_reference_values.py path/to/robot.urdf
|
|
134
|
+
|
|
135
|
+
# Compile and run the CUDA print kernel (requires nvcc):
|
|
136
|
+
python examples/codegen/print_grid.py path/to/robot.urdf
|
|
137
|
+
```
|
|
138
|
+
|
|
139
|
+
Write your own CUDA kernel against the generated header:
|
|
140
|
+
```shell
|
|
141
|
+
# Step-by-step walkthrough + compiling/validated example kernels:
|
|
142
|
+
# examples/cuda/README.md (and examples/cuda/wrapper_types.md)
|
|
143
|
+
bash examples/cuda/build_and_validate.sh # generate → nvcc → run → validate
|
|
144
|
+
```
|
|
145
|
+
|
|
146
|
+
> **Requires a C++17-capable host compiler** (e.g., g++ ≥ 7, clang++ ≥ 5).
|
|
147
|
+
> The benchmark and codegen runtime compile with `-std=c++17` — needed for
|
|
148
|
+
> inline variables in the bench common header. With the `[torch]` extra the
|
|
149
|
+
> per-robot `.so` follows torch's ATen requirement (`-std=c++20` from torch
|
|
150
|
+
> 2.14; needs CUDA 12+ and g++ ≥ 10).
|
|
151
|
+
|
|
152
|
+
## Usage
|
|
153
|
+
+ `grid-generate PATH_TO_URDF` — generate `grid.cuh`; add `-d` for full debug mode, `-f` for floating base, `-t JOINT_NAME` to target a specific end-effector joint
|
|
154
|
+
+ `python examples/codegen/print_reference_values.py PATH_TO_URDF` — print CPU reference values for all algorithms to validate CUDA output
|
|
155
|
+
+ `python examples/codegen/print_grid.py PATH_TO_URDF` — compile and run the CUDA print kernel against the generated header
|
|
156
|
+
|
|
157
|
+
## Floating-Base Conventions
|
|
158
|
+
Floating-base parsing and the Python reference path now accept a public
|
|
159
|
+
floating-base convention flag. The default is Pinocchio-compatible:
|
|
160
|
+
|
|
161
|
+
+ `floating_base_convention="pinocchio"`:
|
|
162
|
+
`q = [x, y, z, qx, qy, qz, qw]`,
|
|
163
|
+
`v = [vx, vy, vz, wx, wy, wz]`
|
|
164
|
+
+ `floating_base_convention="legacy"`:
|
|
165
|
+
`q = [x, y, z, qw, qx, qy, qz]`,
|
|
166
|
+
`v = [wx, wy, wz, vx, vy, vz]`
|
|
167
|
+
|
|
168
|
+
GRiD normalizes both public conventions into one shared internal floating-base
|
|
169
|
+
representation, so the code generator and `RBDReference` stay consistent under
|
|
170
|
+
the hood while callers can choose the input/output ordering they need.
|
|
171
|
+
|
|
172
|
+
## Developer Testing
|
|
173
|
+
|
|
174
|
+
Contributor-facing test workflows (floating-convention regression suite, CUDA
|
|
175
|
+
equivalence env overrides, shared-memory targets) moved to
|
|
176
|
+
[CONTRIBUTING.md](https://github.com/A2R-Lab/GRiD/blob/main/CONTRIBUTING.md#developer-testing); the receipt/verification
|
|
177
|
+
policy lives in the
|
|
178
|
+
[CUDA validation guide](https://a2r-lab.org/GRiD/user_guide/tutorials/cuda_validation.html).
|
|
179
|
+
|
|
180
|
+
|
|
181
|
+
## Current Support
|
|
182
|
+
GRiD supports open-chain and tree models with revolute, prismatic, fixed,
|
|
183
|
+
floating, mimic, and additional joint types. Support is operation-specific;
|
|
184
|
+
see the [joint and algorithm restrictions](https://a2r-lab.org/GRiD/docs/user_guide/tutorials/cuda_support_status.html)
|
|
185
|
+
and [backend inventory](https://a2r-lab.org/GRiD/docs/user_guide/tutorials/backend_coverage.html).
|
|
186
|
+
|
|
187
|
+
GRiD implements the full modern rigid-body-dynamics stack: RNEA / CRBA / ABA /
|
|
188
|
+
Minv / forward dynamics; analytical first-order gradients (ID + FD, incl.
|
|
189
|
+
external-force gradients); the second-order derivatives (IDSVA-SO both frames
|
|
190
|
+
with a codegen-time dispatcher, FDSVA-SO); the kinematics family (EE pose /
|
|
191
|
+
Jacobian / Hessian, general-frame `frame_jacobian`/`J̇`/OSC inertia, runtime
|
|
192
|
+
multi-EE targets); integrators + integrator gradients; the centroidal family
|
|
193
|
+
(CoM, CCRBA, `dccrba`, CMM time-variation, Coriolis matrix, energy/ID
|
|
194
|
+
regressors); the inertial-parameter (π) family (the joint-torque regressor
|
|
195
|
+
`Y` with its analytic gradient ∂Y/∂(q,v) and the FD parameter gradient
|
|
196
|
+
∂q̈/∂π); contact-frame wrench mapping (`contact_fext` /
|
|
197
|
+
`register_robot(contact_frames=...)`); runtime tool/payload welding
|
|
198
|
+
(`attach_tool`/`tool_fext`); runtime multi-target positions; the collision
|
|
199
|
+
family (two-tier `config_free`); a trajectory-optimization `grid_plant`
|
|
200
|
+
cost/step layer; and
|
|
201
|
+
runtime-mutable inertia/transform/joint-dynamics tables. The **complete
|
|
202
|
+
per-algorithm catalog with citations and per-feature detail** lives in the
|
|
203
|
+
[CUDA support status page](https://a2r-lab.org/GRiD/user_guide/tutorials/cuda_support_status.html).
|
|
204
|
+
|
|
205
|
+
`RBDReference` additionally provides numpy reference oracles — validated against [Pinocchio](https://github.com/stack-of-tasks/pinocchio) — for generalized gravity, nonlinear effects, kinetic/potential/mechanical energy, the Coriolis matrix, the centroidal quantities (CoM, CoM Jacobian, CCRBA, centroidal momentum) and their derivatives (the analytic `dccrba` ∂A/∂q tensor — replacing the prior finite-difference oracle — and `cmm_time_variation` Ȧ), the inverse-dynamics and kinetic/potential-energy regressors, the general-frame Jacobian / J̇ / OSC inertia described above, and the plant/cost/barrier layer above.
|
|
206
|
+
|
|
207
|
+
**Dual-surface equivalence.** Every algorithm exists on two surfaces that are tested for numerical agreement: the `RBDReference` numpy implementation (the oracle, checked against Pinocchio) and the generated CUDA C++ kernels (checked against that same numpy reference). This keeps the GPU codegen honest against an independent, Pinocchio-validated baseline.
|
|
208
|
+
|
|
209
|
+
**Mimic-joint support:** per-robot gating is now essentially eliminated. Non-gradient algorithms (RNEA, forward dynamics, ABA, CRBA, …) work for robots with mimic joints, and every **gradient** emits a correct mimic-reduced result on **both** the fixed and floating base: `inverse_dynamics_gradient`/`forward_dynamics_gradient`, `end_effector_pose_gradient`/`end_effector_pose_hessian`, the second-order `idsva_so`/`fdsva_so`, the external-force gradients (`f_ext_gradient`), and the integrator gradients. The centroidal family — `com`, `ccrba`, `energy`, and the centroidal derivatives `dccrba`/`cmm_time_variation` — now also runs on mimic robots (the per-body Jacobian and per-unit motion columns carry the mimic multiplier α, validated against the mimic-aware reference). `dccrba`/`cmm_time_variation` additionally run on big floating-base robots (e.g. `g1`/`h1_2`-floating) via the sweep-pool spill path. No algorithm raises `NotImplementedError` for mimic robots anymore.
|
|
210
|
+
|
|
211
|
+
Additional algorithms and features are in development. If you have a particular algorithm or feature in mind please let us know by posting a GitHub issue. We'd also love your collaboration in implementing the Python reference implementation of any algorithm you'd like implemented!
|
|
212
|
+
|
|
213
|
+
## Repo map
|
|
214
|
+
|
|
215
|
+
| Directory | Owns | Entry doc |
|
|
216
|
+
|-----------|------|-----------|
|
|
217
|
+
| `grid_codegen/` | the code-generation engine: emits `grid.cuh` AND the checked-in generated binding regions, all driven by the `abi_specs.py` table | [codegen architecture](https://a2r-lab.org/GRiD/user_guide/concepts/codegen_architecture.html) |
|
|
218
|
+
| `bindings/` | the `grid-rbd` Python package (numpy/jax/torch handles over a cached per-robot `.so`) | [`bindings/README.md`](https://github.com/A2R-Lab/GRiD/blob/main/bindings/README.md) · [agent guide](https://github.com/A2R-Lab/GRiD/blob/main/bindings/examples/AGENT_INTEGRATION_GUIDE.md) |
|
|
219
|
+
| `external/` | the peer-product submodules: `GLASS` (GPU linear algebra), `RBDReference` (Pinocchio-validated numpy oracle), `URDFParser` | each submodule's README |
|
|
220
|
+
| `examples/` | the start-here track: `notebooks/` (Python tour), `codegen/`, `cuda/` | [`examples/README.md`](https://github.com/A2R-Lab/GRiD/blob/main/examples/README.md) |
|
|
221
|
+
| `test/` | pytest suites + the split-suite/receipt machinery (`run_split_suite.py`, `run_gpu_proof.sh`, `compile_sched.py`) | [CUDA validation](https://a2r-lab.org/GRiD/user_guide/tutorials/cuda_validation.html) |
|
|
222
|
+
| `config/` | ten sample URDFs (`robot_assets/`) + tuned per-GPU launch configs (`launch_configs/`) + `autotune_robot.sh` | `config/robot_assets/URDF_SOURCES.md` |
|
|
223
|
+
| `docs/` | the Sphinx site (`source/`) + `agent_debugging_guide.md` (the bug-class bible) | [docs site](https://a2r-lab.org/GRiD/) |
|
|
224
|
+
| `install/` | install scripts (`base_install.sh`, `developer_install.sh`) + requirements files | [installation guide](https://a2r-lab.org/GRiD/user_guide/getting_started/installation.html) |
|
|
225
|
+
|
|
226
|
+
## C++ API
|
|
227
|
+
The generated external interface has three layers: `*_device` (algorithm-specific
|
|
228
|
+
buffer and scratch contract, with placement owned by the device function),
|
|
229
|
+
`*_kernel` (global entry point with batched timestep loop), and the
|
|
230
|
+
host wrapper (CPU launcher with H↔D copies). Internal `*_inner` helpers support
|
|
231
|
+
composition without repeating shared setup. See the
|
|
232
|
+
[codegen architecture docs](https://a2r-lab.org/GRiD/user_guide/concepts/codegen_architecture.html)
|
|
233
|
+
for the rationale and concrete signatures.
|
|
234
|
+
|
|
235
|
+
## Python API (`grid-rbd`)
|
|
236
|
+
|
|
237
|
+
For Python users the `grid-rbd` package (in [`bindings/`](https://github.com/A2R-Lab/GRiD/tree/main/bindings/)) wraps
|
|
238
|
+
the per-robot codegen behind a register-then-run UX with `numpy`, `jax`,
|
|
239
|
+
and `torch` backends. It ships in the same `grid-rbd` distribution as the code generator, so
|
|
240
|
+
`pip install grid-rbd` (or `pip install -e .` from a checkout, what `install/base_install.sh` runs)
|
|
241
|
+
installs the codegen toolkit *and* the `grid_rbd` wrapper together. The base install is minimal;
|
|
242
|
+
pick a backend extra for the surface you want:
|
|
243
|
+
|
|
244
|
+
```bash
|
|
245
|
+
pip install grid-rbd # base: numpy backend only
|
|
246
|
+
pip install "grid-rbd[jax]" # + JAX FFI surface
|
|
247
|
+
pip install "grid-rbd[torch]" # + torch backend (CUDA wheel matching your GPU arch)
|
|
248
|
+
pip install "grid-rbd[all]" # jax + torch
|
|
249
|
+
```
|
|
250
|
+
|
|
251
|
+
See the [install matrix in `bindings/README.md`](https://github.com/A2R-Lab/GRiD/blob/main/bindings/README.md#install-editable-from-a-grid-checkout)
|
|
252
|
+
for what each extra unlocks (and the torch CUDA-wheel note).
|
|
253
|
+
|
|
254
|
+
```python
|
|
255
|
+
import grid_rbd
|
|
256
|
+
|
|
257
|
+
# numpy (default), jax, or torch; urdf_string= also accepted instead of urdf_path
|
|
258
|
+
handle = grid_rbd.register_robot("iiwa14", urdf_path="iiwa.urdf", backend="torch")
|
|
259
|
+
|
|
260
|
+
qdd = handle.forward_dynamics(q, qd, u) # autograd-aware torch.Tensor
|
|
261
|
+
qdd.sum().backward() # gradients flow to q, qd, u
|
|
262
|
+
```
|
|
263
|
+
|
|
264
|
+
The `torch` backend exposes autograd-aware `inverse_dynamics` / `forward_dynamics` /
|
|
265
|
+
`aba` / `integrator` (analytic backward passes) plus CUDA-Graphs capture,
|
|
266
|
+
and the handle also surfaces the `grid_plant` cost/barrier methods. `inverse_dynamics`
|
|
267
|
+
(alias `rnea`) takes an optional `qdd=` (the
|
|
268
|
+
autograd gradient is qdd-aware, returning the correct ∂τ/∂(q,q̇) including the
|
|
269
|
+
∂(M·q̈)/∂q term), and all three backends expose the value ops `coriolis_matrix`,
|
|
270
|
+
`kinetic_energy_regressor`, `potential_energy_regressor`, `dccrba`, and
|
|
271
|
+
`cmm_time_variation` (forward-only on jax/torch). The π-regressor family
|
|
272
|
+
(`inverse_dynamics_regressor`, the differentiable
|
|
273
|
+
`inverse_dynamics_wrt_params`/`forward_dynamics_wrt_params`, and the
|
|
274
|
+
`forward_dynamics_parameter_gradient` ∂q̈/∂π), runtime tool welding
|
|
275
|
+
(`attach_tool`/`tool_fext`, via `enable_tool=True`), and multi-contact
|
|
276
|
+
wrench mapping (`contact_fext`, via `register_robot(contact_frames=[...])`)
|
|
277
|
+
are bound as well. For true fp64 compute build with
|
|
278
|
+
`register_robot(..., dtype="float64")` (its own cache entry); `allow_fp64=True`
|
|
279
|
+
is only the numpy handle's fp64-in/fp64-out convenience cast on an fp32 build
|
|
280
|
+
(ignored when `dtype="float64"`). See
|
|
281
|
+
[`bindings/README.md`](https://github.com/A2R-Lab/GRiD/blob/main/bindings/README.md) and the
|
|
282
|
+
[Python wrappers docs](https://a2r-lab.org/GRiD/user_guide/tutorials/python_wrappers.html).
|
|
283
|
+
|
|
284
|
+
## Citing GRiD
|
|
285
|
+
To cite GRiD in your research, please use the following bibtex for our paper ["GRiD: GPU-Accelerated Rigid Body Dynamics with Analytical Gradients"](https://brianplancher.com/publication/grid/):
|
|
286
|
+
```
|
|
287
|
+
@inproceedings{plancher2022grid,
|
|
288
|
+
title={GRiD: GPU-Accelerated Rigid Body Dynamics with Analytical Gradients},
|
|
289
|
+
author={Brian Plancher and Sabrina M. Neuman and Radhika Ghosal and Scott Kuindersma and Vijay Janapa Reddi},
|
|
290
|
+
booktitle={IEEE International Conference on Robotics and Automation (ICRA)},
|
|
291
|
+
year={2022},
|
|
292
|
+
month={May}
|
|
293
|
+
}
|
|
294
|
+
```
|
|
295
|
+
|
|
296
|
+
## Performance
|
|
297
|
+
Release measurements from the 27 September 2026 run on one NVIDIA RTX 5090 with an Intel Core Ultra 9 285K cover RNEA,
|
|
298
|
+
its analytical gradient (∇RNEA), and its analytical Hessian (∇²RNEA) on iiwa14 (fixed base, 7 velocities), go2
|
|
299
|
+
(floating base, 18), and G1 (floating base, 35) at batch sizes 16–1024. The
|
|
300
|
+
[release measurements](https://a2r-lab.org/GRiD/release_measurements.html) page gives the method, every timing boundary, and the
|
|
301
|
+
caveats; the [benchmark harness](https://github.com/A2R-Lab/GRiD/tree/main/test/benchmarks/) reproduces the collection.
|
|
302
|
+
|
|
303
|
+
|
|
304
|
+
|
|
305
|
+
Ratios are baseline time divided by GRiD time; above 1× favors GRiD. Each column names its timing boundary: GRiD host
|
|
306
|
+
calls including copies against the CPU libraries, and GRiD compute-only calls against the GPU libraries' resident
|
|
307
|
+
calls. `*` marks cells where the evaluated baseline path required fp64 and `~` a side whose run means span more than
|
|
308
|
+
1.5×. Colors are clipped at 100×.
|
|
309
|
+
|
|
310
|
+
|
|
311
|
+
|
|
312
|
+
Microseconds per complete batch on a log axis. GRiD's bar splits into its CUDA compute-only call, the GPU–CPU I/O
|
|
313
|
+
increment, and the JAX wrapper increment. These are differences of measured call times, not isolated measurements of
|
|
314
|
+
each component.
|
|
315
|
+
|
|
316
|
+
|
|
317
|
+
|
|
318
|
+
Call wall times through each API boundary: native CUDA, the C++ host call, NumPy, PyTorch, and JAX. Pick the
|
|
319
|
+
boundary your application uses. For the Python surfaces the solid bar is the call with its buffers allocated once
|
|
320
|
+
and reused (measured 2 October 2026), and the hatched cap reaches the default call, which allocates its output every
|
|
321
|
+
time. With reused buffers, NumPy and PyTorch land within a few percent of the C++ host call on large outputs.
|
|
322
|
+
|
|
323
|
+
## Installation
|
|
324
|
+
The Quick Start above covers the common-case install. For CUDA Toolkit
|
|
325
|
+
setup, developer dependencies (Pinocchio, robot_descriptions, benchmarks),
|
|
326
|
+
and Docker, see the full
|
|
327
|
+
[installation guide](https://a2r-lab.org/GRiD/user_guide/getting_started/installation.html).
|
|
328
|
+
|
|
329
|
+
## Troubleshooting
|
|
330
|
+
|
|
331
|
+
### Bench harness `nvcc` hangs on floating-base kernels (sm_8x)
|
|
332
|
+
|
|
333
|
+
On Ampere (sm_86 / CUDA 12.6) the bench harness can wedge `nvcc` /
|
|
334
|
+
`ptxas` at 100 % CPU when compiling heavy floating-base GRiD harnesses.
|
|
335
|
+
Pass `--ptxas-opt-level 2` to `test/benchmarks/run_multi_version.py` — it
|
|
336
|
+
forwards `-Xptxas -O2` to floating-base compiles only. Blackwell (sm_120) does
|
|
337
|
+
not hit this. Typical user code that includes `grid.cuh` and calls the
|
|
338
|
+
batch host wrappers (e.g. `grid::forward_dynamics<T>(...)`) does not
|
|
339
|
+
trigger the hang — it's specific to the timing-bench template surface.
|
|
340
|
+
|
|
341
|
+
|
|
342
|
+
## Contributing
|
|
343
|
+
|
|
344
|
+
Contributions welcome — see [CONTRIBUTING.md](https://github.com/A2R-Lab/GRiD/blob/main/CONTRIBUTING.md) for the
|
|
345
|
+
workflow (and [CLAUDE.md](https://github.com/A2R-Lab/GRiD/blob/main/CLAUDE.md) for the repo conventions AI agents and
|
|
346
|
+
humans both follow).
|
|
347
|
+
|
|
348
|
+
## Contributors
|
|
349
|
+
|
|
350
|
+
<!-- ALL-CONTRIBUTORS-LIST:START - Do not remove or modify this section -->
|
|
351
|
+
<!-- prettier-ignore-start -->
|
|
352
|
+
<!-- markdownlint-disable -->
|
|
353
|
+
<table>
|
|
354
|
+
<tbody>
|
|
355
|
+
<tr>
|
|
356
|
+
<td align="center" valign="top" width="20%"><a href="https://github.com/plancherb1"><img src="https://avatars.githubusercontent.com/plancherb1?s=100" width="100px;" alt="Brian Plancher"/><br /><sub><b>Brian Plancher</b></sub></a><br /></td>
|
|
357
|
+
<td align="center" valign="top" width="20%"><a href="https://github.com/Z4KH"><img src="https://avatars.githubusercontent.com/Z4KH?s=100" width="100px;" alt="Zachary Pestrikov"/><br /><sub><b>Zachary Pestrikov</b></sub></a><br /></td>
|
|
358
|
+
<td align="center" valign="top" width="20%"><a href="https://github.com/kawotwi"><img src="https://avatars.githubusercontent.com/kawotwi?s=100" width="100px;" alt="Kwamena A"/><br /><sub><b>Kwamena A</b></sub></a><br /></td>
|
|
359
|
+
<td align="center" valign="top" width="20%"><a href="https://github.com/anncli"><img src="https://avatars.githubusercontent.com/anncli?s=100" width="100px;" alt="Ann Li"/><br /><sub><b>Ann Li</b></sub></a><br /></td>
|
|
360
|
+
<td align="center" valign="top" width="20%"><a href="https://github.com/caelyasutake"><img src="https://avatars.githubusercontent.com/caelyasutake?s=100" width="100px;" alt="Cael Yasutake"/><br /><sub><b>Cael Yasutake</b></sub></a><br /></td>
|
|
361
|
+
</tr>
|
|
362
|
+
<tr>
|
|
363
|
+
<td align="center" valign="top" width="20%"><a href="https://github.com/pruyontrarakk"><img src="https://avatars.githubusercontent.com/pruyontrarakk?s=100" width="100px;" alt="pruyontrarakk"/><br /><sub><b>pruyontrarakk</b></sub></a><br /></td>
|
|
364
|
+
<td align="center" valign="top" width="20%"><a href="https://github.com/the-eater"><img src="https://avatars.githubusercontent.com/the-eater?s=100" width="100px;" alt="="/><br /><sub><b>=</b></sub></a><br /></td>
|
|
365
|
+
</tr>
|
|
366
|
+
</tbody>
|
|
367
|
+
</table>
|
|
368
|
+
|
|
369
|
+
<!-- markdownlint-restore -->
|
|
370
|
+
<!-- prettier-ignore-end -->
|
|
371
|
+
|
|
372
|
+
<!-- ALL-CONTRIBUTORS-LIST:END -->
|